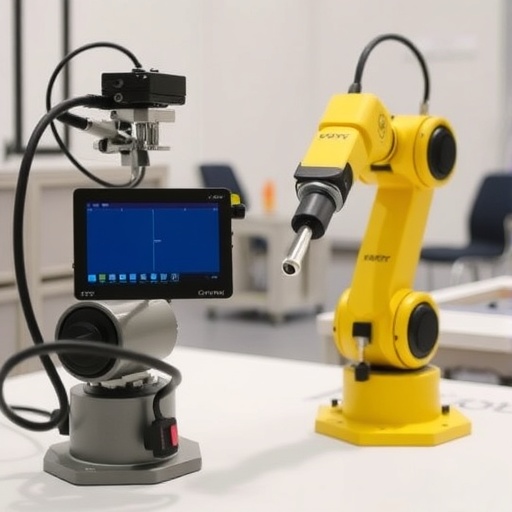
In recent years, the integration of collaborative robots—commonly known as cobots—into diverse industrial settings has surged dramatically. These machines work alongside human operators, enhancing productivity, flexibility, and safety in manufacturing, logistics, and service sectors. However, achieving precise and reliable performance from cobots hinges heavily on meticulous calibration processes, traditionally dependent on complex, costly external measurement devices. A groundbreaking study by Franzese, Spahn, Kober, and colleagues, published in Communications Engineering in 2026, unveils a novel approach that challenges the status quo: accurate and affordable cobot calibration without external measurement devices.
Calibration is central to robotic operation; it ensures that the machine’s perception of its environment and movement aligns perfectly with reality. Without such synchronization, even the most advanced cobots may falter, resulting in reduced efficiency or hazardous errors. Conventional calibration methods typically require specialized equipment like laser trackers, external cameras, or precision measurement tools, which add both financial and logistical burdens to deployment. This restricts cobots’ accessibility, especially for small and medium enterprises or applications in dynamic environments where recalibration must be frequent and swift.
The study introduces an innovative method leveraging intrinsic sensor data and advanced algorithmic compensation techniques. Instead of relying on external instrumentation, this new calibration technique uses the cobot’s own internal sensors, including encoders, force-torque sensors, and inertial measurement units, to self-assess and correct its positioning and movement errors. By harnessing the robot’s internal sensory feedback, the researchers circumvent the need for cumbersome external devices, thereby democratizing accurate calibration.
At the core of the approach is a sophisticated computational model that interprets multisensor data, compensating for joint backlash, compliance, temperature-induced deviations, and dynamic effects that typically degrade precision. This model incorporates a rigorous kinematic and dynamic framework that accounts for manufacturing tolerances and wear and tear, which conventional models often overlook. By integrating these factors, the cobot can iteratively refine its internal maps of joint angles and link positions with remarkable accuracy.
Significantly, the research team developed a robust optimization algorithm using machine learning techniques that adaptively tunes calibration parameters over time. This adaptive process enables continuous in-operation calibration, allowing the cobot to maintain peak accuracy despite environmental changes or mechanical drift. Unlike static, one-time calibrations, this dynamic method ensures that cobots are perpetually aligned with their physical state, thus enhancing operational reliability and reducing downtime.
The implications of this technology are far-reaching. By eliminating dependency on external measurement devices, businesses can drastically reduce calibration costs and complexity. Moreover, field recalibration can be conducted by non-expert users, empowering frontline operators to manage maintenance autonomously. This breakthrough therefore addresses one of the critical bottlenecks limiting widespread cobot adoption in emerging markets and agile manufacturing systems.
The researchers validated their method across several experimental setups involving different classes of cobots, encompassing articulated arms and mobile manipulators. Measurement comparisons against state-of-the-art external metrology systems demonstrated that the new calibration yields precision within a fraction of a millimeter, rivaling conventional methods. Furthermore, calibration time was reduced by over 50%, showcasing the method’s practicality for industrial use.
Beyond manufacturing, this autonomous calibration technique holds promise for cobots deployed in healthcare, agriculture, or hazardous environments where external measurement setups are impractical, if not impossible. For example, surgical robots could benefit from continuous internal calibration for enhanced safety and efficacy. Similarly, agricultural cobots working in unstructured outdoor terrains could self-calibrate amidst changing conditions, maintaining productivity.
The advent of affordable, self-contained calibration technologies also aligns perfectly with trends toward increased automation and Industry 4.0 smart factories. These environments demand flexible robots capable of rapid redeployment and adaptation, tasks made feasible by quick, accurate recalibration. The study’s findings enable cobot manufacturers to streamline design considerations, focusing on sensor integration and software intelligence rather than external calibration infrastructure.
Critically, the research underscores the importance of sensor fusion – combining multiple sensing modalities provides redundancy and richer data for error correction. The integration of force-torque sensing proved particularly beneficial in detecting subtle deviations during physical interactions, enabling finer calibration granularity. By contrast, purely kinematic methods fare poorly over time when subjected to mechanical wear.
Despite its remarkable success, the team acknowledges certain limitations. The approach currently relies on relatively high-quality internal sensors; thus, extremely low-cost cobots with minimal sensing capabilities might not fully benefit without hardware upgrades. Additionally, calibration of complex multi-cobot systems with interdependencies poses an ongoing challenge, necessitating further algorithmic development.
Looking forward, the researchers plan to extend their methodology by incorporating vision-based internal calibration using embedded cameras, augmenting sensor fusion with environmental perception. Incorporating real-time feedback from external human operators could also enhance adaptability, enabling intuitive calibration assistance. Moreover, reduction of computational demands remains a focal point to enable deployment on resource-constrained robotic platforms.
This pioneering work by Franzese and colleagues represents a major leap toward making cobots more autonomous, reliable, and accessible. By freeing calibration from external devices, the robotics industry can overcome one of its most persistent barriers, paving the way for truly ubiquitous, intelligent robotic collaborators. The future symbiosis of humans and robots in daily workflows becomes significantly more attainable, promising enhanced productivity and safety across manifold sectors.
In summary, the breakthrough self-calibration framework unveiled in this study represents an elegant fusion of advanced sensor analytics, machine learning, and robot kinematics. It democratizes access to high-precision calibration, reduces operational expenses, and elevates the functional autonomy of cobots. As the robotics landscape evolves rapidly, such innovations will be instrumental in shaping the next generation of intelligent, collaborative machines that seamlessly integrate into human environments.
Subject of Research: Collaborative robot calibration methods and sensor-based self-calibration techniques
Article Title: Accurate and affordable cobot calibration without external measurement devices
Article References:
Franzese, G., Spahn, M., Kober, J. et al. Accurate and affordable cobot calibration without external measurement devices. Commun Eng (2026). https://doi.org/10.1038/s44172-026-00633-4
Image Credits: AI Generated
Tags: accessible cobot solutions for SMEsadvanced algorithmic compensation in roboticsaffordable cobot calibration methodscobot calibration without external toolscollaborative robot calibration techniquesdynamic environment robot calibrationenhancing cobot performance reliabilityindustrial collaborative robots calibrationintrinsic sensor data for robot calibrationprecise calibration for manufacturing cobotsreal-time cobot recalibration methodsreducing calibration costs for cobots