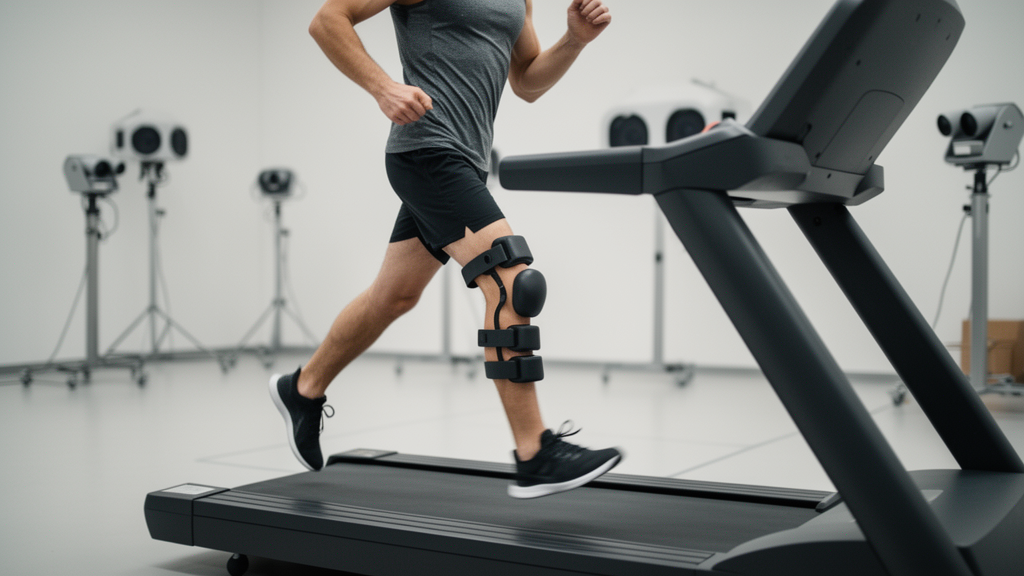
A research study authored by Hua Wang introduces an integrated data capture and fusion framework designed to substantially enhance the accuracy and numerical stability of wearable human motion tracking. To resolve these operational constraints, the investigation combines mathematical joint modeling based on four-dimensional quaternions, root bone forward kinematics, tailored multi-sensor calibration procedures, and an optimized Madgwick attitude estimation algorithm. Experimental evaluations of the newly introduced model demonstrated a maximum mean error of 1.21 degrees and a root mean square error of 1.17 degrees for yaw angle tracking, alongside a maximum mean error of 1.24 degrees and a root mean square error of 1.19 degrees for pitch angle determination. Furthermore, maximum data capture errors during joint tracking reached 3.8 for the knee joint and 6.1 for the elbow joint, confirming measurable performance gains over existing baseline methods.
Wearable sensor technology has expanded rapidly over recent decades to become a vital foundation for monitoring and analyzing human physical activity across sports science, physical rehabilitation, virtual reality environments, and human-computer interaction interfaces. Standard configurations incorporate micro-machined accelerometers, angular gyroscopes, and magnetic field sensors positioned across multiple segments of the human body to acquire detailed movement information in real time. Nevertheless, existing research literature has frequently concentrated on single-sensor deployments or isolated limb tracking, which leaves broader multi-sensor networks vulnerable to significant data synchronization errors, signal noise, and cumulative sensor drift. In multi-device setups, differing hardware response times, varied sampling frequencies, and physical latency between remote body nodes degrade the consistency of fused data streams.
Previous scholarly efforts have targeted specialized aspects of wearable tracking with varied success, highlighting persistent technical bottlenecks in multi-sensor data fusion. Yan and coworkers targeted knee joint tracking under short-term mechanical impact by applying energy calculations to single-point joint modeling, confirming feature reinforcement during low-frequency walking gait. Gao and colleagues developed wearable sensors incorporating graphene-silicone rubber foam composites, successfully monitoring nine distinct body regions during complex motions. In fall detection research, Abdu and associates paired convolutional neural networks with radar micro-Doppler signatures to achieve a 99.77 percent classification accuracy among elderly subjects. Multimodal capture platforms developed by Xue and collaborators recognized ten finger movement features with 93.72 percent accuracy but encountered severe synchronization discrepancies during high-frequency motions. Additionally, Lee and colleagues merged inverse dynamics with deep learning to mitigate poor real-time responsiveness in inertial joint tracking.
To establish a coherent structural foundation for motion tracking, Wang simplified the intricate anatomical complexity of the human musculoskeletal system into an operational mathematical representation. Because natural human movement involves an exceptionally large arrangement of bones, skeletal muscles, articulating joints, and flexible soft tissues, simulating raw anatomical complexity directly in embedded devices produces prohibitive computational delays. The author addressed this computational burden by abstracting the human body into a hierarchical skeletal chain comprising fifteen discrete segments. This structural chain establishes coordinated kinematic coverage over the head, back, waist, hips, left upper arm, left lower arm, left hand, right upper arm, right lower arm, right hand, left thigh, left calf, left foot, right thigh, right calf, and right foot.
The spatial orientation of each structural limb segment is tracked mathematically using quaternions, which avoid the mathematical singularity of gimbal lock found in Euler angle representations and require fewer computational operations than conventional three-dimensional rotation matrices. Representing spatial rotations through a four-dimensional construct consisting of a scalar cosine value and a three-dimensional vector axis, quaternions maintain numerical stability across extended calculation intervals and prevent excessive computational drift. Anatomical boundary limits established by the International Society of Biomechanics were integrated directly into the data preprocessing routines, establishing reference frames centered on proximal joints with orthogonal coordinate axes. These joint constraints incorporate physiological ranges of motion, including hip internal rotation of zero to fifty degrees, external rotation of zero to forty degrees, and forward flexion of zero to one hundred forty degrees, alongside elbow internal rotation of zero to ninety degrees and flexion of zero to one hundred fifty degrees. Root bone forward kinematics groups these skeletal segments into five distinct kinematic branches extending outward from the pelvis.
The physical measurement architecture relies on miniature microelectromechanical systems organized into modular hardware divisions, including inertial measurement unit modules, central processing controllers, wireless communication transceivers, program debugging connections, and power management circuits. Because raw microelectromechanical sensors inherently suffer from manufacturing irregularities and environmental thermal sensitivity, the author established dedicated mathematical calibration routines for each onboard sensing element. Accelerometer calibration combines linear error modeling with temperature compensation formulas that account for baseline bias vectors at reference temperatures alongside thermal variation offsets and axis scaling factors. Gyroscope calibration focuses specifically on compensating for random drift noise and temperature-induced bias shifts across continuous measurement cycles. Magnetometer calibration resolves soft-iron magnetic interference and mechanical mounting alignment errors through dedicated scaling matrices and spatial rotation corrections. Correcting these baseline physical discrepancies prior to numerical fusion ensures that raw inertial measurements delivered to the pose determination algorithm remain structurally consistent and free of severe instrument-level bias.
Calibrated sensor observations are subsequently merged using the Madgwick attitude solution algorithm, which applies a gradient descent optimization routine to compute optimal orientation quaternions with low computational overhead. Unlike extended Kalman filters that demand intensive matrix operations and precise initial statistical parameters, or complementary filters that fail to capture nonlinear errors and inter-sensor dynamics, the Madgwick formulation processes normalized vectors from accelerometers, gyroscopes, and magnetometers within embedded processing limitations. The algorithm calculates optimization step vectors scaled by an adjustable compensation parameter and balances orientation rates derived from gyroscopic integration against spatial attitude solutions obtained from accelerometer and magnetometer fields using an explicit weighting coefficient. By looping this gradient descent optimization continuously, the system suppresses high-frequency sensor noise, mitigates directional drift, and dynamically updates the spatial attitude quaternion, allowing the multi-dimensional rigid body chain model to compute real-time forward kinematic joint trajectories without overwhelming local hardware controllers.
Experimental validation of the calibration parameters was conducted using an InvenSense MPU9250 wearable inertial sensor operating at an eighty-hertz sampling frequency across twenty distinct measurement sequences. Applying an ellipse fitting technique to measured outputs across three orthogonal axes revealed circular output distributions and established optimal operational bias ranges. Comparative attitude tests demonstrated that the proposed model produced significantly smoother yaw and pitch curves than standalone Madgwick, complementary filter, or unscented Kalman filter implementations, yielding an average yaw angle of 0.2 degrees and an average pitch angle of negative 0.4 degrees.
When evaluated in isolation, the standard Madgwick algorithm displayed substantial drift accumulation, exhibiting a maximum average error of 3.11 degrees and a root mean square error of 1.98 degrees for yaw, alongside a maximum average error of 2.74 degrees and a root mean square error of 1.87 degrees for pitch. Unscented Kalman filters and particle filters demonstrated improved nonlinear handling but remained sensitive to initial noise parameters. Among existing benchmark models, the information filter achieved the strongest secondary performance, recording maximum average yaw and pitch errors of 1.62 degrees and 1.68 degrees, with root mean square errors of 1.53 degrees and 1.42 degrees, respectively. The proposed framework outperformed all benchmarked filters, recording lowest maximum average errors of 1.21 degrees for yaw and 1.24 degrees for pitch, alongside lowest root mean square errors of 1.17 degrees and 1.19 degrees, demonstrating high numerical stability.
Dynamic validation was performed using sensor nodes from a Noetic inertial human motion capture system operating at an input frequency of one hundred fifty hertz while a human test subject executed eight distinct yoga postures. Prior to optimization, joint tracking error curves displayed sharp nonlinear variations, reaching maximum errors of nine for the knee joint and 7.8 for the elbow joint. Following implementation of the quaternion forward kinematics and dynamic calibration framework, maximum tracking errors decreased substantially to 3.8 for the knee and 6.1 for the elbow. When benchmarked against camera-based deep learning vision frameworks including OpenPose, AlphaPose, and MediaPipe, the proposed wearable system recorded capture time differences of 0.7 seconds for the knee and 0.4 seconds for the elbow, achieving tracking accuracies of 93.67 percent and 93.66 percent, respectively. The author noted that physical wearing comfort was not evaluated in this study, representing an important consideration for subsequent investigations.
Subject of Research: Human joint motion data capture and multi-sensor fusion using wearable inertial sensors
Article Title: Human joint motion data capture and fusion based on wearable sensors
Article References: Wang, H. (2025). Human joint motion data capture and fusion based on wearable sensors. Autonomous Intelligent Systems, 5(1), Article 12. https://doi.org/10.1007/s43684-025-00098-w
Image Credits: AI Generated
DOI: 10.1007/s43684-025-00098-w
Keywords: wearable sensors, motion capture, sensor fusion, quaternions, Madgwick algorithm, forward kinematics, rigid body chain, accelerometer calibration, gyroscope drift, magnetometer correction, MPU9250, knee joint kinematics, elbow joint tracking, inertial measurement units, posture estimation, biomechanics
News Source: Denise Maddox. (November 11, 2026). Wearable Sensor Model Improves Joint Motion Capture Accuracy and Stability. Scienmag.