New AI Network Enhances UAV Thermal Mapping in Dynamic Environments
MAPS-Net, a new multi-modal attention and planning network, enhances autonomous UAV thermal mapping by combining deep learning with Monte Carlo ...
MAPS-Net, a new multi-modal attention and planning network, enhances autonomous UAV thermal mapping by combining deep learning with Monte Carlo ...
Researchers have developed a distributed exploration framework that combines cooperative grid allocation with velocity-aware risk prediction to keep autonomous drone ...
A two-phase optimization framework demonstrates that domain clustering governs Pareto coverage while reinforcement learning accelerates convergence during simulated drone navigation ...
Researchers have developed a dual-constrained pulse-coupled neural network algorithm that accelerates robotic path planning by suppressing redundant neuron activations without ...
Researchers report a simulation-based explainability framework that pairs a physics-guided reinforcement learning controller with XGBoost and SHAP analysis to trace ...
An in-person experiment with 35 participants found that a straight wall-following path was the most comfortable robot route in varying-width ...
A simulation study found that a PID-and-reactive navigation scheme kept a mobile robot collision-free but slowed it to 0.17 m/s ...
Automated vehicles promise safer highways, but the hardest moments are often the simplest ones: a car ahead braking suddenly, a ...
A MATLAB simulation combining Theta* planning, potential field avoidance, Pure Pursuit tracking and LIDAR mapping reached the goal in nine ...
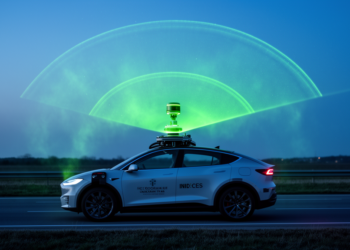
Researchers in Hefei have combined a compact Mie-scattering LiDAR with an autonomous electric vehicle to continuously profile aerosols in three ...
A new local planner maintains a probabilistic estimate of a hidden person's position, letting indoor robots keep following targets through ...
A new study combines an improved graph capsule neural network with a user-aware A* path planning algorithm to create an ...
Researchers trained a deep reinforcement learning agent to plan collision-free paths for a fuel-saving free-floating space manipulator, even with noisy ...
Researchers have developed a modified particle swarm optimization algorithm that outperforms eight competing heuristics in mobile robot path planning, cutting ...
Researchers have developed an adaptive logistic regression model that lets low-cost autonomous robots classify obstacles and steer through dense environments ...