• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Tuesday, October 27, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Robot planner keeps following people even when they vanish from view

by
October 27, 2026
in Technology
Reading Time: 2 mins read
0
Robot planner keeps following people even when they vanish from view

Robot planner keeps following people even when they vanish from view

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

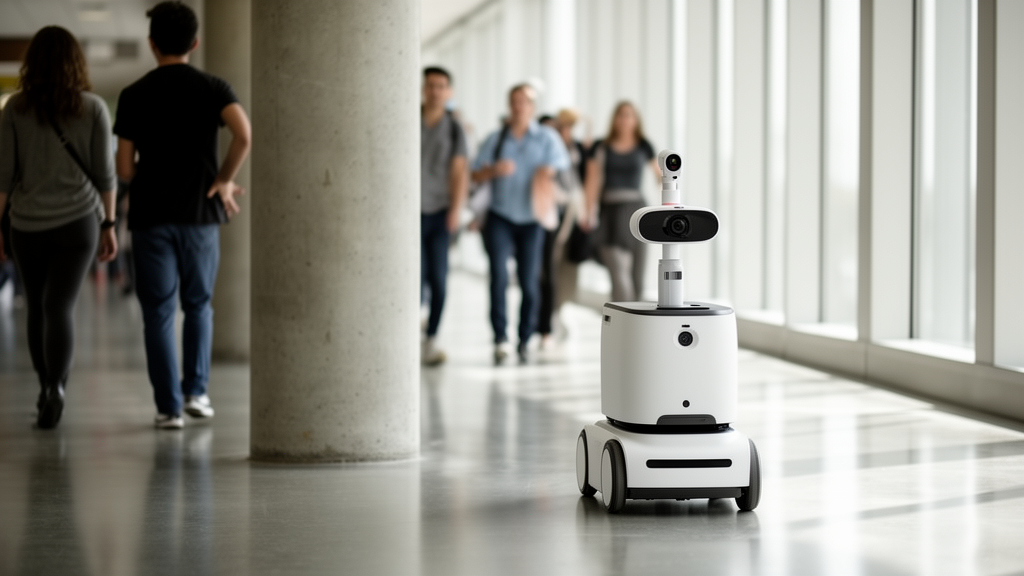
Indoor robots that follow people tend to freeze the moment their target disappears around a corner or into a crowd. A new local planner called IO-TEB, described in Scientific Reports, is designed to keep moving sensibly through exactly those gaps. Instead of treating the last camera sighting as the person's fixed location, the planner maintains a probabilistic estimate of where the hidden person probably is, together with the growing uncertainty of that estimate, and feeds both directly into its trajectory optimization.

In conventional setups, when a person is lost from view, the robot typically stalls at the last seen position. IO-TEB instead lets the optimizer work with the predicted estimate, and when the person remains hidden for longer stretches, the robot actively searches along paths the person is likely to have taken, such as corridors and doorways. The researchers evaluated the planner across 4,320 simulated episodes spanning eight indoor scenes, three durations of occlusion, and real pedestrian trajectory data.

IO-TEB completed 87.36 percent of following tasks, compared with 55.14 percent for the standard timed elastic band planner. An important benchmark comparison involved a conventional design that handles the same probabilistic estimate in a separate finite-state supervisor, switching between modes depending on whether the person is visible. IO-TEB was statistically equivalent to that design, suggesting that embedding the belief estimate directly inside the optimizer costs neither accuracy nor computational overhead, while simplifying the architecture.

Real-time performance was another focus. The team compared IO-TEB with model predictive control using trajectory prediction and with three recent person-following planners. IO-TEB was not the most accurate of these methods, but in the authors' implementation it missed the 100-millisecond control-cycle deadline least often, exceeding the deadline on 3.32 percent of cycles, against a range of 5.14 to 44.21 percent for the alternatives.

Ablation experiments, in which components were removed one at a time, revealed which parts of the design actually drive the improvement. Replacing the last observation with the predicted estimate as the following reference accounted for most of the gain. By contrast, the additional terms that scale with the estimate's uncertainty brought no consistent benefit, a finding that could simplify future implementations.

The results are limited to simulation, albeit with realistic pedestrian trajectories, and the authors note the reported deadline-miss figures apply to their specific implementation. Even so, the study offers a concrete recipe for person-following robots: rather than adding external state machines or heavier predictors, a local planner can absorb a belief about a hidden target and remain computationally lean. The open-access study suggests that modest changes to existing planners, rather than wholesale redesigns, may deliver much of that robustness.

Subject of Research: Robot local planning for indoor person following under intermittent observations

Article Title: Belief-integrated timed elastic band planning for robust indoor person following under intermittent observations

Article References: Guan, J., Liu, S., Guan, K., Zheng, H., & Hu, W. (2026). Belief-integrated timed elastic band planning for robust indoor person following under intermittent observations. Scientific Reports. https://doi.org/10.1038/s41598-026-76768-3

Image Credits: AI Generated

DOI: 10.1038/s41598-026-76768-3

Keywords: robotics, person following, path planning, timed elastic band, probabilistic estimation, occlusion, trajectory optimization, model predictive control, indoor navigation, real-time planning, Belief-integrated, timed

News Source: Denise Maddox. (October 27, 2026). Robot planner keeps following people even when they vanish from view. Scienmag.
Tags: Belief-integratedindoor navigationmodel predictive controlocclusionpath planningperson followingprobabilistic estimationreal-time planningRoboticstimedtimed elastic bandtrajectory optimization
Share12Tweet7Share2ShareShareShare1

Related Posts

Research report: SLAM Project - Long-Term Ecological Study of the Impacts of Climate Change in the natural forest of Azores: VII - Long-term arthropod monitoring in Graciosa Island

Research report: SLAM Project – Long-Term Ecological Study of the Impacts of Climate Change in the natural forest of Azores: VII – Long-term arthropod monitoring in Graciosa Island

October 27, 2026
Hybrid retrieval and verification framework cuts hallucinations in medical AI

Hybrid retrieval and verification framework cuts hallucinations in medical AI

October 27, 2026

Switching Headways, Not Lost Signals, Destabilises Self-Driving Platoons

October 27, 2026

Fractal Fingerprints of Chinese Mainland Seismicity Reveal Deep Tectonic Controls

October 27, 2026

POPULAR NEWS

  • Body Image Distress Rises in Final Months for Pancreatic Cancer Patients of Both Sexes

    Body Image Distress Rises in Final Months for Pancreatic Cancer Patients of Both Sexes

    29 shares
    Share 12 Tweet 7
  • Botanists complete first full flora of Empoli, revealing heavy alien invasion

    29 shares
    Share 12 Tweet 7
  • Research report: SLAM Project – Long-Term Ecological Study of the Impacts of Climate Change in the natural forest of Azores: VII – Long-term arthropod monitoring in Graciosa Island

    29 shares
    Share 12 Tweet 7
  • Gemcitabine-Fused microRNA Shows Promise Against Chemoresistant Colorectal Cancer in Preclinical Models

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Body Image Distress Rises in Final Months for Pancreatic Cancer Patients of Both Sexes

Botanists complete first full flora of Empoli, revealing heavy alien invasion

Research report: SLAM Project – Long-Term Ecological Study of the Impacts of Climate Change in the natural forest of Azores: VII – Long-term arthropod monitoring in Graciosa Island

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 85 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.