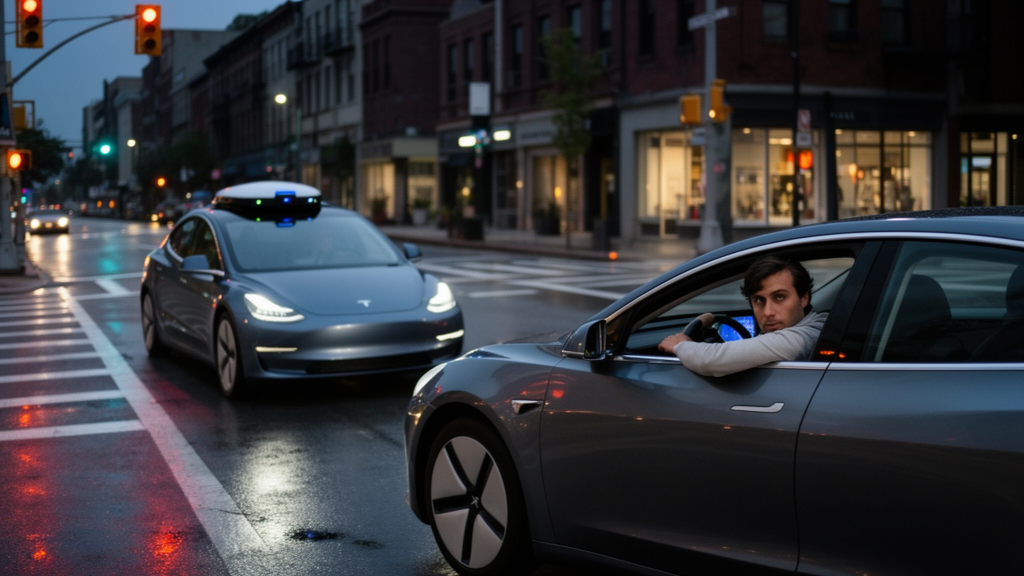
Autonomous vehicles are often assessed by how well they control themselves, but a new open-access review argues that a large share of mixed-traffic risk comes from the humans around them.
The authors start from a deceptively simple observation: the same visible behavior can mean very different things depending on the interaction partner. A short following distance behind a human-driven vehicle may reflect a conventional car-following error, but the same short gap behind a recognizable autonomous vehicle may reflect trust in its braking, imitation of its platooning style, or deliberate exploitation of its expected conservatism. Existing driver error and violation taxonomies, including the slips, lapses, mistakes and violations framework of Reason and colleagues and the generic driver error taxonomy of Stanton and Salmon, were developed mainly for conventional traffic, where unsafe behavior is interpreted within a human–human interaction system.
To build the mixed-traffic extension, the team combined two input streams. The first was a review of established driver error, violation and situation-awareness frameworks, which supplied the conceptual scaffold: Endsley’s three levels of situation awareness — perception, comprehension and projection — plus a decision stage, together with the distinction between unintentional errors and violations. The second was a structured narrative search of Google Scholar, TRID, Scopus and Web of Science, with no lower publication date limit through 17 April 2026, covering driving-simulator and field studies, naturalistic dataset and crash-report analyses, observational work, driver self-reports, survey experiments and human-calibrated microsimulation. More than 60 publications and data sources were assessed; 37 met the eligibility criteria and yielded 49 coded evidence cases, with 29 of the 37 studies published between 2021 and 2026.
Each case was coded on three attributes: the observable unsafe behavior, the information-processing stage at which the error was inferred to occur, and the autonomous-vehicle-specific interaction factors that appeared to trigger or modulate it. Nine such factors emerged from the evidence: autonomous vehicle recognizability and identity cues; driving style and rule compliance; behavior predictability and intent ambiguity; trust in autonomous vehicle safety and automation capability; social status and moral accountability; dedicated infrastructure; platoon exposure; penetration rate and traffic composition; and repeated exposure and learning. Observable behaviors were grouped into four categories: reduced safety margins, right-of-way and yielding behavior, gap and lane-change behavior, and aggression or exploitation.
The descriptive analysis of the 49 cases points to a clear concentration. Mixed-traffic errors cluster mainly in the projection and decision stages — that is, in anticipating what an autonomous vehicle will do next and in choosing how to respond — rather than in simply failing to perceive it. Two recurring pathways dominate. The first is projection-stage safety-margin reduction: drivers overtrust autonomous vehicle capability, treat its behavior as predictable, or expect it to compensate for unsafe human actions, producing shorter time headways, smaller accepted gaps, closer following and reduced overtaking margins. The second is decision-stage exploitation or social devaluation: drivers treat autonomous vehicles as lower-priority, less socially protected or safer-to-bully partners, producing reduced yielding, brake-checking, racing, close cut-ins and intentional exploitation of conservative autonomous vehicle behavior.
The behavioral evidence behind these pathways is varied but consistent in direction. Field and naturalistic analyses, including studies based on the Waymo Open Dataset, suggest that drivers of manually driven vehicles behave differently when following autonomous vehicles than when following other manual vehicles; some report lower driving volatility and smoother speed adjustments. Yet crash-report analyses of California DMV autonomous vehicle collision reports show a safety-relevant counterpart: rear-end collisions were frequent, most involved the autonomous vehicle being struck by another vehicle, and rear-end crashes were positively associated with autonomous vehicles being stopped, slowing, yielding or waiting. Conventional-vehicle drivers involved in autonomous vehicle crashes were more often coded with unsafe speed and following too closely than drivers in comparable conventional crashes at the same locations.
Merging and gap acceptance show an even more direct link to autonomous-vehicle-specific expectations. Several studies indicate that drivers accept smaller gaps or merge more assertively in front of autonomous vehicles, especially when they believe the vehicles are programmed defensively — a phenomenon the authors connect to automation complacency, where drivers overestimate autonomous capabilities and fail to account for real-world limitations. Reddy and colleagues further showed that recognizability and driving style interact: recognizable aggressive autonomous vehicles led to larger critical gaps, whereas non-recognizable aggressive ones led to smaller critical gaps. Platoon and infrastructure effects add another layer: Gouy and colleagues found that human drivers reduced their own headways when driving beside autonomous vehicle platoons with short headways, and simulator work suggests that higher autonomous vehicle penetration can lead drivers to adopt shorter headways and less variable speed, imitating patterns they cannot safely replicate without the same automation.
The authors are explicit that these distributions describe the reviewed literature, not the true prevalence of error types on real roads. The coding of stages and factors involved interpretive judgment, no formal coding-reliability assessment was conducted, and the categories were developed and reapplied on the same case set without independent held-out validation, so the results should not be assumed exactly reproducible. The evidence base also relies heavily on simulators, survey experiments, virtual reality, test tracks and a limited number of naturalistic studies, which caution against direct generalization to crash causation. The taxonomy covers only drivers of manually driven vehicles interacting with autonomous vehicles as surrounding road users; pedestrians, cyclists, autonomous vehicle passengers, remote operators and drivers supervising partial automation are outside its scope.
Even with those caveats, the framework carries a practical implication that reaches beyond academia: autonomous vehicle safety should be evaluated not only through the vehicle’s own control performance but through its behavioral effect on other road users. Design choices such as driving style, external communication, recognizability, platooning behavior, rule compliance and dedicated infrastructure can shape the error patterns of surrounding human drivers, sometimes unintentionally. The authors propose the taxonomy’s attribute structure as a basis for safety performance indicators in mixed traffic, for coding safety-critical events, and for designing simulation experiments, and they call for validation against naturalistic-driving data to test whether the projection-stage safety-margin reduction and decision-stage exploitation patterns identified here also appear in real safety-critical events.
Subject of Research: A taxonomy of human driver errors and unsafe adaptations in mixed traffic with autonomous vehicles
Article Title: A taxonomy of human driver errors and unsafe adaptations in mixed traffic
Article References: Mironenko, O., Banaee, H., & Loutfi, A. (2026). A taxonomy of human driver errors and unsafe adaptations in mixed traffic. European Transport Research Review, 18(1), Article 91. https://doi.org/10.1186/s12544-026-00851-z
Image Credits: AI Generated
DOI: 10.1186/s12544-026-00851-z
Keywords: autonomous vehicles, mixed traffic, driver error taxonomy, behavioral adaptation, road safety, situation awareness, gap acceptance, car-following, trust in automation, crash reports, traffic safety, human factors
News Source: Denise Maddox. (October 28, 2026). New taxonomy maps how human drivers err around autonomous vehicles. Scienmag.