• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Friday, October 23, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold

by
October 23, 2026
in Technology
Reading Time: 2 mins read
0
AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold

AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

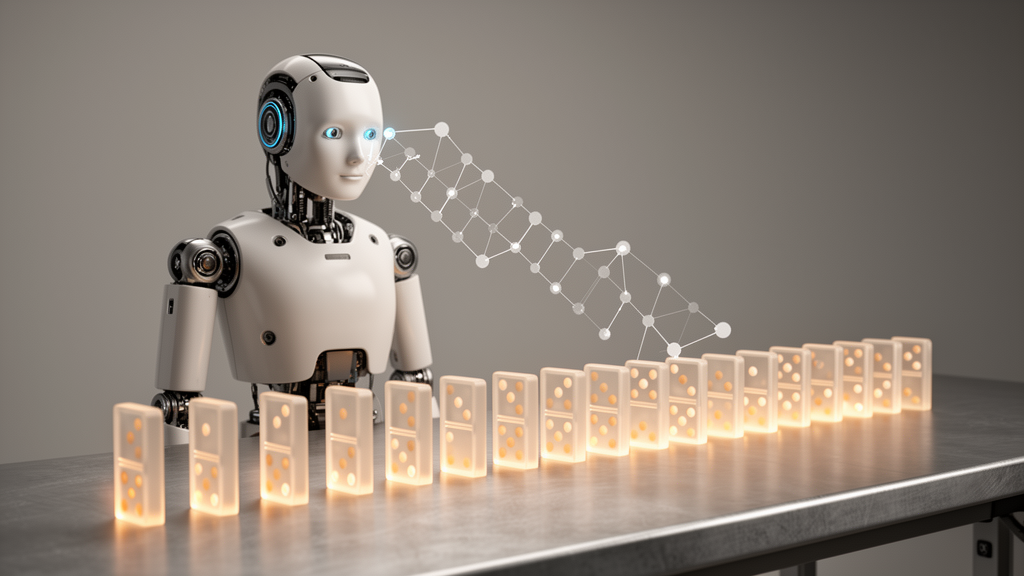
Autonomous agents that follow natural-language instructions often struggle once a task stretches beyond a few steps. A hierarchical policy framework called EOPBiSE (Episodic On-the-Fly Planner and Bifurcate Subgoal Executor), described in an open-access paper published in Complex & Intelligent Systems, addresses that weakness by grounding its planning in what the agent actually sees as the episode unfolds. The core problem the researchers identified is a discrepancy between plan and status.

When a plan is generated only from the language instruction, it cannot adapt if the environment deviates from what the plan assumed, so the agent may keep pursuing subgoals that no longer match the real-time state of the world. EOPBiSE tackles this with a planner that draws on both the linguistic instruction and holistic visual observations taken from the task's entire episode history, allowing subgoal predictions to be updated in an adaptive, on-the-fly manner rather than fixed in advance. Execution is handled by a separate component, the bifurcate subgoal executor.

By splitting the subgoal information it receives, the executor is designed to minimize the gap between what was planned and what is actually happening during execution, translating abstract intermediate goals into concrete actions more reliably. The team evaluated the framework on ALFRED, a benchmark of complex household tasks carried out from an egocentric visual perspective. According to the paper, EOPBiSE effectively handled a wide range of long-horizon tasks and showed generalization capabilities in unseen scenarios, meaning it maintained performance when tested on environment configurations it had not been trained on.

The reported results come from a single benchmark of simulated household tasks, and the abstract-level claims concern task handling and generalization within that setting. The planner's use of episodic visual history is the key departure from prior approaches, tying each predicted subgoal to accumulated evidence about the task's progress instead of to the instruction text alone, with the reduction of plan-status discrepancy described as the mechanism behind the framework's performance.

Subject of Research: A hierarchical AI policy that plans and executes subgoals for long-horizon instruction following tasks

Article Title: Learning to plan and execute subgoals with a hierarchical policy for long-horizon instruction following tasks

Article References: Zhuang, B., Zhang, C., Zhang, M., & Hu, Z. (2026). Learning to plan and execute subgoals with a hierarchical policy for long-horizon instruction following tasks. Complex & Intelligent Systems. https://doi.org/10.1007/s40747-026-02416-y

Image Credits: AI Generated

DOI: 10.1007/s40747-026-02416-y

Keywords: EOPBiSE, hierarchical policy, autonomous agents, instruction following, subgoal planning, ALFRED benchmark, long-horizon tasks, egocentric vision, machine learning, AI planning, Learning, plan

News Source: Denise Maddox. (October 23, 2026). AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold. Scienmag.
Tags: AI planningALFRED benchmarkautonomous agentsegocentric visionEOPBiSEhierarchical policyinstruction followinglearninglong-horizon tasksMachine Learningplansubgoal planning
Share12Tweet7Share2ShareShareShare1

Related Posts

AI Decision Aid for Juvenile Arthritis Scores Well on Safety but Diverges on Treatment Choices

AI Decision Aid for Juvenile Arthritis Scores Well on Safety but Diverges on Treatment Choices

October 23, 2026
Low-Loss InP Splitter Delivers Near-Perfect Power Balance for Photonic Chips

Low-Loss InP Splitter Delivers Near-Perfect Power Balance for Photonic Chips

October 23, 2026

Piezoelectric Hydrogel Turns Muscle Motion Into Signals That Rebuild Bone in Osteoporosis

October 23, 2026

CodeBERT edges out BERT rivals in controlled defect-detection benchmark, but the gap is not statistically significant

October 23, 2026

POPULAR NEWS

  • AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold

    AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold

    29 shares
    Share 12 Tweet 7
  • Global evidence map links soil fertility management to fertilizer efficiency and greenhouse gas outcomes

    29 shares
    Share 12 Tweet 7
  • Host–virus genetic interactions mask heritable fitness variation in flies

    29 shares
    Share 12 Tweet 7
  • Screening Young Hearts: How ECGs and AI Could Curb Sudden Cardiac Death

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

AI Agents Learn to Plan Subgoals by Watching the Whole Task Unfold

Global evidence map links soil fertility management to fertilizer efficiency and greenhouse gas outcomes

Host–virus genetic interactions mask heritable fitness variation in flies

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 85 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.