Researchers have developed a novel trajectory generation method that enables industrial robots to handle diverse products more rapidly and accurately in complex logistics environments. Published in the journal Autonomous Intelligent Systems, the study presents an integrated approach combining an improved deep learning algorithm for path planning with a time-optimal trajectory planning algorithm. The primary finding is that this combined method achieves a task success rate of 94% or above while significantly reducing motion time and improving path smoothness compared to traditional algorithms. This work addresses the growing demand in manufacturing and logistics for robots that can adapt to varying product sizes, weights, and fragility levels without extensive retraining.
The core challenge in rapid handling of diversified products lies in the significant variation of physical characteristics among items. Fragile items required acceleration limits of no more than 0.2 m/s², whereas standard items could tolerate up to 0.5 m/s². Traditional path planning algorithms often struggle with these dynamic requirements, typically requiring model retraining when switching between product types, a process that can take 30 seconds or more. The new method aims to eliminate this delay, targeting single-task processing times of 40 seconds or less to meet the demands of modern production lines.
To address the limitations of existing path planning techniques, the study first enhances the Double Actors Regularized Critics (DARC) algorithm using deep learning technologies. The traditional DARC algorithm, while stable, suffers from poor real-time performance and insufficient adaptability to dynamic environmental changes. The researchers introduced three key improvements to the DARC framework. First, they incorporated target point coordinates into the environmental state space, allowing the robot to explore the workspace more efficiently. Second, they optimized the reward function by adding a straight-line path deviation coefficient and a timeout penalty, which helps balance path length with smoothness. Third, they integrated Gaussian noise with variable step-size actions to enhance global exploration and prevent the algorithm from getting trapped in local optima.
The second major component of the method is the Reachability Analysis-based Time Optimal Trajectory Planning (RA-TOPP) algorithm. This algorithm transforms the planned path into an actual handling trajectory that minimizes motion time while respecting physical constraints. Unlike previous methods that often neglected friction and Zero-Moment Point (ZMP) constraints, the RA-TOPP algorithm integrates these factors to ensure stable motion. By deriving second-order dynamic constraints through reachability analysis, the algorithm generates trajectories that avoid vibration and maintain the stability of the object being handled. This is crucial for preventing damage to fragile items and ensuring the safety of the robotic operation in a crowded warehouse environment.
In simulation tests, the improved DARC algorithm demonstrated superior performance compared to the original DARC, Soft Actor-Critic (SAC), and Proximal Policy Optimization (PPO) algorithms. The improved DARC achieved a minimum path length of 9.98 meters, which was 20.2% shorter than the path generated by the SAC algorithm. Convergence efficiency was also markedly better, with the improved DARC stabilizing after only 7 iterations, compared to 35 iterations for SAC and 28 for PPO. The path smoothness score for the improved DARC was 8.2, surpassing the scores of 6.5 for SAC and 7.0 for PPO. These results indicate that the enhancements to the DARC algorithm significantly improve both the efficiency and quality of path planning in complex environments.
When compared with other path planning algorithms such as IDWA, IDQN, ISSA, and RL-RSA, the improved DARC continued to show advantages. The minimum path length planned by the improved DARC did not exceed 20 meters, significantly reducing the distance traveled compared to the comparative algorithms. The number of iterations required to reach convergence was less than 20, which is substantially fewer than the iterations needed by the other methods. The obstacle avoidance trajectory generated by the research method was closer to the expected value, with an average deviation of about 0.5 meters from the expected trajectory. In contrast, the trajectories of the IDQN and ISSA algorithms were longer, with an average increase of 1.2 meters, and exhibited greater fluctuations in velocity.
The performance of the RA-TOPP algorithm was evaluated against the Cubic Polynomial Interpolation Algorithm (CPIA) under identical constraint conditions. Both algorithms were tested with a maximum acceleration of ±0.4 m/s² and a load mass of 5 kg. The RA-TOPP algorithm achieved a shorter motion time, taking approximately 1.75 seconds for a specific displacement, whereas the CPIA took about 2.0 seconds. The RA-TOPP algorithm also demonstrated better stability, with a standard deviation of acceleration fluctuations of only 0.05 m/s², compared to 0.12 m/s² for the CPIA. The ZMP point offsets for the RA-TOPP algorithm were maintained within ±0.03 meters, ensuring load balance, while the CPIA’s deviations exceeded ±0.08 meters, posing a risk of load sliding.
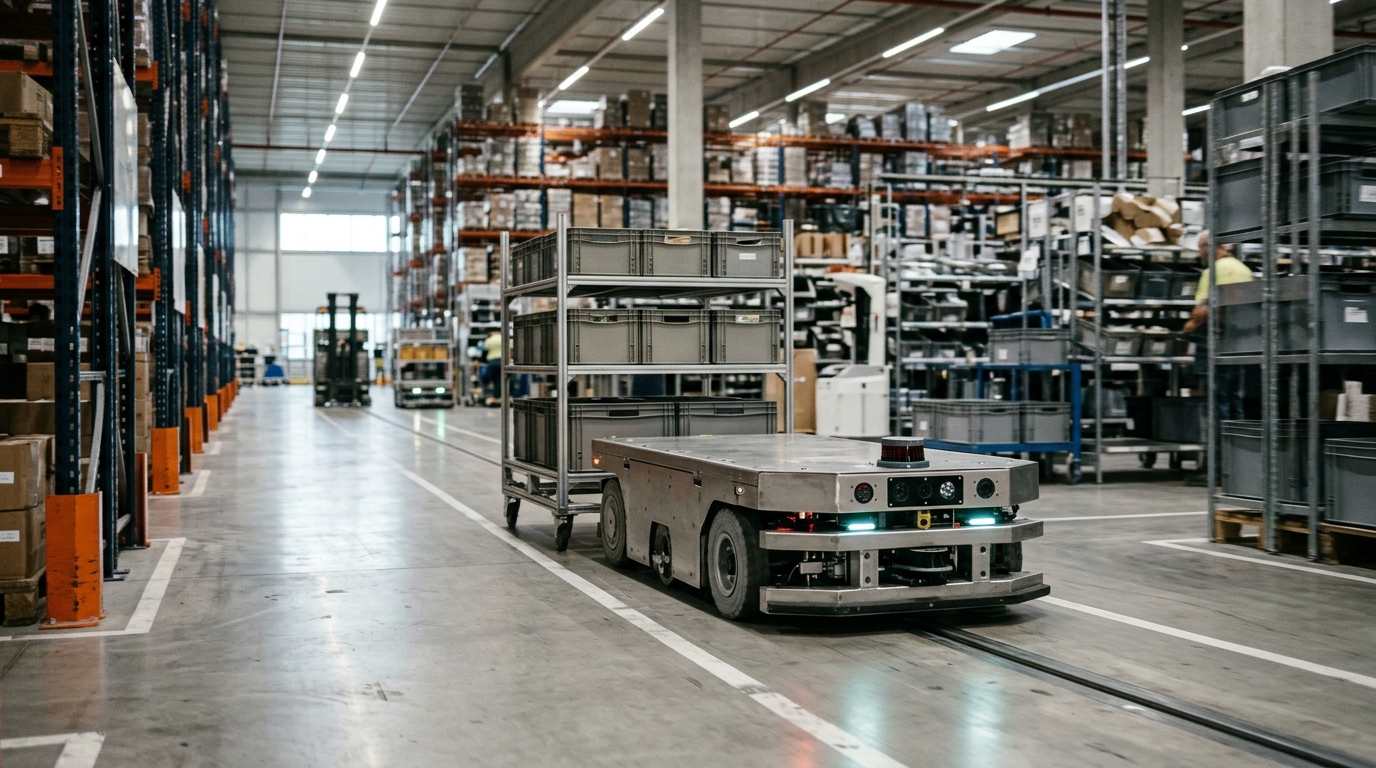
To assess the practical application of the method, the integrated algorithm was applied to an ABB IRB1200 robot in a large comprehensive logistics warehouse. The warehouse environment included dynamic factors such as shelves, channels, other handling equipment, and staff. Five representative product handling tasks were selected for testing, including small packages, medium-sized cardboard boxes, large home appliance packaging boxes, shaped decoration packaging, and fragile item packaging. The handling time for small packages was the shortest at 15 seconds, while the handling time for large household appliance packaging boxes was the longest at 35 seconds. The path length increased with product volume, ranging from 20 meters for small packages to 40 meters for large boxes. The trajectory smoothness scores ranged from 7.0 to 8.5, indicating relatively smooth overall motion.
The success rate of all tasks in the warehouse application was 94% or above, demonstrating the method’s ability to meet real-time path planning and efficient handling requirements in complex environments. Energy consumption was correlated with handling time and product weight, with large household appliance packaging boxes consuming 180 J and small packages consuming 80 J. The results verify the adaptability of the method to diversified products, as the handling times and path lengths adjusted according to the specific characteristics of each product. The study also included an ablation experiment to quantify the contribution of each innovative component, showing that the integration of target coordinates, the optimized reward function, and the friction and ZMP constraints all provided substantial performance improvements.
Despite the promising results, the study acknowledges several limitations. The method has only been verified on the ABB IRB1200 robot and has not yet been tested on other robot models such as SCARA or delta robots. The robustness in extreme environments is also a concern; when the density of dynamic obstacles in the warehouse reached 5 units per 100 m², the success rate of the path planning algorithm dropped to 85%, which is 9.6% lower than in conventional environments with lower obstacle density. Additionally, the input of product characteristics, such as weight and fragility, currently relies on manual entry, which increases operational complexity. Future work will focus on expanding the adaptability to different robot models, enhancing robustness in high-density obstacle environments through sensor integration, and developing automatic identification of product characteristics using machine vision algorithms.
Subject of Research: Optimal trajectory generation method for robots for rapid handling of diversified products
Article Title: Optimal trajectory generation method for robots for rapid handling of diversified products
Article References: Hao, Z. (2026). Optimal trajectory generation method for robots for rapid handling of diversified products. Autonomous Intelligent Systems, 6(1), Article 1. https://doi.org/10.1007/s43684-025-00122-z
Image Credits: AI Generated
DOI: 10.1007/s43684-025-00122-z
Keywords: Optimal, trajectory, generation, method, robots, rapid, handling, diversified, products, scientific research
News Source: Denise Maddox. (November 7, 2026). New Robot Algorithm Boosts Warehouse Handling Efficiency. Scienmag.