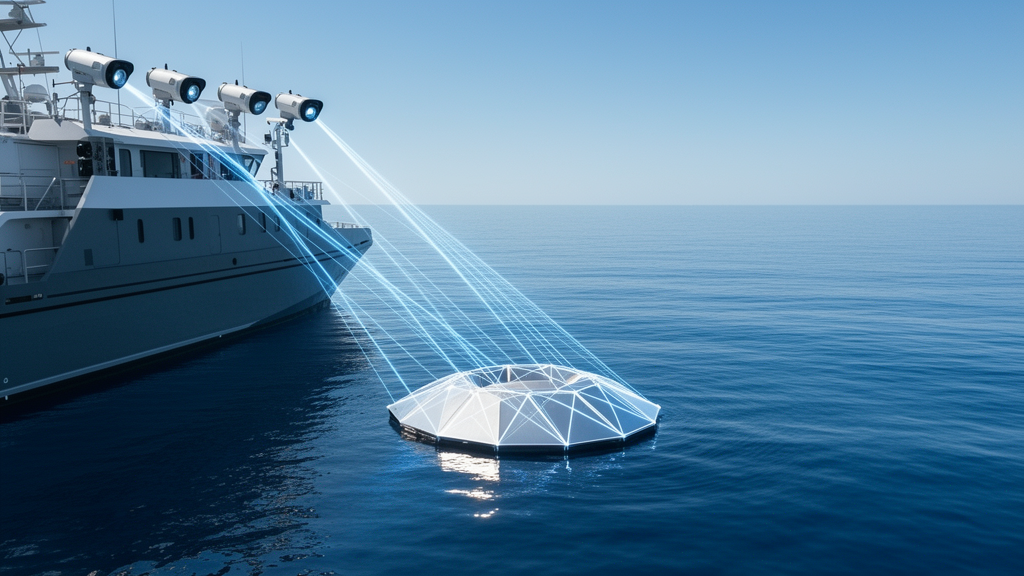
Robotic systems deployed for autonomous tasks increasingly rely on multi-LiDAR sensor configurations to enhance perception beyond the capabilities of a single sensor. However, operating multiple sensors effectively requires accurate extrinsic calibration to align their coordinate frames. A research team has introduced SIMPLE-C, an online extrinsic calibration tool specifically developed for multiple synchronized LiDAR sensors operating in feature-sparse maritime environments.
Existing extrinsic calibration methods often depend on moving the host platform or require environments rich in stationary geometric features. These requirements present severe practical obstacles in maritime settings. Consequently, standard calibration pipelines struggle to operate effectively in open-water environments.
To address these environmental constraints, the SIMPLE-C framework uses a simple moving reflective target positioned within the overlapping field of view of the sensors. The detection pipeline isolates the reflective target by pairing an intensity threshold with spatial clustering.
For extrinsic parameter estimation, the methodology uses Singular Value Decomposition to solve closed-form point cloud registration between synchronized LiDAR pairs. Because the mathematics does not require target-specific geometric calculations, the system remains quasi-invariant to target shape and dimensions. Operators can therefore calibrate the sensors using readily available reflective objects, such as standard plastic lids equipped with reflective tape or conventional warning vests.
The complete calibration architecture is designed to execute in real time, making online operational deployment feasible. To maintain reliable performance in challenging environments, the approach integrates adaptive outlier rejection mechanisms and tailored calibration weights.
Experimental validation demonstrated strong calibration precision across different operational contexts. In sparse water scenarios, the system recorded an average pairwise calibration accuracy of 5 centimeters translational Root Mean Square Error and 0.3 degrees rotational Root Mean Square Error. When evaluated under land-based testing conditions, the method achieved an even tighter translational accuracy of 3 centimeters Root Mean Square Error.
The study also evaluated SIMPLE-C against established state-of-the-art registration and calibration algorithms, including multiple Iterative Closest Point variants, GMMCalib, CROON, and Fast Global Registration. Across water-side tests, the proposed framework consistently delivered superior performance, reducing translational calibration error by up to 47 percent while maintaining rotational error levels comparable to existing baselines. The researchers have released their code and experimental dataset publicly.
Subject of Research: Extrinsic online calibration for synchronized multi-LiDAR systems in maritime environments
Article Title: SIMPLE-C: Multi-LiDAR Extrinsic Calibration using a Simple Moving Reflective Target in Feature-Sparse Maritime Environments
Article References: Rehbronn, T., Viehl, M., Vallery, H., & Reuscher, T. (2026). SIMPLE-C: Multi-LiDAR Extrinsic Calibration using a Simple Moving Reflective Target in Feature-Sparse Maritime Environments. Journal of Intelligent & Robotic Systems, 112(4), Article 110. https://doi.org/10.1007/s10846-026-02486-7
Image Credits: AI Generated
DOI: 10.1007/s10846-026-02486-7
Keywords: multi-LiDAR calibration, extrinsic calibration, maritime robotics, point cloud registration, Singular Value Decomposition, reflective targets, spatial clustering, intensity thresholding, sensor synchronization, autonomous vessels, SIMPLE-C, feature-sparse environments, outlier rejection, iterative closest point, GMMCalib, CROON, Fast Global Registration
News Source: Denise Maddox. (November 18, 2026). Moving Reflective Targets Enable Online Multi-LiDAR Calibration in Sparse Maritime Environments. Scienmag.