A comprehensive scientific review published in the European Transport Research Review examines how emerging data space architectures can overcome the critical data fragmentation bottleneck currently hindering the development of autonomous driving technologies. Authored by Kosmas Tsiakas and an international research team, the analysis establishes that the rapid evolution of autonomous mobility depends directly on high-quality datasets and robust data management frameworks that exceed the collection capacity of any single corporate actor or research institution working in isolation. While peer-to-peer data sharing mechanisms have supported early academic research and targeted algorithmic transfers, the researchers demonstrate that structured data spaces offer the necessary scalability to establish self-improving feedback loops for artificial intelligence driving models. By formally aligning the demand for operational vehicle information with the diverse offerings of distributed data providers, specialized data space frameworks can systematically channel heterogeneous sensor information into machine learning pipelines, enabling advanced automated driving systems to reach the rigorous reliability and safety thresholds demanded by complex public roadways.
To systematically evaluate the potential integration of data ecosystems into modern vehicular development, the authors frame four fundamental research questions addressing technical abstraction, cross-organizational collaboration, automotive standardization, and mutual interoperability benefits. The investigation explores whether an architectural abstraction layer can homogenize sensor feeds captured from different vehicle models operating in vastly divergent environments into unified, exploitable structures. Because autonomous driving mandates exceptionally high safety margins backed by immense, varied datasets, the study examines how industrial competitors can collectively generate, share, and validate training data without compromising proprietary advantages. Unlike conventional centralized data warehouses or data lakes that aggregate raw information in a single repository, the authors emphasize that data spaces prioritize data sovereignty, guaranteeing that data providers retain complete governance, ownership, and policy control over their assets while granting controlled access to authorized commercial consumers and external artificial intelligence developers seeking training material.
A fundamental contribution of the review centers on distinguishing the operational dynamics of intra-vehicular data from traditional extra-vehicular mobility data streams. Drawing on previous transportation research by Rettore and colleagues, the study notes that extra-vehicular data ecosystems encompassing traffic management, municipal infrastructure, smart signaling, and public transit schedules have achieved relative maturity through public frameworks like Germany’s Mobility Data Space and the European PrepDSpace4Mobility project. In stark contrast, intra-vehicular information—which includes proprioceptive vehicle telemetry like speed and positional coordinates alongside exteroceptive environmental measurements from cameras and laser scanners—remains largely restricted to proprietary silos. The researchers identify that existing taxonomies governing intra-vehicular processes require substantial modernization to reflect modern sensor suites, vehicle equipment, and software environments. Consequently, current mobility data spaces worldwide do not sufficiently support the intensive algorithmic development and rigorous validation cycles essential for deploying safe autonomous perception and navigation software.
The review critically reassesses standardized automation taxonomies, specifically examining the widely adopted six-tier classification established by SAE International ranging from Level 0 baseline systems to Level 5 full autonomy. The researchers observe that treating an automated vehicle as an isolated entity obscures the steep, asymptotic technical barrier separating Level 4 operation under restricted operational design domains from unconstrained Level 5 navigation. Because achieving Level 5 requires systems to function across infinite environmental, meteorological, and infrastructural variations, researchers such as Chen and Betz have proposed intermediate sub-categories and scenario-based taxonomies linked to infrastructure capabilities. In commercial vehicles, gradual progress along this continuum is driven by advanced driver assistance systems that rely on machine learning for lane centering, obstacle collision avoidance, automated parking, and highway cruising. Because the detection accuracy of these production algorithms remains imperfect, developers require expansive, continuous data exchanges across diverse operational domains to test edge cases and eliminate critical system vulnerabilities.
To resolve these technical barriers, the authors conceptualize a specialized autonomous vehicle data space architecture anchored in the Reference Architecture Model established by the International Data Spaces Association. Within this multi-tiered architecture, core software components regulate decentralized transactions, featuring interoperable connectors that manage physical data exchange between distributed endpoints and specialized metadata brokers that register, publish, maintain, and query system self-descriptions. An integrated Clearing House provides immutable logging services and enforces strict usage control policies, ensuring that participants comply with contractual agreements and European data protection standards. Addressing the current absence of universally adopted dataset formats, the authors highlight initiatives such as ASAM OpenLABEL and emphasize the necessity of modular transformation applications capable of translating disparate data schemas, including Robot Operating System message formats, into standardized ontologies and structured vocabularies that facilitate efficient indexing, discovery, and analytical consumption.
Managing vehicular information within a data space requires an end-to-end data lifecycle framework spanning generation, acquisition, preparation, processing, model training, and compliant disposal. As vehicles capture raw multimodal feeds through cameras, light detection and ranging sensors, inertial measurement units, and satellite navigation systems, rigorous preparation stages must eliminate errors, correct distortions, and validate structural consistency. The researchers emphasize that data quality assessment, scenario filtering, and automated anonymization must occur prior to sharing, reliably stripping sensitive personally identifiable information such as pedestrian faces and vehicle license plates. The study details an important engineering trade-off regarding where these pre-processing tasks occur: deploying filtering plugins directly on vehicle edge processors minimizes transmission bandwidth demands to external servers, whereas routing raw streams to cloud environments reduces onboard computational overhead at the expense of higher cellular transfer requirements and heightened storage burdens.
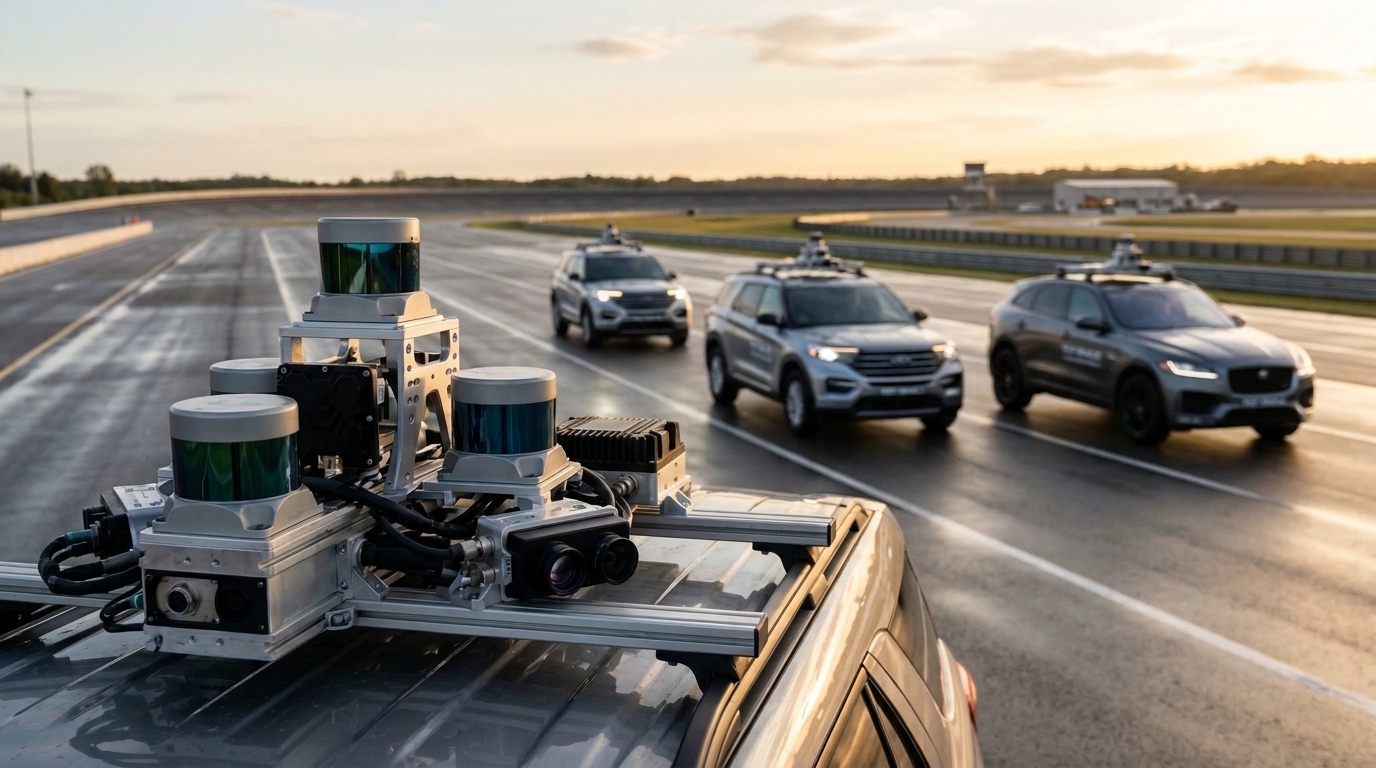
The study validates the practical feasibility of its conceptual framework by examining a real-world multi-institutional integration involving two highly complementary autonomous research platforms operating across Europe. The first platform is the iseAuto shuttle, a Level 4 autonomous vehicle developed at Tallinn University of Technology in Estonia, designed for urban passenger transport and equipped with a multi-camera array, multiple LiDAR sensors, and an interactive digital twin simulation environment. The second platform is an all-terrain vehicle developed by the Centre for Research and Technology Hellas in Thessaloniki, Greece, constructed on a Polaris Ranger chassis and fitted with three sixteen-line LiDAR units, a forward-facing stereo camera, an industrial safety laser scanner, and precision inertial measurement instruments. Operating in disparate physical environments, iseAuto collects urban transit telemetry along northern paved routes, while the CERTH vehicle maneuvers across semi-structured roads, parking facilities, and unpaved terrain.
Because neither platform independently possesses sufficient operational diversity to train universally robust perception models, the authors demonstrate three concrete collaborative use cases enabled by data space architectures. The primary use case establishes bilateral data exchange between the Estonian and Greek research groups, utilizing automated processing pipelines that deduplicate static frames, anonymize human subjects, filter key driving events, and compress recordings. The second use case leverages shared data spaces to distribute high-fidelity synthetic driving scenarios generated from diverse game-engine simulators, establishing common scenario formats that allow academic and industrial partners to systematically exchange rare hazard models and corner cases while avoiding redundant simulation development expenditures.
The third experimental use case targets comprehensive algorithmic validation across widely divergent operational design domains, addressing the financial and logistical impossibility of any single manufacturer independently capturing extreme global driving conditions. This federated scenario pooling broadens the empirical boundaries of operational design domains, ensuring that automated driving functions undergo standardized verification against authentic real-world hazards.
Looking toward future transportation ecosystems, the review outlines critical governance, privacy, and architectural mechanisms required to scale autonomous driving data spaces across the global automotive industry. Coupled with robust cryptographic identity mechanisms and continuous transaction logging, this decentralized approach protects commercial secrets while cultivating mutual technological benefits. Ultimately, the authors conclude that bridging the technological divide between mature extra-vehicular infrastructure networks and siloed intra-vehicular sensor streams represents the defining frontier for autonomous mobility, offering a governed, collaborative infrastructure capable of reducing redundant data collection, enhancing algorithmic robustness, and accelerating societal deployment of safe automated transit.
Subject of Research: Architectural frameworks and data spaces for scaling autonomous vehicle machine learning datasets
Article Title: Datasets and data spaces in the autonomous driving domain: insights and trends
Article References: Tsiakas, K., Alexiou, D., Malayjerdi, M., Bellone, M., Giakoumis, D., Abbasli, M., & Sell, R. (2026). Datasets and data spaces in the autonomous driving domain: insights and trends. European Transport Research Review, 18(1), Article 81. https://doi.org/10.1186/s12544-026-00844-y
Image Credits: AI Generated
DOI: 10.1186/s12544-026-00844-y
Keywords: autonomous vehicles, data spaces, intra-vehicular data, machine learning, interoperability, TalTech iseAuto, CERTH, operational design domains, Datasets, data, spaces, autonomous
News Source: Denise Maddox. (November 7, 2026). Data Spaces Offer Scalable Architectures for Collaborative Autonomous Vehicle AI Development. Scienmag.