Agricultural engineers have developed an artificial intelligence framework named YOLO-Gr that achieves high accuracy in recognizing foliar grapevine diseases while executing directly on low-power embedded hardware. Built upon a modified version of the lightweight YOLO26 detector, the system recorded a precision of 97.9 percent, a recall of 96.1 percent, and a mean average precision of 98.4 percent at an intersection over union threshold of 0.50. The research couples automated leaf-level disease recognition with a connected mobile, edge, and cloud architecture designed to support viticultural management under practical field conditions. By executing neural network inference on local edge devices rather than relying on remote servers, the framework enables rapid disease screening directly within vineyards, mitigating bandwidth constraints and latency issues that frequently impede smart farming deployments in rural regions.
Grapevine cultivation forms a vital socioeconomic pillar of worldwide agriculture, sustaining fresh-fruit distribution alongside commercial raisin, juice, and winemaking sectors. According to data derived from the Food and Agriculture Organization Corporate Statistical Database, global grape harvests reached roughly 75.90 million tons in 2024, with Moroccan vineyards yielding approximately 339,673 tons, representing roughly 0.45 percent of total global output. Despite this economic significance, vineyard productivity and commercial value face severe threats from foliar diseases that impair photosynthetic activity, suppress plant development, and generate substantial financial losses when symptoms escape early detection. Conventional surveillance depends heavily on manual visual inspections conducted by growers and specialists. Although visual examination remains indispensable for assessing ambiguous cases, manual monitoring is labor-intensive, time-consuming, and difficult to repeat across extensive acreages, while laboratory diagnostics require specialized equipment, trained personnel, and extended processing times.
To address the limitations of manual crop scouting, computer vision and automated deep learning models have increasingly been applied to agricultural disease identification. Early computational studies predominantly framed pathological analysis as whole-image classification, attributing a single diagnostic label to an isolated leaf centered against a uniform background. While classification models achieve strong accuracy in controlled laboratory settings, they falter in natural vineyard canopies that contain overlapping foliage, grape clusters, branches, shadows, and soil. Furthermore, classification does not locate or count multiple affected leaves across a scene. Object detection provides a more practical formulation by simultaneously predicting bounding box coordinates, disease classes, and confidence scores for individual leaves. Single-stage detectors from the You Only Look Once family have gained widespread prominence due to their real-time inference speeds and multi-scale feature representations, yet variable sunlight, motion blur, and complex foliage continue to challenge baseline models.
Deploying automated plant detectors within commercial farming operations introduces systemic hardware and communication bottlenecks that academic evaluations frequently overlook. Most computer vision research benchmarks model accuracy exclusively on high-performance desktop graphics workstations rather than addressing the operational pathway required in commercial vineyards. Relying solely on cloud-only architectures necessitates continuously transmitting high-resolution visual streams over mobile networks to remote servers. In rural agricultural landscapes, cellular reception is notoriously intermittent and bandwidth-constrained, creating communication latencies and risking system paralysis during network disruptions. Conversely, localized edge artificial intelligence allows embedded devices to process image inputs near the point of capture, ensuring uninterrupted offline operation while preserving detection functionality. Nevertheless, standalone edge hardware cannot provide long-term historical recordkeeping, centralized visual telemetry, or geographic mapping across entire properties, necessitating a unified mobile, edge, and cloud architecture that distributes computing workloads rationally among smartphones, field microcomputers, and centralized analytical dashboards.
To balance feature extraction precision against computational efficiency on low-power devices, the research team structured YOLO-Gr around the compact YOLO26 baseline, preserving its core architecture while integrating three specific enhancements. The researchers inserted Coordinate Attention into shallow backbone layers to capture directional horizontal and vertical positional dependencies, facilitating the spatial encoding of small disease spots and narrow necrotic margins. Across selected intermediate backbone and neck stages, four Convolutional Block Attention Modules were incorporated to apply sequential channel and spatial feature refinement, amplifying disease-sensitive features while suppressing background noise originating from branches, soil, and grape clusters. Furthermore, two DySample modules replaced standard fixed upsampling steps in the top-down feature fusion neck. Unlike static interpolation methods that apply fixed mathematical rules irrespective of local feature content, DySample dynamically calculates data-driven spatial offsets to reconstruct fine boundary details and irregular lesion textures during multi-scale feature aggregation.
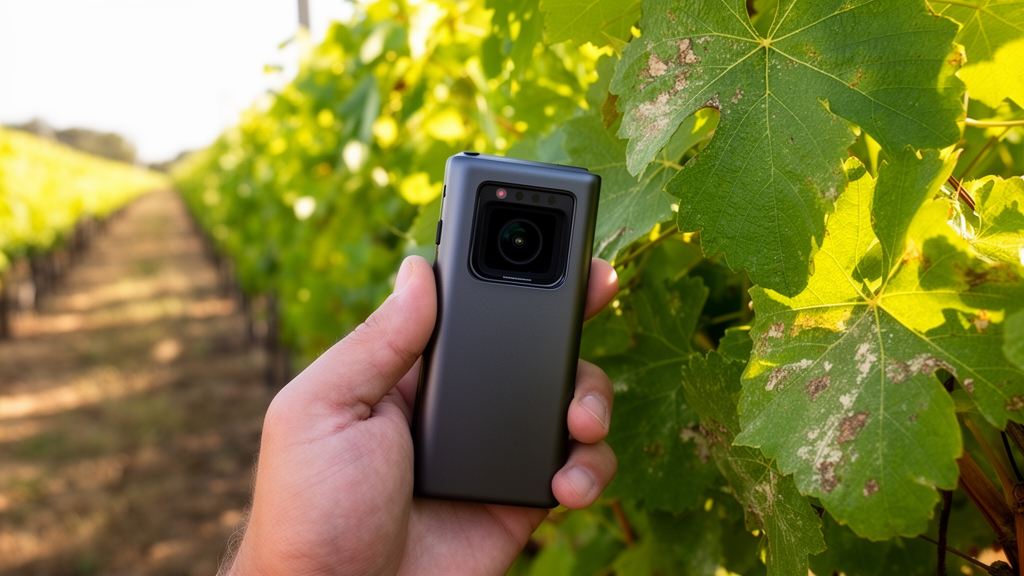
Rigorous validation of agricultural vision architectures requires empirical datasets that faithfully reflect the uncontrolled optical environments of commercial farms. The researchers constructed a dedicated field dataset comprising 8500 high-resolution images gathered directly from operational vineyards situated across the Khemisset and Meknes regions of Morocco. Rather than photographing excised leaves against artificial backdrops, the images captured intact vines displaying four distinct conditions: grape black measles, grape leaf blight, grape black rot, and healthy foliage. Black measles manifested as irregular reddish-brown interveinal discoloration fringed by chlorotic zones, leaf blight appeared as extensive marginal necrosis, and black rot presented as localized circular brown lesions with darker internal centers. To eliminate potential data leakage, the 8500 images were partitioned by discrete acquisition sessions and specific vine identities rather than via random shuffling, reserving 5950 images for training, 1700 images for validation, and 850 images for final testing.
Every visible grapevine leaf throughout the Moroccan dataset was manually delineated with rectangular bounding boxes formatted to standard object detection conventions, with each annotation undergoing visual audits to remove duplicates and correct boundaries. Before model optimization, training images underwent targeted data augmentation, including mosaic composition, horizontal flips, rotational transforms, random translation, scaling, and photometric alterations to simulate direct sunlight, overcast illumination, and varying camera perspectives without corrupting biological lesion characteristics. All experimental models were trained from scratch over 100 epochs with an input resolution of 640 by 640 pixels using an AMD Ryzen 9 7940HX processor and an NVIDIA GeForce RTX 4070 graphics card. The optimization protocol employed Stochastic Gradient Descent with an initial learning rate of 0.01, momentum of 0.937, weight decay of 0.0005, and a batch size of 16. Loss curves converged smoothly without late-stage divergence, confirming that the structural modifications did not destabilize network optimization.
Comparative benchmarking against established single-stage architectures demonstrated that YOLO-Gr achieved superior overall detection scores across the Moroccan test set. Under identical input resolutions and training settings, YOLO-Gr registered a precision of 97.9 percent, recall of 96.1 percent, an F1-score of 97.0 percent, and a mean average precision at IoU 0.50 of 98.4 percent. In comparison, baseline YOLO26 attained 97.6 percent precision, 96.0 percent recall, a 96.8 percent F1-score, and 97.7 percent mAP at IoU 0.50. YOLOv10 yielded 97.6 percent precision and 97.8 percent mAP at IoU 0.50, while YOLO11 recorded 97.7 percent precision and 98.1 percent mAP at IoU 0.50 with 96.2 percent recall. When evaluated across the stricter metric spanning IoU values from 0.50 to 0.95, YOLO26 ranked highest at 94.8 percent, followed by YOLOv10 at 94.7 percent, YOLO-Gr at 94.6 percent, and YOLO11 at 94.4 percent, showing that gains in general detection do not necessarily improve bounding-box tightness.
Granular class-level analysis of the multi-threshold metric revealed non-uniform performance shifts between the baseline detector and the improved model. YOLO-Gr elevated average precision across the 0.50 to 0.95 range for grape black measles from 94.2 percent to 94.4 percent and for grape black rot from 94.7 percent to 95.0 percent. Conversely, the model experienced decreases for grape leaf blight from 95.0 percent to 94.4 percent and for healthy foliage from 95.3 percent to 94.6 percent. Ablation trials systematically mapped the influence of each component, showing that adding Coordinate Attention alone lowered precision to 95.7 percent and mAP at IoU 0.50 to 95.9 percent. Integrating the Convolutional Block Attention Module alongside Coordinate Attention recovered performance to 97.9 percent precision and 98.2 percent mAP at IoU 0.50. Supplementing this pair with DySample yielded the full YOLO-Gr model containing 2.583 million parameters and requiring 6.2 billion floating-point operations.
Physical deployment benchmarks across computing platforms highlighted distinct operational tradeoffs between processing speed, hardware cost, and electrical power demand. Evaluated on a desktop computer, YOLO-Gr executed inferences in 11 milliseconds, generating 90.91 frames per second while consuming 115 watts for an energy efficiency of 0.79 frames per second per watt. When deployed on an NVIDIA Jetson Nano running TensorRT in half-precision format, the detector achieved latencies of 63 to 68 milliseconds and frame rates of 14.71 to 15.87 frames per second while drawing 9 to 11 watts, yielding an energy efficiency range of 1.34 to 1.76 frames per second per watt. On an 8-gigabyte Raspberry Pi 5 executing ONNX Runtime in single-precision format, processing required 93 to 95 milliseconds per image at 10.53 to 10.75 frames per second, drawing 5 to 6 watts. Consequently, the Raspberry Pi 5 exhibited the highest energy efficiency of 1.75 to 2.15 frames per second per watt at an equipment cost of roughly 220 dollars.
To close the gap between experimental model evaluation and agronomic utility, the developers embedded YOLO-Gr within a functional ecosystem comprising an Android mobile interface and a centralized ThingsBoard dashboard. Through the mobile application, field workers can acquire live camera feeds or gallery photographs, inspect local bounding box overlays, review disease management guidelines, and upload georeferenced records via wireless protocols including MQTT and HTTPS. Telemetry ingested by the cloud dashboard maps infection incidents geographically onto OpenStreetMap layers, as demonstrated during pilot monitoring at the Ferme CHAMALI site. Despite these functional milestones, the authors emphasize critical technical boundaries: comparative evaluations relied on single training runs without multi-seed variance testing, bounding boxes localized entire leaves rather than segmenting individual lesions, and wireless latency was assessed qualitatively rather than through quantitative benchmarks. Furthermore, automated management recommendations serve solely as preliminary decision-support indicators that must never supersede certified agronomic diagnoses or formal phytosanitary regulations.
Subject of Research: Edge-based computer vision and connected IoT monitoring for grapevine foliar disease detection
Article Title: YOLO-Gr: An AIoT-enabled mobile–edge–cloud framework with an improved YOLO26 for real-time grapevine disease detection and smart vineyard monitoring
Article References: Chaman, M., Maliki, A. E., Sadoune, Z., & Hadjoudja, A. (2026). YOLO-Gr: An AIoT-enabled mobile–edge–cloud framework with an improved YOLO26 for real-time grapevine disease detection and smart vineyard monitoring. Smart Agricultural Technology, 15, Article 102728. https://doi.org/10.1016/j.atech.2026.102728
Image Credits: AI Generated
DOI: 10.1016/j.atech.2026.102728
Keywords: grapevine disease detection, YOLO26, YOLO-Gr, edge artificial intelligence, precision viticulture, coordinate attention, convolutional block attention module, DySample upsampling, Raspberry Pi 5, NVIDIA Jetson Nano, ThingsBoard, foliar plant pathology, black rot, black measles, leaf blight, agricultural object detection, smart vineyard monitoring, Internet of Things
News Source: Alan Morgan. (November 15, 2026). Custom YOLO26 Architecture Improves Grapevine Disease Detection on Embedded Devices. Scienmag.