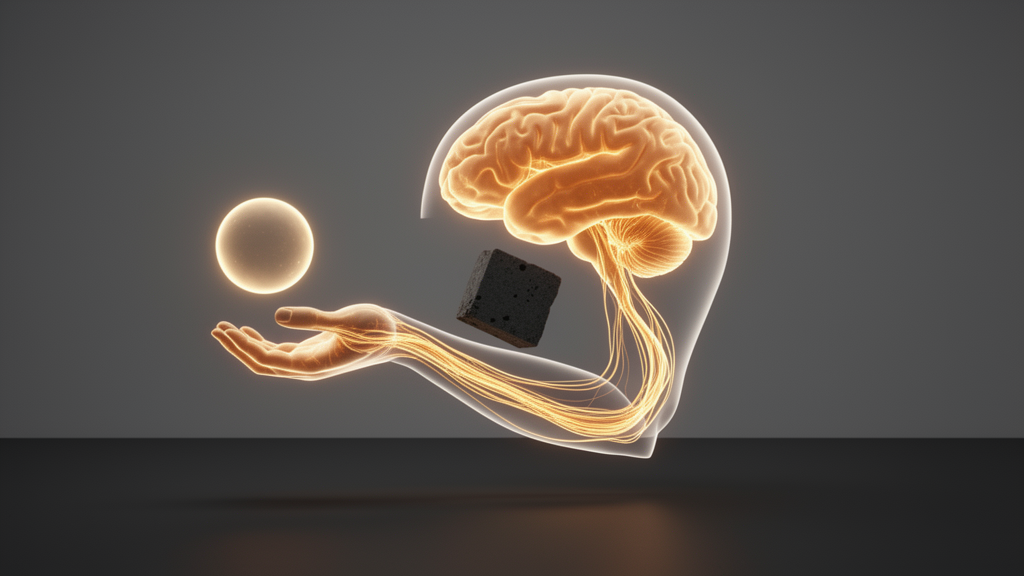
Reaching for a cup on a crowded desk is harder than it looks, because the brain must steer the hand toward a goal while simultaneously steering it away from everything in the way. A new computational study proposes a mathematical framework for how this dual demand is solved, extending stochastic optimal control theory with a novel treatment of obstacle avoidance during action selection.
The model, developed by Shan Zhong, Nader Pouratian, Paul Schrater and Vassilios Christopoulos, decomposes action selection into a weighted combination of individual control policies, each generated separately for either approaching a target or avoiding an obstacle. Rather than treating these policies as competing commands, the framework integrates value information from goals, obstacles and candidate actions into a single unified measure the authors call relative desirability. This measure dynamically determines how much each policy contributes to the overall action at any given moment, allowing the balance between approach and avoidance to shift as the body moves through a cluttered scene.
To test the framework, the researchers ran simulated target-reaching tasks in cluttered environments modeled on previous human studies. The simulations showed that the model qualitatively captures key features of human motor behavior, including how the properties of an obstacle shape movement trajectories and a transient tendency to initiate movements toward obstacles before avoiding them, a counterintuitive signature observed in human reaching data.
The authors note that the work offers new insights into the dynamic interaction between approach and avoidance behaviors and provides a basis for future studies of action selection in more complex and naturalistic settings. Because the evidence comes from simulations benchmarked against prior human experiments rather than new behavioral recordings, the framework remains a modeling contribution whose predictions await direct experimental testing.
Subject of Research: Computational modeling of obstacle avoidance during action selection and reaching movements
Article Title: An integrative computational approach for obstacle avoidance during action selection
Article References: Zhong, S., Pouratian, N., Schrater, P., & Christopoulos, V. (2026). An integrative computational approach for obstacle avoidance during action selection. PLOS Computational Biology, 22(10), e1013756. https://doi.org/10.1371/journal.pcbi.1013756
Image Credits: AI Generated
DOI: 10.1371/journal.pcbi.1013756
Keywords: action selection, obstacle avoidance, stochastic optimal control, computational neuroscience, motor control, relative desirability, reaching movements, approach and avoidance, movement trajectories, target-reaching tasks, integrative, computational
News Source: Cassandra Pierce. (October 26, 2026). Computational model shows how the brain dodges obstacles while reaching for goals. Scienmag.