Tobacco is one of China’s most economically important leaf crops, and the number of plants standing in a field is far more than a headcount. Plant count underpins planting density, field uniformity, and stand quality, all of which shape leaf yield and quality, farmers’ profits, and the competitiveness of the tobacco industry. Previous agronomic research has shown that planting density and the number of leaves retained influence tobacco’s agronomic traits, economic traits, and quality formation, making accurate plant counts a key diagnostic for missing plants, growth vigor, and yield forecasting. Yet the traditional way of obtaining that number, walking the rows and counting by hand, is reliable only for small plots or experimental areas. As modern agricultural management shifts toward precision and large-scale operations, the demand for rapid monitoring across extensive tobacco fields has outstripped what manual surveys can deliver, particularly when repeated across multiple growth stages.
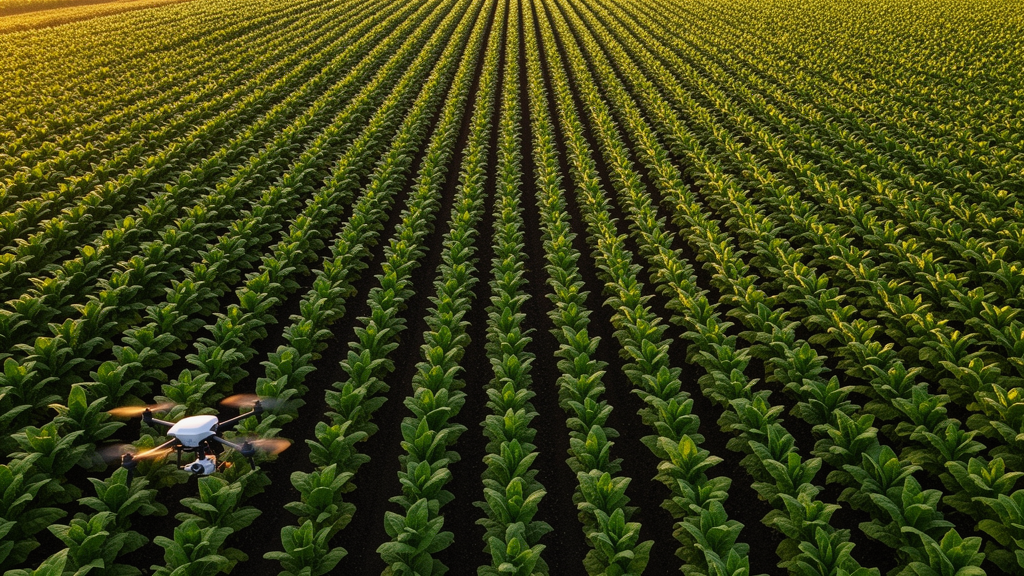
Unmanned aerial vehicle (UAV) remote sensing has emerged as a promising answer. Compared with ground surveys and satellite imagery, UAVs offer mobility, high coverage efficiency, and adjustable spatial resolution, acquiring high-resolution imagery over large areas within a short time. Deep learning methods applied to UAV imagery have already achieved strong results for counting crops such as corn, rice, cotton, wheat, and sorghum. In tobacco, earlier studies have used multispectral UAV images with object detection, an improved YOLOv8 network that reached counting accuracies of 97.20% and 96.13% in plain and mountainous fields, and an MSA-TCN model that achieved a counting performance of R2=0.996 in complex mountainous terrain. However, the dominant automatic counting approaches, object detection, density estimation, and semantic segmentation, all share a costly bottleneck: they require per-plant bounding boxes, point annotations, or pixel-level labels, and they treat individual plants as independent objects, failing to exploit the regular row structure that row-planted crops inherently possess.
A research team working in Luoping County, Qujing City, Yunnan Province, has now proposed a way around this bottleneck. Their method, conducted in Shanggule Village on the eastern edge of the Yungui Plateau at elevations of roughly 1,500 to 1,800 meters, transforms plant counting from individual plant recognition into row-structure extraction and length estimation. The insight is simple but powerful: tobacco in the study area follows standardized ridge planting with clear, continuous rows and relatively fixed row and plant spacing, so if a model can trace the center of each row and measure its total length, the plant count follows directly from geometry. Counting becomes a matter of dividing row length by average within-row plant spacing, rather than detecting every plant as a separate target.
The data pipeline began with a DJI Mavic 3M UAV carrying a 20-megapixel RGB camera and an onboard RTK positioning system. Flight missions at altitudes of 50 and 100 meters used parallel mapping routes with 80% forward and 70% side overlap at approximately 5 m/s, and the images were processed in DJI Terra into georeferenced orthomosaics. Three acquisition dates captured distinct growth stages: June 29, 2023, 57 days after transplanting, when black plastic mulch remained and weeds were sparse; July 14, 2023, 72 days after transplanting, when leaves had closed the rows; and August 23, 2023, 112 days after transplanting, when plants were denser, leaves had begun to yellow, and topping and the first harvest had occurred. The orthomosaics were cropped into non-overlapping 1024 by 1024 pixel patches and split into training, validation, and test sets at an approximate 8:1:1 ratio.
The annotation strategy is the method’s defining feature. Instead of drawing bounding boxes around each plant, annotators used the LineStrip tool in LabelMe to trace the centerline of each tobacco row as a polyline. Python scripts then expanded these line annotations into strip-shaped row-center region masks, with widths of 15 pixels for 50-meter imagery and 7 pixels for 100-meter imagery to maintain consistent physical widths across flight altitudes. Sensitivity experiments showed that a narrower physical width of approximately 20 centimeters produced lower downstream estimation errors at both altitudes, even though wider labels improved pixel-level F1 scores and IoU. The labels covered only the central strips of the rows rather than entire canopy boundaries, a design that reduces interference from leaf expansion, inter-row weeds, intercropped plants, and local occlusions. This transforms a high-cost instance-level annotation task into a low-cost structure-level one.
On the modeling side, the team treated row-center extraction as a binary semantic segmentation problem and compared four encoder-decoder networks under a unified training configuration: SegNet, which uses pooling indices for unpooling; U-Net, which compensates for shallow-layer details through skip connections; ModSegNet, which combines unpooling with cross-layer feature fusion; and DeepLabV3+, which uses atrous spatial pyramid pooling and low-level encoder features for multi-scale context. Training used a weighted binary cross-entropy loss to handle the severe class imbalance between sparse row foreground and background, the AdamW optimizer with a learning rate of 1e-4, and data augmentation including random horizontal flipping, CLAHE, color perturbation, and affine transformations. Across mixed and single-period experiments, U-Net proved the most stable overall, achieving the lowest relative counting error of 5.55% with a bias close to zero in the mixed S123 experiment, while DeepLabV3+ and ModSegNet showed larger errors and more obvious adhesion and background false detections under challenging conditions.
Converting segmented strips into counts required a careful post-processing pipeline. Because areal measurements are unstable under width variation and row adhesion, the method first applies skeletonization to reduce band-shaped regions to one-pixel-wide centerlines. The centerline is decomposed into connected segments under an 8-neighborhood rule, each segment is represented as an 8-neighborhood undirected weighted graph with edge weights of 1 for cardinal and 2 for diagonal adjacency, and endpoints are identified by node degree. When multiple endpoints exist, the pair with the greatest Euclidean distance is chosen as start and end, suppressing short spurs; closed loops are handled by selecting the most distant node pair. Dijkstra’s algorithm then extracts the shortest path as the segment’s main path, a moving average with a 7-pixel window smooths grid-aliasing fluctuations, and lengths are summed across segments. Plant spacing, estimated from 1,760 valid adjacent-plant intervals in the S1 training imagery as a mean of 61.97 centimeters with a standard deviation of 7.27, was rounded to 62 centimeters and converted to pixel scale using the ground sampling distance; each connected segment contributes a floor of length divided by spacing plus one plant. A manual topology audit found that 98 of 3,336 ground-truth row segments were falsely fragmented, a rate of 2.94%.
The results were strong, with instructive caveats. In single-stage training and testing, U-Net’s plant-count mean relative error rose from 4.43% on the early S1 data to 7.42% on the late S3 data. Controlled comparisons showed that this decline reflected both late-stage canopy changes and reduced spatial resolution at 100 meters, with resolution appearing more influential on counting. Cross-period experiments at 50 meters showed that mixed-stage training was more stable than single-stage training, and the S123-trained model kept plant-count MRE below 6% on the test datasets, including 4.36% with 97.28% accuracy on the S4 late-stage data from the same year and generalization to S5 from a different year. A spatially independent partition of the S7 dataset actually improved performance, reducing MRE from 5.10% under a random split to 2.73% with 99.70% accuracy. Most strikingly, on Plot629, a continuous 4,154-square-meter region, all training strategies kept row-length MRE below 1% and plant-count MRE between 0.69% and 0.96%, with the S1-trained model estimating 4,205 plants against a ground truth of 4,176.
The efficiency gains are equally compelling. For the same 20 images, three annotators needed an average of 203 minutes to draw individual-plant rectangular bounding boxes but only 45 minutes for row-centerline polylines, roughly a fivefold speedup, while the number of annotated objects dropped by a factor of about 13 across the test datasets. A sensitivity analysis showed the method tolerates moderate spacing variation: within plus or minus 5% spacing deviation, MRE ranged from 4.4% to 6.0% on early-stage S1 and reached 10.6% on late-stage S3, with negative deviations producing larger errors and deviations of plus or minus 15% to 20% degrading results markedly. The authors caution that the approach depends on regular row structures and a representative within-row spacing, which here was derived from UAV imagery rather than field measurements, and that dense weeds or vegetation resembling crop rows can still cause local breaks or false connections. Fields with different planting patterns would need recalibrated reference spacing. Still, for regularly planted tobacco, the method demonstrates that a cheap line drawn down the middle of a row can replace thousands of expensive boxes, offering a practical template for rapid field censuses, yield assessment, and plant counting in other regularly row-planted crops.
Subject of Research: A low-cost annotation-based method for tobacco row structure extraction and plant counting from UAV imagery
Article Title: A low-cost annotation-based method for tobacco row structure extraction and plant counting
Article References: Luo, S., Lin, H., Qiang, Z., Zhang, S., Zhao, T., Li, K., Dong, Y., & Wang, K. (2026). A low-cost annotation-based method for tobacco row structure extraction and plant counting. Smart Agricultural Technology, 15, Article 102634. https://doi.org/10.1016/j.atech.2026.102634
Image Credits: AI Generated
DOI: 10.1016/j.atech.2026.102634
Keywords: tobacco, plant counting, UAV remote sensing, deep learning, semantic segmentation, U-Net, low-cost annotation, row structure extraction, precision agriculture, Yunnan, row length estimation, annotation efficiency
News Source: Alan Morgan. (October 24, 2026). Counting Tobacco Plants From Row Lines: A Low-Cost Annotation Method for UAV Field Surveys. Scienmag.