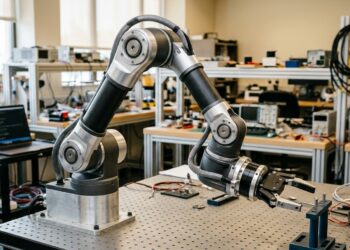
Cyclic Perturbation Solver Resolves Redundant Robotic Inverse Kinematics Without Jacobian Matrices
Researchers designed a Jacobian-free inverse kinematics algorithm for seven-degree-of-freedom robotic arms using norm-limited cyclic perturbations to minimize task residuals and ...