Published in Discover Robotics, the study introduces a system that combines symbolic logical reasoning with algebraic tensor decomposition to improve decision-making in dynamic, adversarial environments. The primary objective of the work is to address the limitations of traditional multi-robot coordination methods, which often struggle with the non-stationary objectives and rapid spatial-temporal changes inherent to robotic soccer. By leveraging structured data from simulated matches, the proposed method allows a team of heterogeneous robots to reason over incomplete histories and predict collaborative behaviors such as passing, defending, and role-switching with greater robustness.
The core of the framework is the Soccer Robot Collaboration Treebank, or SRCT, a syntactically annotated corpus designed to encode robot experiences during simulated matches. Drawing inspiration from linguistic treebanks used in natural language processing, the SRCT represents play-by-play histories of robot behaviors as formally parsed interaction statements. Each statement in the treebank is paired with a syntactic tree generated from a domain-specific formal grammar. This structure abstracts tactical sequences into a machine-interpretable form, allowing the system to convert raw match logs into structured symbolic actions. The grammar includes specific production rules for various collaborative semantics, such as individual actions, temporal collaborations, and role shifts triggered by specific stimuli like opponent pressure or lost possession.
To model the complex tactical behaviors of the soccer robots, the researchers utilize Multidimensional Relational Structures, known as MDRSs. These structures serve as the logical backbone of the framework, encoding inter-robot task dependencies as high-order relational templates. An MDRS is defined as a tuple consisting of a signature and a tensor. The signature specifies the symbolic schema of the relation, including the relation symbol, the sorts of arguments such as robot or action, and the constant symbols representing specific entities in the domain. The tensor component quantitatively encodes the interaction patterns, with each entry representing the strength, frequency, or probability of a specific relation among participating entities. For example, a tensor entry might indicate a high probability that a specific striker passes to a specific midfielder before a shot attempt.
The learning process involves extracting MDRS signatures from the SRCT and constructing high-dimensional tensors based on these symbolic mappings. The system uses a probabilistic generative model to populate these tensors, treating the SRCT as a collection of symbolic observations from a multinomial distribution. A Dirichlet prior is assumed to estimate the latent probability vector, which helps stabilize inference and prevents overfitting to infrequent or noisy samples. This approach is particularly important in robotic soccer, where many valid role-task associations may never be explicitly observed during training due to the vast number of possible combinations. The resulting tensors are inherently sparse, containing many undefined entries for unobserved data, which necessitates a method for completing the missing information.
To address sparsity and infer missing entries, the framework applies Non-Negative Tensor Decomposition, or NTD. NTD performs tensor completion by filling in unobserved entries and compressing the tensor into latent components. The researchers employ the Fast Hierarchical Alternating Least Squares algorithm, adapted to handle missing values using a binary mask tensor. This optimization minimizes the reconstruction error for known entries while ignoring missing ones during training, allowing the model to predict those missing values during inference. The decomposition uses a low-rank approximation where all terms are constrained to be non-negative, ensuring the interpretability and semantic consistency of the latent components. Each factor matrix encodes latent embeddings for the corresponding sort, such as robot or action, enabling the system to identify recurring sub-tactics and latent strategy patterns.
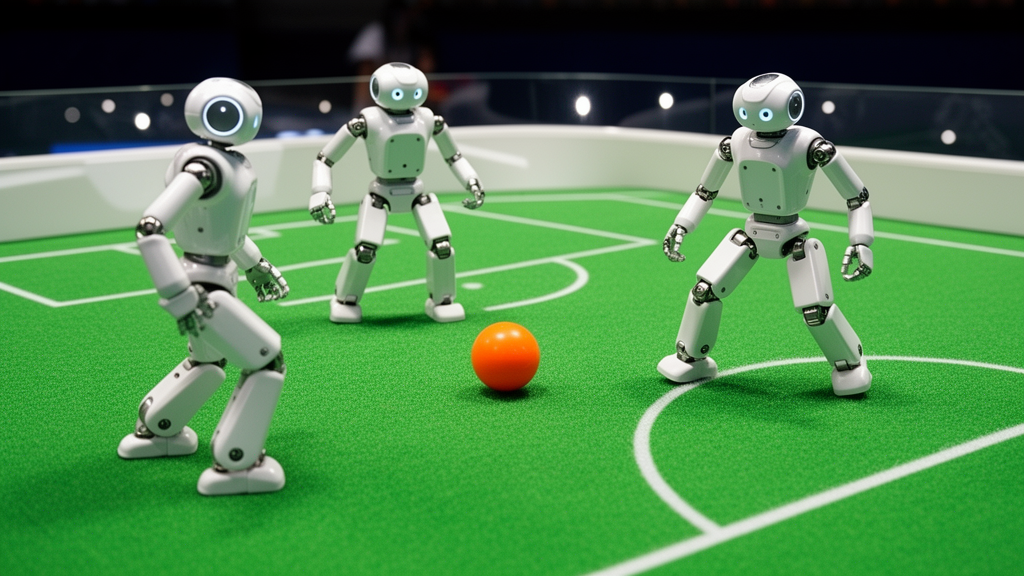
The proposed framework was validated through a series of simulation experiments conducted in the Webots robotics environment. The simulation modeled a simplified soccer field adhering to RoboCup Small Size League standards, featuring five wheeled robots: two strikers, two midfielders, and one goalkeeper. The environment included ball physics, dynamic friction, and vision-based localization for tracking the ball and opponents. Inter-robot communication was limited to 2 Hz to simulate real-world latency, and each robot had preprogrammed low-level actions such as pass, shoot, dribble, and intercept. High-level decisions were governed by the MDRS-based inference engine, which used the decomposed tensors to select optimal collaborators and assign roles in real-time.
The experimental scenarios focused on distinct collaborative behavior patterns, including collaborative passing and shooting, role switching under pressure, and defensive recovery followed by a counterattack. In the passing scenario, the system had to identify the best receiver for a striker using inferred knowledge. In the role-switching scenario, a midfielder transitioned to a defensive role after losing ball possession due to opponent proximity. The results demonstrated that the system consistently inferred correct task partners, even when the specific collaboration tuple was never explicitly observed in the training data. Role switching was responsive to environmental stimuli, with correct transitions observed in over 85% of trials. The tensor decomposition generalized well from only 70% of the SRCT entries, supporting robust link prediction for unobserved behaviors.
Quantitative validation compared the proposed MDRS-NTD framework with two baseline tensor-based models: the Tucker Temporal Model and the GETD framework. The MDRS-NTD framework achieved the lowest reconstruction error of 0.148 and the highest link prediction accuracy of 92.3% across five independent runs. These results indicate that the explicit encoding of role-action semantics and the integration of temporal context contribute to superior representational fidelity and predictive accuracy. The framework also demonstrated an effective trade-off between accuracy and computational efficiency, with runtime scaling nearly linearly with the number of role-action pairs. This scalability profile suggests suitability for deployment in real-time multi-agent robotic systems where both reasoning precision and computational efficiency are critical.
One of the significant advantages of the proposed system is its interpretability and decision transparency. Unlike black-box neural models, the MDRS-NTD framework allows human operators to understand why a particular robot was selected as a collaborator by inspecting the relevant tensor fibers or slices. This transparency facilitates debugging, strategy refinement, and human-robot collaboration, which are essential in domains where trust and explainability are paramount. The modular architecture also allows for the integration of new interaction types by defining additional MDRS signatures and enriching the SRCT. This extensibility makes the framework applicable beyond robotic soccer to other multi-agent systems, such as warehouse robot task assignment, coordinated vehicle platooning, and multi-drone mapping operations.
Despite the encouraging results, the study acknowledges several limitations. The construction of the SRCT is currently manual or semi-automated, and scaling to large datasets or live logging systems would require integration with natural language processing pipelines or structured event extractors. The evaluation focused on a fixed formation of five robots, and generalization to larger or dynamically evolving formations remains an open direction for future research. Additionally, the current model does not fully address failure recovery under extreme communication dropout or actuator malfunction. Future work aims to investigate resilient policy adaptation under degraded conditions and incorporate uncertainty-aware latent inference using Bayesian tensor factorization to improve risk-sensitive decision-making. The researchers also plan to explore the transfer of latent collaboration models between teams with different robot configurations and validate the framework in real-world physical robot deployments.
The study builds directly on prior work by Gianni and Uddin, who introduced a Non-Negative Tensor Decomposition-based framework for cooperative heterogeneous multi-robot systems. That earlier approach modeled collaboration as Multidimensional Relational Structures to capture temporal and spatial relations among agents. The current research extends this foundation specifically to the domain of wheeled soccer robots, aiming to uncover latent coordination patterns in competitive environments. By applying tensor-driven relational modeling to this new context, the authors address the gap where existing symbolic and relational models had not been tested in adversarial, continuous, and dynamic domains. This extension allows the framework to handle the fluid role transitions and proactive teamwork essential for success in robotic soccer, moving beyond static or structured coordination tasks.
The simulation environment was configured to mimic real-world constraints that often disrupt robot coordination. Inter-robot communication was deliberately limited to a frequency of 2 Hz to simulate latency, while vision-based localization was used for tracking the ball and opponents. The field adhered to RoboCup Small Size League standards but utilized wheeled robots rather than legged ones. Each robot operated with preprogrammed low-level actions, including passing, shooting, dribbling, intercepting, defending, and recovering. High-level decisions were not hard-coded but were instead governed by the MDRS-based inference engine. This setup allowed the researchers to evaluate how the system copes with sensor noise and communication delays, which are critical factors in overall system performance when robots operate under partial observability.
Computational efficiency was a key consideration in the design of the MDRS-NTD framework. The system was tested on an Intel i7 10th Gen CPU with 32 GB of RAM, using Python 3.12 and NumPy-based tensor operations. The average runtime per training epoch was analyzed to ensure the model remained viable for real-time applications. While higher-order tensor frameworks like GETD offer greater expressiveness, they incur higher computational costs due to additional tensor contractions. The MDRS-NTD model achieved an optimal balance, running slightly slower than conventional decompositions due to symbolic-tensor alignment but remaining faster than more complex higher-order frameworks. This efficiency is crucial for deployment in real-time multi-agent systems where reasoning precision must be maintained without excessive computational delay.
The choice of tensor rank significantly influenced the model’s performance during validation. Increasing the decomposition rank from 10 to 30 substantially reduced the reconstruction error, indicating better model expressiveness. However, the benefits plateaued beyond a rank of 40, suggesting diminishing returns for higher complexity. Consequently, a rank of 25 was selected as the optimal parameter across all experiments. The near-linear scaling of runtime with the number of role-action pairs further supports the framework’s stability for medium-scale robotic teams, confirming its potential for broader application in cooperative autonomy domains.
Subject of Research: Role and task allocation framework for wheeled soccer robot collaboration with latent knowledge estimation
Article Title: Role and task allocation framework for wheeled soccer robot collaboration with latent knowledge estimation
Article References: Uddin, M. S. (2025). Role and task allocation framework for wheeled soccer robot collaboration with latent knowledge estimation. Discover Robotics, 1(1), Article 14. https://doi.org/10.1007/s44430-025-00014-0
Image Credits: AI Generated
DOI: 10.1007/s44430-025-00014-0
Keywords: Role, task, allocation, framework, wheeled, soccer, robot, collaboration, latent, knowledge, estimation, scientific research
News Source: Denise Maddox. (November 11, 2026). Soccer Robots Learn Team Tactics via Tensor Decomposition. Scienmag.