


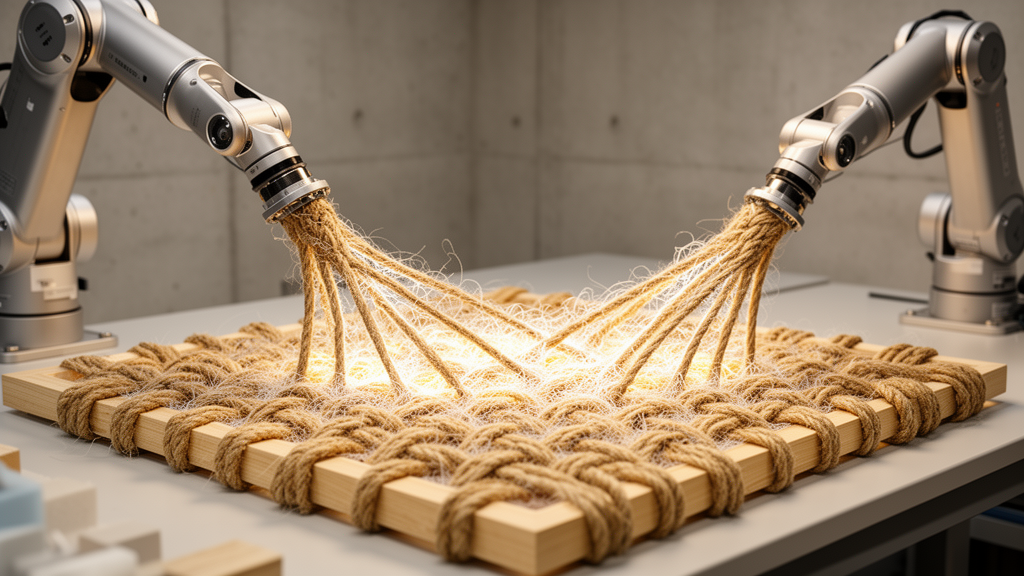
Researchers have combined robotic fiber winding with fungal growth to produce large, mold-free building components from braided hemp rope, and they have now reported the full pipeline in detail, from digital design to a finished two-square-meter panel. The study, published in the journal Architectural Intelligence, introduces what the authors call Braided Mycelium Composites, a class of bio-based materials in which a robotically deposited hemp scaffold is consolidated not by synthetic resin but by living mycelium, the vegetative network of filamentous fungi. The work was carried out by Tiziano Derme, Alim Battal, Nicolas Boscoboinik, Francis W. M. R. Schwarze and Benjamin Dillenburger, and it addresses a persistent bottleneck in mycelium-based construction: the reliance on rigid molds, batch production and discontinuous fabrication methods that limit geometric freedom and reinforcement continuity.
Mycelium-based composites have attracted sustained attention in architecture and construction because fungal mycelium can grow through lignocellulosic waste such as straw, sawdust or hemp and bind it into lightweight, biodegradable panels. Commercial products based on this logic have reached the market, mainly as thermal and acoustic insulation boards. But the dominant production route remains mold-based: the external geometry is defined by a rigid form, and material performance is tuned through substrate selection, moisture content, incubation conditions and post-processing. According to the authors, this logic restricts customization, makes graded material distributions difficult to achieve, and decouples form-giving from reinforcement design. Mycelium alone also lacks the tensile strength needed for load-bearing or tension-active applications without additional support.
The new method tackles these constraints with three linked elements. First, a raster-based computational design tool converts a target two-dimensional or three-dimensional boundary into deposition-relevant fields, encoding local fiber density, orientation, porosity, layer hierarchy and crossover distribution as grayscale values on a control grid. Higher raster values map to more fiber layers, producing denser, heavier regions with more frequent rope intersections, while lower values yield open, porous configurations. Grid resolution is calibrated against rope diameter and target curvature radius so that every specified pattern remains physically feasible. The system accommodates rope diameters from 15 to 60 millimeters, allowing variation in resolution, curvature conformity and material density before anything is fabricated.
Second, the digital braid sequence is compiled into robot target points for a six-axis industrial arm working around a modular pin-loom system. Toolpath planning must satisfy robot kinematics and rope mechanics simultaneously: minimum turning radii, tension, twist and friction all constrain what can be executed. A simulation-based collision check governs the trajectory, and during diagonal transitions between non-adjacent anchors the robot substitutes straight moves with half-round, curvature-controlled detours that encircle intermediate anchors at a safe distance. Rope feed rate is synchronized with tool-center-point speed to avoid tension spikes or slack accumulation. Because hemp yarn behaves unpredictably, a human operator assists deposition in real time, pressing and repositioning the extruded loops along the vertical axis to maintain alignment with the digital toolpath, a hybrid arrangement that also allows a standard industrial arm to be used without excessive payload capacity.
Third, the dry scaffold is biologically stabilized through a five-phase protocol tracked as states t1 through t5. After fabrication, the scaffold is pasteurized through a combined thermal-chemical treatment with short UV-C surface exposure to suppress competing moulds and standardize substrate condition. It is then inoculated with a liquid fungal culture and incubated for two to four weeks in a climatically controlled clean-room environment with tray bioreactors, held at 25 to 26 degrees Celsius and 70 to 80 percent relative humidity. Finally, the component is harvested and air-dried at 25 to 26 degrees Celsius and 30 to 40 percent relative humidity until constant mass, halting biological activity and locking the geometry through dehydration-driven stiffening. No polymer matrix or chemical binder is used at any stage; mycelium immobilizes rope-rope contacts, improves shear transfer at crossings and stabilizes the as-fabricated form.
To validate the pipeline at architectural scale, the team fabricated a full-scale panel measuring 2000 by 1000 millimeters. Robotic deposition laid down 165 meters of hemp rope with a nominal diameter of 28 millimeters, producing a dry scaffold weighing 83.0 kilograms, an areal density of 41.5 kilograms per square meter. At a tool speed of 25 millimeters per second, ideal deposition time was about 28 minutes per square meter, excluding pauses and detours. Of 402 planned turns, 34 required operator support, yielding an autonomous turn-closure rate of 91.5 percent. Geometric fidelity was quantified by comparing the digital model with the physical scaffold: mean deviation was 13.4 plus or minus 9.0 millimeters in the dry state, rising to 15.7 plus or minus 10.1 millimeters after stabilization, with the maximum deviation increasing from 29.0 to 38.0 millimeters. The authors interpret this as partial rather than complete geometric stabilization and call for improved fixturing and phase-based quality control in future prototypes.
Mass evolved dramatically across the stabilization phases. From the dry braided state, mass rose to 137.0 kilograms after pasteurization and 138.0 kilograms after inoculation, then fell to 63.0 kilograms after incubation and 58.0 kilograms at final harvest, a 30.1 percent net reduction relative to the initial dry state. Areal density correspondingly dropped from 41.5 to 29.0 kilograms per square meter. Linear rope specimens tested with two fungal strains, Trametes pubescens and Ganoderma lucidum, showed largely parallel trajectories: a marked mass increase of roughly 65 percent during wet treatment, then a dominant reduction during incubation, with changes between the last two phases minor, indicating the process reached a steady state. The authors note that these moisture-driven swings between wet and dry states increase handling loads and sensitivity to deformation, making stabilization logistics, not robotic deposition, the true bottleneck at scale.
Mechanical testing examined the composite at rope scale. Single-rope specimens colonized for 60 days were tested in three-point bending over a 142-millimeter span, five specimens per strain. The bending-derived effective flexural modulus was 19.31 plus or minus 10.83 megapascals for Ganoderma lucidum and 25.73 plus or minus 3.92 megapascals for Trametes pubescens, a difference that was not statistically significant, though the Ganoderma specimens showed substantially higher scatter. Apparent densities were 689.5 plus or minus 24.8 and 662.7 plus or minus 12.4 kilograms per cubic meter respectively, also not significantly different. Failure behavior was consistent across all specimens: localized indentation and crushing beneath the loading nose, accompanied by wrinkling and cracking of the consolidated mycelial rind, with progressive damage accumulation rather than a single brittle fracture of the hemp rope. The authors frame the material as a junction-controlled composite in which the continuous braided rope network carries tensile loads while mycelium locks the junctions, and they caution that time-dependent creep was not quantified because no sustained-load hold tests were performed.
Acoustic performance was more modest. Normal-incidence absorption measured with a two-microphone impedance tube following ISO 10534-2 reached only about 0.10 to 0.17 at 1.6 kilohertz, below the 0.4 threshold associated with speech intelligibility, with Trametes pubescens consistently outperforming Ganoderma lucidum. Benchmarked against published data on molded mycelium composites, such as cardboard-based Pleurotus panels reporting mean absorption around 0.51 at 500 hertz, the tested configuration sits at the lower end, and the authors explicitly state it should not yet be presented as a competitive acoustic absorber. They attribute the gap to porous-absorber physics: the dense cylindrical test coupons represent a tighter configuration than the braided prototypes, and higher open porosity, greater thickness, junction density and air-gap backing are identified as the main improvement pathways, to be verified on full-scale braided panels in anechoic chamber testing. The study’s stated limitations include the multi-week stabilization time, phase-dependent warping, limited sample sizes and the need for creep, connection and long-term serviceability testing, positioning the method as a replicable fabrication framework whose structural and acoustic performance now depends on tuning braid topology, placement tolerances and growth conditions.
Subject of Research: Robotic braiding of hemp rope scaffolds consolidated by fungal mycelium into bio-based building components
Article Title: Braided mycelium composites: an integrated robotic design-to-fabrication method for bio-based fibrous building components
Article References: Derme, T., Battal, A., Boscoboinik, N., Schwarze, F. W. M. R., & Dillenburger, B. (2026). Braided mycelium composites: an integrated robotic design-to-fabrication method for bio-based fibrous building components. Architectural Intelligence, 5(1), Article 20. https://doi.org/10.1007/s44223-026-00126-6
Image Credits: AI Generated
DOI: 10.1007/s44223-026-00126-6
Keywords: mycelium composites, robotic fabrication, hemp rope, bio-based materials, coreless winding, three-point bending, acoustic absorption, digital fabrication, fungal binder, architecture, sustainable construction, biogenic stabilization
News Source: Roger Howard. (October 29, 2026). Robots braid hemp rope into mold-free building panels bound by living fungus. Scienmag.



