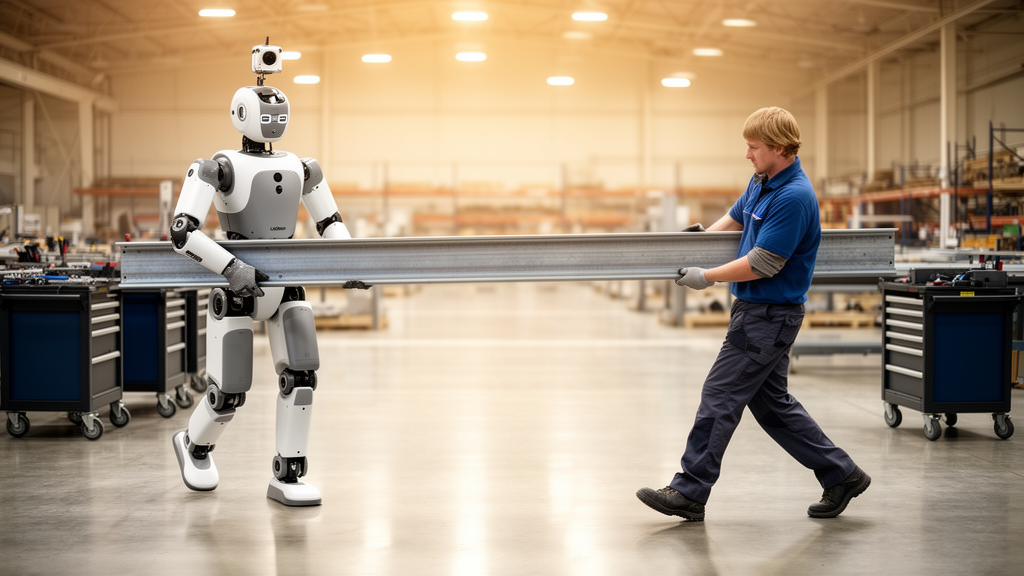
Engineers have demonstrated a control framework that lets a humanoid robot carry an object alongside a human partner, handling not only straight-line moves but also turns and curved, semi-circular paths of the kind that arise naturally when two agents share a load. The system was validated in real-world experiments on the Digit humanoid platform.
The framework rests on three components. A high-level planner generates dynamically feasible footstep plans by combining a model the researchers call the Interaction Linear Inverted Pendulum (I-LIP) with an admittance model and a model predictive control formulation. At the lowest level, a quadratic-programming-based whole-body controller executes those plans while accounting for the coupled dynamics of the humanoid and the object being carried together.
Between the two sits a stiffness modulation mechanism, which regulates the interaction between the robot and the object. Its role is to ensure convergence to a desired relative configuration, defined by the distance between the object and the robot’s center of mass.
To measure how well the collaboration actually works, the team proposes an efficiency metric that captures both task performance and inter-agent coordination. According to the authors, this metric highlights the role of compliance in collaborative tasks and offers insights into desirable trajectory characteristics across both the high- and low-level control layers.
The reported behaviors include translation, turning, and combined motions such as semi-circular trajectories, demonstrating versatility beyond simple point-to-point carrying. Because the planner explicitly supports both translational and rotational motion, the framework targets the full range of movements fundamental to co-transport scenarios rather than a single scripted task.
The I-LIP planner and the coupled-dynamics whole-body controller are designed to handle exactly that coupling between balance and shared load.
Subject of Research: A control framework enabling humanoid robots to collaboratively transport objects with human partners, validated on the Digit platform.
Article Title: Efficient and compliant control framework for versatile human-humanoid collaborative transportation
Article References: Kumbhar, S. S., Kulkarni, A. M., & Artemiadis, P. (2026). Efficient and compliant control framework for versatile human-humanoid collaborative transportation. Autonomous Robots, 50(4), Article 45. https://doi.org/10.1007/s10514-026-10271-6
Image Credits: AI Generated
DOI: 10.1007/s10514-026-10271-6
Keywords: humanoid robots, collaborative transportation, human-robot interaction, compliant control, I-LIP, whole-body control, stiffness modulation, Digit, model predictive control, co-transport, Efficient, compliant
News Source: Denise Maddox. (October 28, 2026). Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation. Scienmag.