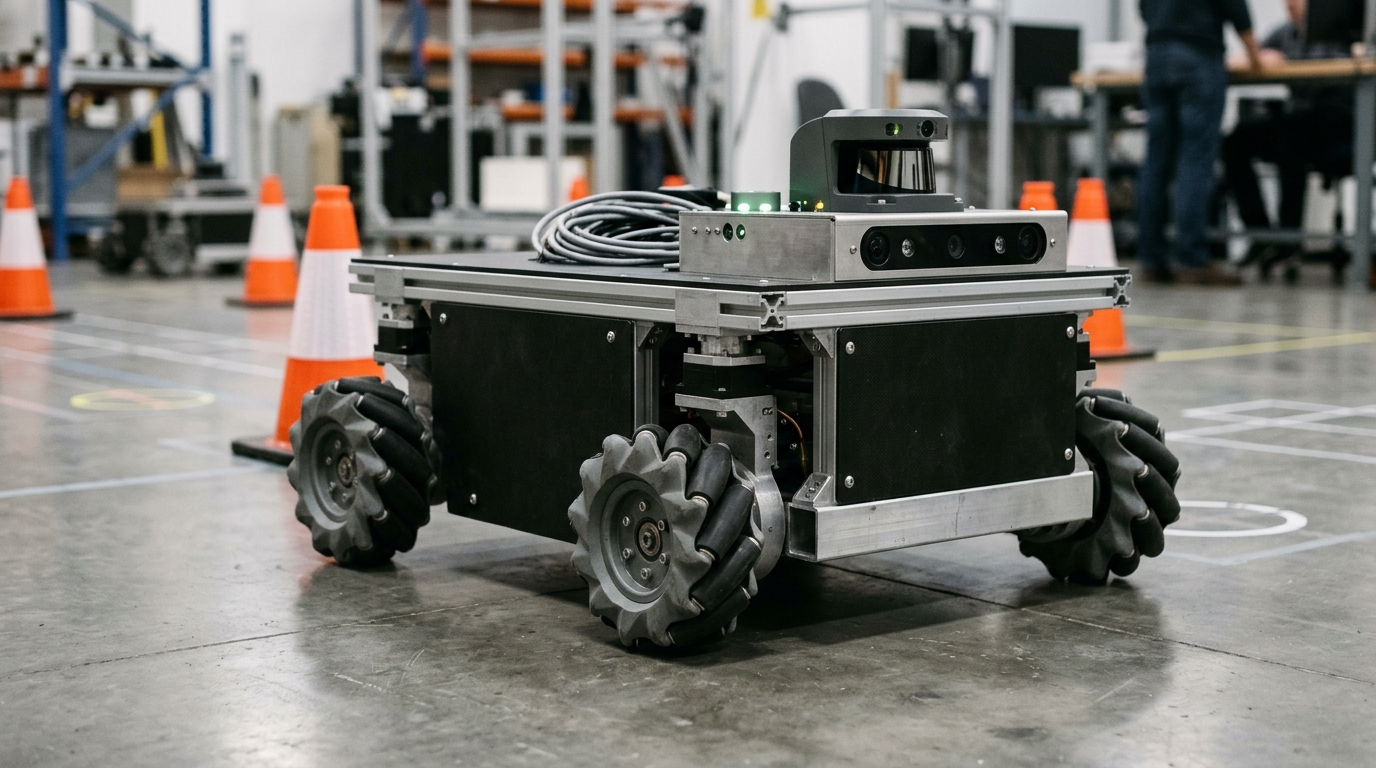
Researchers have introduced a CBF-critic-based, heading-aware Model Predictive Path Integral (MPPI) navigation architecture designed for omnidirectional mobile robots operating in narrow environments. The framework was developed to support the growing deployment of autonomous dual-arm wheeled humanoid robots as well as heavy-duty logistics robots, where both collision-free path execution and dynamic stability are critical operational requirements. In experimental evaluations, the newly proposed control scheme attained a 100 percent collision-free navigation success rate across both simulated environments and physical hardware trials.
The research addresses fundamental geometric and operational constraints inherent to four-wheel independent steering (4WS) platforms. Although four-wheel independent steering delivers superior maneuverability compared to conventional steering configurations, these platforms possess asymmetric rectangular footprints. When governed by traditional controllers that rely on circular approximations of the robot’s physical dimensions, this geometric mismatch frequently causes severe physical collisions and excessive variations in heading while the platform attempts to navigate confined areas.
To resolve these geometric shortcomings, the proposed navigation framework represents the robot’s perimeter as an Oriented Bounding Box (OBB). Within this geometric formulation, the researchers integrated Control Barrier Functions (CBF) directly into the Model Predictive Path Integral framework. This mathematical integration functions to approximate collision avoidance as a strict hard constraint rather than a soft penalty, effectively mitigating the optimization cost conflicts that typically arise when balancing multiple competing navigation objectives.
To complement the barrier function formulation, the architecture incorporates an online Adaptive Heading Critic driven by real-time LiDAR perception data. Operating continuously during navigation, this component dynamically enforces heading alignment as the robot negotiates narrow passages. By actively regulating orientation based on immediate environmental sensing, the critic effectively suppresses unnecessary angular jerk, preserving smooth trajectory motion and preventing sudden rotational movements.
The effectiveness of the architecture was demonstrated through extensive validation testing conducted in simulation and on real-world four-wheel independent steering robotic hardware. In addition to recording zero collisions across all experimental scenarios, the system proved particularly effective during a region-locked parallel parking benchmark. In that trial, the proposed framework maximized dynamic stability by reducing the robot’s maximum angular jerk by approximately 91.6 percent relative to a conventional soft-constraint baseline controller.
Subject of Research: Collision-free navigation and dynamic stability control for omnidirectional mobile robots
Article Title: CBF-Critic-Based Heading-Aware MPPI Navigation for Omnidirectional Mobile Robots
Article References: Kim, T., Seo, H., & Lee, C. (2026). CBF-Critic-Based Heading-Aware MPPI Navigation for Omnidirectional Mobile Robots. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02485-8
Image Credits: AI Generated
DOI: 10.1007/s10846-026-02485-8
Keywords: omnidirectional mobile robots, model predictive path integral, control barrier functions, oriented bounding box, four-wheel independent steering, adaptive heading critic, angular jerk reduction, collision avoidance, dynamic stability, narrow passage navigation, real-time LiDAR, parallel parking scenario, dual-arm wheeled humanoid robots, logistics robots, hard constraint approximation, soft-constraint baseline, robot footprint modeling
News Source: Denise Maddox. (November 16, 2026). New Controller Stops Collisions and Cuts Angular Jerk in Omnidirectional Robots. Scienmag.