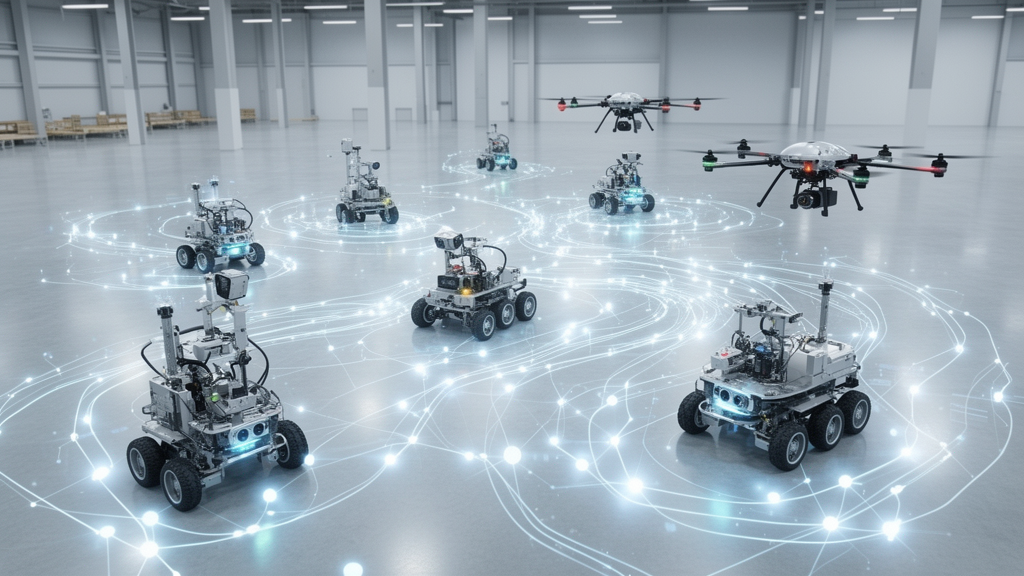
A research team has introduced a supervised deep learning framework capable of rapid inference to predict the operational performance of heterogeneous multi-robot teams directly from their structural composition.
The operational effectiveness of robotic teams relies heavily on multiple interdependent parameters, including overall team size, the specific capabilities of individual robotic agents, operational synergies between team members, and the coordination strategies deployed during task execution. However, existing research within multi-robot task allocation frequently operates under the assumption of pre-established teams, restricting analytical focus to the allocation and optimization of available resources.
This prevailing assumption in task allocation literature has historically limited the ability to design teams from a broad range of diverse robots or to select the most suitable team configuration from a collection of potential candidate setups. Predicting a team's performance in a given mission based on its composition has significant implications for selecting or designing multi-robot teams, helping optimize performance while minimizing costs.
To resolve these composition evaluation challenges, the authors proposed a novel fast inference method using supervised learning to estimate team performance in multi-robot task allocation scenarios. The investigation considered a general task allocation problem formulated for missions distributed spatially across an operational domain. For systematic empirical evaluation, the researchers constructed a comprehensive dataset spanning varied problem instances, employing two distinct algorithmic solvers to generate mission plans and evaluating five separate performance metrics derived directly from the computed solutions.
Experimental results confirmed that deep neural network architectures can accurately predict team performance metrics derived from both solvers. Specifically, long short-term memory recurrent neural networks, enhanced with convolutional layers, effectively predicted key operational criteria including mission makespans and intra-team communication metrics.
In addition to baseline performance prediction, the authors highlighted the efficacy of transfer learning for training predictive models across different algorithmic regimes. The researchers demonstrated that models initially trained on outputs from a simpler, sub-optimal solver could be successfully fine-tuned to predict solutions generated by a more complex, optimal solver. This transfer learning strategy achieved improved predictive accuracy while substantially reducing both the required training dataset size and the accompanying computational burden during model development.
Subject of Research: Deep learning inference of team performance in heterogeneous multi-robot systems
Article Title: Deep Learning-Based Fast Inference of Team Performance in Heterogeneous Multi-Robot Systems
Article References: Ansari, M. Y., Feo Flushing, E., Ishaq, M., Yaqoob, M., & Di Caro, G. A. (2026). Deep Learning-Based Fast Inference of Team Performance in Heterogeneous Multi-Robot Systems. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02477-8
Image Credits: AI Generated
DOI: 10.1007/s10846-026-02477-8
Keywords: multi-robot systems, heterogeneous robots, deep learning, fast inference, team performance prediction, multi-robot task allocation, supervised learning, recurrent neural networks, long short-term memory, convolutional layers, transfer learning, makespan prediction, intra-team communication, team composition, spatially distributed missions, algorithmic solvers
News Source: Denise Maddox. (November 18, 2026). Neural Networks Accurately Predict Team Performance in Heterogeneous Multi-Robot Systems. Scienmag.