• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Wednesday, November 18, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Lightweight AI Models Enable Reliable Slip Detection on Microcontroller Hardware

by
November 18, 2026
in Technology
Reading Time: 2 mins read
0
Lightweight AI Models Enable Reliable Slip Detection on Microcontroller Hardware

Lightweight AI Models Enable Reliable Slip Detection on Microcontroller Hardware

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

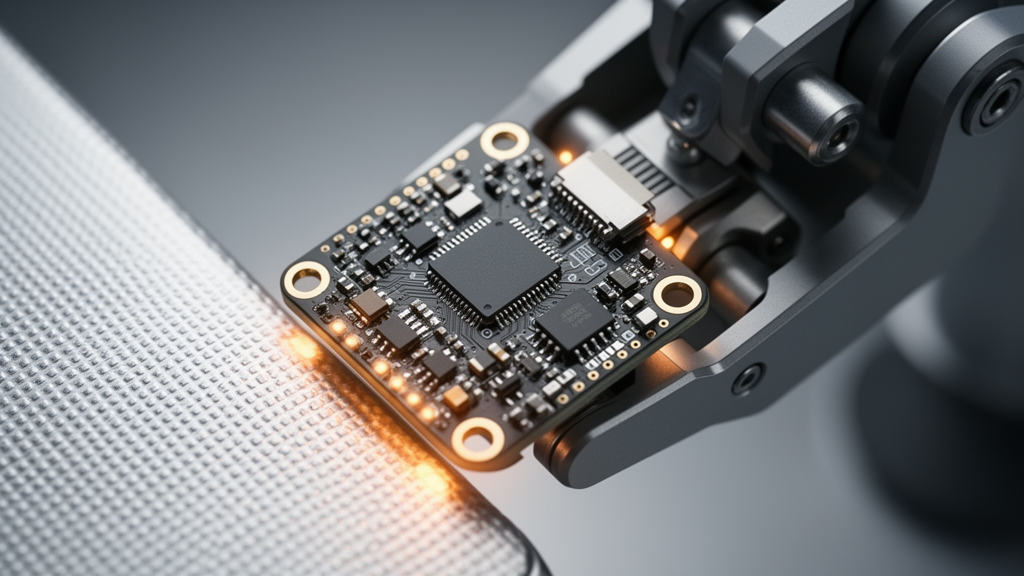
Researchers have demonstrated that accurate slip detection for robotic grasping is feasible on highly constrained embedded hardware, bridging a critical gap in real-world robotic manipulation. By designing and evaluating lightweight Long Short-Term Memory (LSTM) and Temporal Convolutional Network (TCN) architectures, the team provides a rigorous benchmark for performance across various edge computing platforms.

Reliable object grasping remains essential for autonomous systems in sectors like manufacturing and assembly. While previous studies have shown that LSTM networks can perform real-time slip detection on edge devices, those experiments were often limited by manually labeled datasets and a lack of comprehensive comparisons between different model and hardware configurations. This study addresses these limitations by introducing a large-scale slip detection dataset gathered through automated means.

To generate high-quality training data, the researchers utilized a Fin Ray-inspired soft gripper equipped with tactile Force Sensing Linear Potentiometers, a Time-of-Flight sensor, and an encoder. By leveraging automatically estimated ArUco marker poses, the team successfully created precise slip and no-slip labels for their sensor sequences. This methodological shift allows for a more robust evaluation of how different machine learning architectures process tactile data during grasping tasks.

The study focuses on the comparative performance of lightweight LSTM and TCN architectures. After training these models on the collected sensor data, the researchers tested them on a held-out set to ensure generalization. The selected architectures were then deployed across diverse embedded platforms, ranging from high-performance systems like the Nvidia Jetson AGX Orin to power-efficient, microcontroller-class devices including the Google Coral Dev Board Micro, ESP32, and Arduino Nicla Sense ME.

The researchers conducted an extensive performance evaluation, measuring accuracy, F1 scores, average inference time, and estimated average energy consumption per inference for each platform. The results confirm that accurate slip detection is achievable even on significantly constrained microcontrollers, proving that complex tactile analysis does not necessarily require high-end computational power.

This benchmark provides a clear comparison of model-hardware combinations, which has been lacking in earlier literature. By assessing energy efficiency alongside predictive performance, the study offers practical guidance for deploying adaptive robotic systems in environments where power and compute resources are strictly limited. The findings suggest that real-time, resource-aware slip detection is a viable path toward safer and more robust robotic manipulation.

Subject of Research: Edge AI-based robotic slip detection evaluation

Article Title: Slip Detection for Robotic Grasping with LSTM and TCN: Edge AI Evaluation on Embedded Platforms

Article References: Khan, M. H., Radke, M., Hanna, M., Saeed, R., Fan, M., Liu, H., & Rätsch, M. (2026). Slip Detection for Robotic Grasping with LSTM and TCN: Edge AI Evaluation on Embedded Platforms. Journal of Intelligent & Robotic Systems, 112(4), Article 109. https://doi.org/10.1007/s10846-026-02481-y

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02481-y

Keywords: Robotics, Edge AI, LSTM, TCN, Slip Detection, Microcontrollers, Embedded Systems, Tactile Sensing, Soft Robotics, Object Manipulation, Real-time Sensing, Nvidia Jetson, Google Coral, ESP32, Arduino Nicla, Fin Ray Gripper, Force Sensing Linear Potentiometers

News Source: Denise Maddox. (November 18, 2026). Lightweight AI Models Enable Reliable Slip Detection on Microcontroller Hardware. Scienmag.
Tags: Arduino Niclaedge AIembedded systemsESP32Fin Ray GripperForce Sensing Linear PotentiometersGoogle CoralLSTMmicrocontrollersNVIDIA JetsonObject Manipulationreal-time sensingRoboticsSlip Detectionsoft roboticstactile sensingTCN
Share12Tweet7Share2ShareShareShare1

Related Posts

New Biomicrometric Framework Tracks Spatial and Temporal Dynamics in Migrating Cells

New Biomicrometric Framework Tracks Spatial and Temporal Dynamics in Migrating Cells

November 18, 2026
Microstructural Modeling Optimizes Electrical Resistance in Laser-Welded Aluminum Battery Interconnects

Microstructural Modeling Optimizes Electrical Resistance in Laser-Welded Aluminum Battery Interconnects

November 18, 2026

Bio-Based Benzoxazine Blended With Polyethylene Glycol Enables Self-Healing Marine Coatings

November 18, 2026

Distributed Latent Encoding Cuts Cloud Media Retrieval Latency Across Six Datasets

November 18, 2026

POPULAR NEWS

  • Review Identifies Stage-Specific Biological Bottlenecks Limiting Long-Term Cancer Metastasis Control

    Review Identifies Stage-Specific Biological Bottlenecks Limiting Long-Term Cancer Metastasis Control

    29 shares
    Share 12 Tweet 7
  • Lightweight AI Models Enable Reliable Slip Detection on Microcontroller Hardware

    29 shares
    Share 12 Tweet 7
  • Overharvesting Threatens Traditional Cosmetic Plants in South Africa’s Eastern Cape

    29 shares
    Share 12 Tweet 7
  • Distributed Latent Encoding Cuts Cloud Media Retrieval Latency Across Six Datasets

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Preoperative Strain Predicts Hypertrophy Burden but Not Reverse Remodeling After Valve Replacement

HemoCue Hb801 Accurately Measures Hemoglobin While SpHb Tracks Trends

Northern Iran Uropathogenic E. coli Show High Antibiotic Resistance and Integron Carriage

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 88 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.