• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Thursday, November 19, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

IsoRank Framework Detects Sybil Identities in Multi-Robot Exploration Using Spatial Consistency

by
November 19, 2026
in Technology
Reading Time: 2 mins read
0
IsoRank Framework Detects Sybil Identities in Multi-Robot Exploration Using Spatial Consistency

IsoRank Framework Detects Sybil Identities in Multi-Robot Exploration Using Spatial Consistency

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

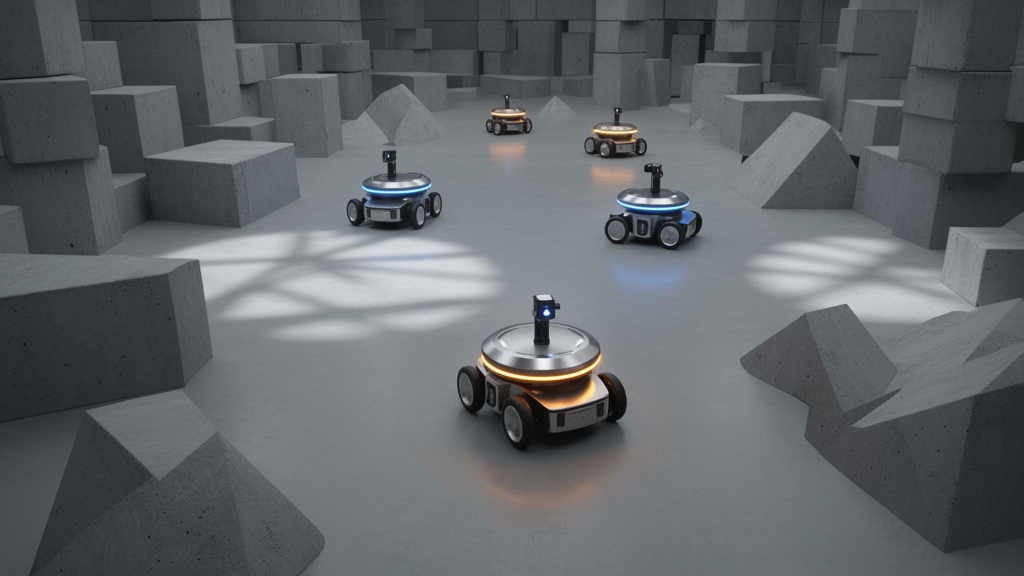
A geometry-driven detection framework named IsoRank successfully identifies forged Sybil identities in distributed multi-robot exploration teams by evaluating spatial consistency constraints. In a study published in the Journal of Intelligent & Robotic Systems, researchers Rubal Sagwal, Vishal Gupta, and Avinash Gautam investigated the impact of strategically placed Sybil identities on distributed exploration, demonstrating that spatial consistency provides an effective lightweight signal for detecting anomalous geometric behavior without relying on centralized coordination.

Cooperative multi-robot exploration relies on mutual coordination among autonomous agents, but Sybil attacks pose a significant threat to these distributed systems. In a Sybil attack, an adversary introduces forged identities to manipulate shared coverage information and disrupt distributed coordination. To examine these vulnerabilities, the researchers evaluated the impact of strategically placed Sybil identities during exploration missions, adopting adversarial placement strategies established in prior work to model realistic adversarial behavior.

Building on this threat model, the research team developed IsoRank to exploit spatial consistency constraints inherent to physically realizable robot teams. The framework operates through a multi-stage design that integrates density-based clustering, global centroid-isolation analysis, and local neighbor-consistency verification. By combining these geometric checks, IsoRank identifies identities that exhibit anomalous geometric behavior across the operational environment, distinguishing legitimate team members from fabricated nodes.

A primary operational advantage of the IsoRank method is that it operates using only broadcast position information shared among the robots. The framework requires neither centralized infrastructure nor specialized hardware, allowing it to function directly within distributed multi-robot teams. By avoiding specialized hardware requirements or central coordination hubs, the approach maintains the flexibility and scalability required for autonomous distributed robotic exploration across unknown domains.

The authors evaluated IsoRank under distributed multi-robot exploration across varying robot densities and different environment configurations. Experimental results, including ablation and parameter-sensitivity analyses, showed that the combined multi-stage design consistently improves detection performance over the individual geometric stages across varying robot densities and environment configurations. The researchers concluded that spatial consistency offers a practical and lightweight signal for detecting Sybil identities in distributed multi-robot exploration.

Subject of Research: Geometric detection of Sybil identities in distributed multi-robot exploration

Article Title: Detecting Sybil Identities in Distributed Multi-Robot Exploration via Geometric Ranking

Article References: Sagwal, R., Gupta, V., & Gautam, A. (2026). Detecting Sybil Identities in Distributed Multi-Robot Exploration via Geometric Ranking. Journal of Intelligent & Robotic Systems, 112(4), Article 94. https://doi.org/10.1007/s10846-026-02452-3

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02452-3

Keywords: IsoRank, multi-robot exploration, Sybil attacks, Sybil identity detection, distributed coordination, spatial consistency, geometric ranking, density-based clustering, centroid-isolation analysis, neighbor-consistency verification, broadcast position information, adversarial placement strategies, robot densities, environment configurations, ablation analysis, parameter-sensitivity analysis, Journal of Intelligent and Robotic Systems

News Source: Denise Maddox. (November 19, 2026). IsoRank Framework Detects Sybil Identities in Multi-Robot Exploration Using Spatial Consistency. Scienmag.
Tags: Ablation Analysisadversarial placement strategiesbroadcast position informationcentroid-isolation analysisdensity-based clusteringdistributed coordinationenvironment configurationsgeometric rankingIsoRankJournal of Intelligent and Robotic Systemsmulti-robot explorationneighbor-consistency verificationparameter-sensitivity analysisrobot densitiesspatial consistencySybil attacksSybil identity detection
Share12Tweet7Share2ShareShareShare1

Related Posts

Graphical Fuzzy B-Metric Spaces Yield Novel Fixed Point Findings and Applications

Graphical Fuzzy B-Metric Spaces Yield Novel Fixed Point Findings and Applications

November 19, 2026
Fine Earth and Fly Ash Replace Cement in Printable Construction Mortars

Fine Earth and Fly Ash Replace Cement in Printable Construction Mortars

November 19, 2026

Systematic Review Evaluates Deep Learning Generative Models in Medical Imaging

November 19, 2026

Dual Decomposition Model Accurately Predicts Dynamic Thermal Ratings of Transmission Lines

November 19, 2026

POPULAR NEWS

  • Lifelong Social Isolation Tied to Muscle Weakness but Lower Obesity Odds

    Lifelong Social Isolation Tied to Muscle Weakness but Lower Obesity Odds

    29 shares
    Share 12 Tweet 7
  • Narrative Review Identifies Systematic Bias and Privacy Risks Across AI Electrocardiography Protocols

    29 shares
    Share 12 Tweet 7
  • Landscape Integrated Farming Framework Links Cross-Farm Resources to Enhance Climate Resilience

    29 shares
    Share 12 Tweet 7
  • Machine Learning Matches Traditional Time Series in Forecasting Tanzanian Sisal Exports

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Anlotinib Combined with Cranial Radiotherapy Shows Promise for Lung Cancer Brain Metastases

Curcumin Reduces Liver Steatosis in Rats by Altering Gut Microbiota and Epigenetics

Air Sampling in Bat Caves Captures Mammalian Viruses Across Optimized Volumes

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 89 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.