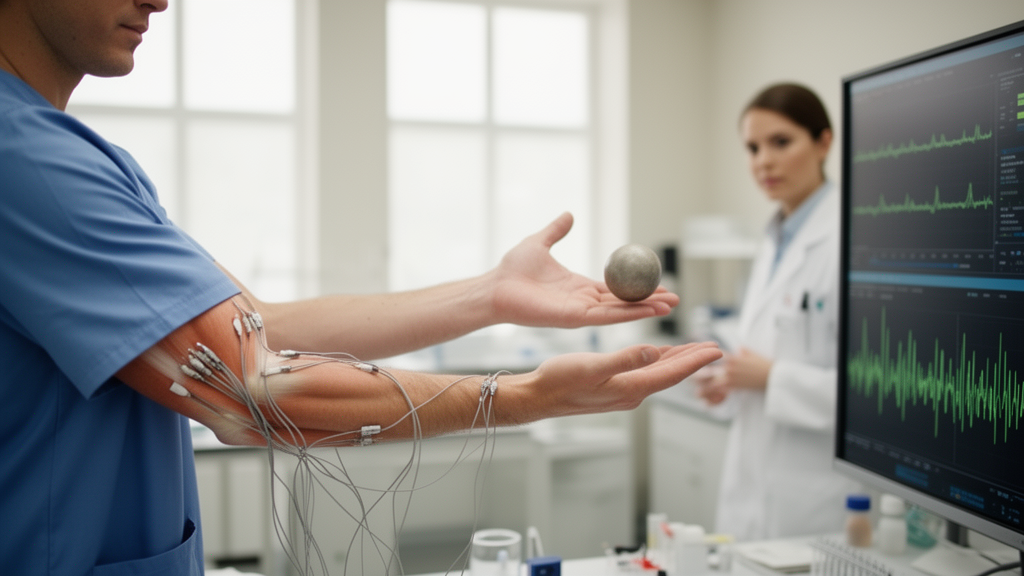
Researchers have mapped how the human arm stiffens and softens while bouncing a ball, using surface electromyography to estimate limb stiffness continuously during a task that involves intermittent contact with the environment. The study, published in Annals of Biomedical Engineering, modeled the arm as a second-order spring-mass-damper system and drew on data from thirty-four participants.
Estimating impedance—the resistance a limb presents to being displaced—is considered a key aspect of understanding human dynamic control. In this work, surface EMG signals captured ongoing muscle activity, which the team converted into stiffness estimates through Hill-type muscle models. After a training phase, participants completed two bouncing experiments, one with haptic feedback and one without, allowing the researchers to examine how this additional sensory channel affected control.
The analysis identified two distinct dynamic control strategies among the participants. The first produced a symmetrical force and position profile, in which the arm’s downward and upward motions mirrored each other. The second was asymmetrical, featuring a shorter upward phase of the arm’s motion. Crucially, the stiffness profiles tracked these force and position profiles closely, suggesting that the way people organize the bouncing movement directly shapes the impedance their arm presents during contact.
Stiffness was higher in the asymmetrical strategy, which the authors attribute to more active control of the motion. Despite these differences, both strategies kept the arm within the limits of the passive stability domain, meaning neither approach pushed the limb into a dynamically unstable configuration during the intermittent impacts.
Performance differed between the strategies as well. The symmetrical profile performed better on the bouncing task. However, the haptic feedback manipulation revealed a shared vulnerability: both profiles showed an increase in variability when haptic feedback was added, indicating that this extra sensory input did not stabilize performance and instead made the movements less consistent across trials.
Because stiffness was estimated continuously from EMG rather than measured only at discrete perturbation points, the approach captures how impedance changes across the phases of the bounce, from descent through impact to recovery.
For researchers interested in human motor control, the study offers evidence that stiffness regulation is strategy-dependent and tied to the temporal structure of the movement itself. The reported results are limited to the ball-bouncing task and the thirty-four participants studied, and the abstract does not report effects beyond these conditions.
Subject of Research: Estimating upper limb stiffness from EMG during a ball-bouncing task
Article Title: Endpoint Upper Limb Stiffness Computation and Characterization in a Ball Bouncing Task Using EMGs
Article References: Hureaux, B., Makarov, M., Rodriguez-Ayerbe, P., & Siegler, I. A. (2026). Endpoint Upper Limb Stiffness Computation and Characterization in a Ball Bouncing Task Using EMGs. Annals of Biomedical Engineering. https://doi.org/10.1007/s10439-026-04430-0
Image Credits: AI Generated
DOI: 10.1007/s10439-026-04430-0
Keywords: arm stiffness, electromyography, ball bouncing, motor control, impedance, Hill-type muscle models, haptic feedback, biomechanics, human dynamics, stability, Endpoint, Upper
News Source: Gregory Coleman. (October 29, 2026). Arm Stiffness During Ball Bouncing Revealed by EMG Signals. Scienmag.