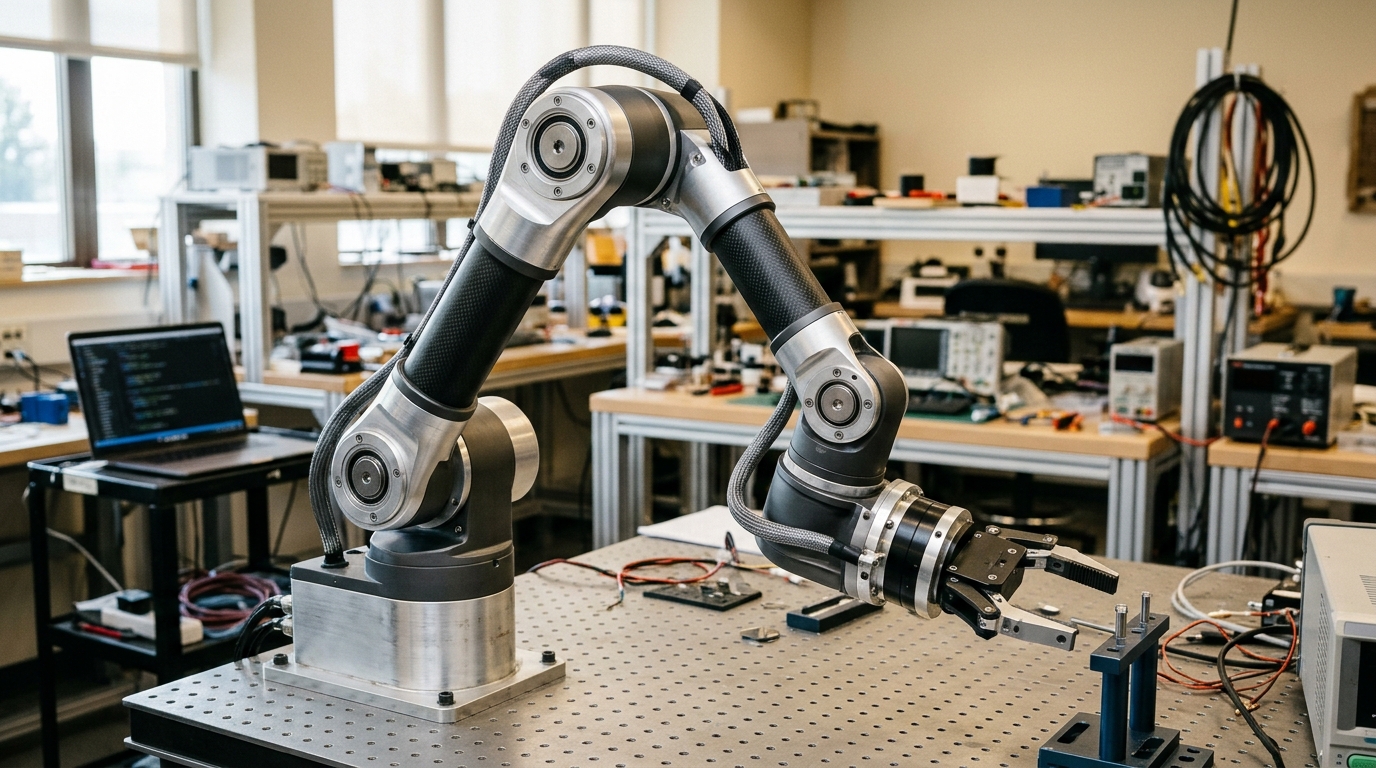
A Jacobian-free inverse kinematics solver using norm-limited cyclic perturbations can resolve joint configurations for seven-degree-of-freedom redundant manipulators while strictly observing physical limits. Formulated by researchers Qisheng Zhang and Zehong Lu, the mathematical framework targets the non-unique nature of redundant robotic positioning by minimizing a composite objective function that balances operational task residuals against a quadratic joint-motion cost.
In redundant robotic arms, controlling multiple degrees of freedom introduces non-unique configurations that demand careful handling of practical constraints such as physical joint limits. To address these operational challenges, the investigated task specifies the target entirely through end-effector Cartesian positions and approach directions. Physical joint constraints are subsequently integrated and directly enforced throughout execution using an explicit box projection mechanism.
The underlying norm-limited cyclic perturbation technique works by perturbing a single manipulator joint at a time in a cyclic sequence rather than altering all joints concurrently. According to reported ablation trials, this single-joint cyclic approach is associated with reduced residual oscillations compared to simultaneous multi-joint adjustments. The algorithm estimates a coordinate-wise descent direction requiring only two objective evaluations per iteration before applying a norm-limited update step.
Numerical simulations evaluating point tracking and continuous path tracking demonstrated stable convergence alongside low numerical residuals under an ideal Denavit–Hartenberg kinematic model. Comparative benchmarking under a position-only evaluation protocol against Artificial Bee Colony and Growing Neural Gas algorithms showed that the proposed solver achieved smaller Cartesian position residuals across the tested simulation scenarios.
Published as a regular research paper in the International Journal of Intelligent Robotics and Applications, the study focuses on resolving kinematic redundancy where multiple joint configurations can satisfy identical spatial goals.
Subject of Research: Jacobian-free inverse kinematics for 7-DOF redundant robotic manipulators
Article Title: Jacobian-free inverse kinematics for 7-DOF manipulators via norm-limited cyclic perturbation
Article References: Zhang, Q., & Lu, Z. (2026). Jacobian-free inverse kinematics for 7-DOF manipulators via norm-limited cyclic perturbation. International Journal of Intelligent Robotics and Applications. https://doi.org/10.1007/s41315-026-00616-w
Image Credits: AI Generated
DOI: 10.1007/s41315-026-00616-w
Keywords: inverse kinematics, redundant manipulators, 7-DOF manipulators, Jacobian-free solver, norm-limited cyclic perturbation, robotic kinematics, joint limits, Denavit-Hartenberg model, point tracking, continuous path tracking, Artificial Bee Colony, Growing Neural Gas, box projection, coordinate descent, Cartesian position residuals, joint motion cost
News Source: Denise Maddox. (November 19, 2026). Cyclic Perturbation Solver Resolves Redundant Robotic Inverse Kinematics Without Jacobian Matrices. Scienmag.