• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Wednesday, November 18, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Optimized Dual-Loop Control Framework Improves Robust Quadrotor Position Tracking

by
November 18, 2026
in Technology
Reading Time: 2 mins read
0
Optimized Dual-Loop Control Framework Improves Robust Quadrotor Position Tracking

Optimized Dual-Loop Control Framework Improves Robust Quadrotor Position Tracking

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

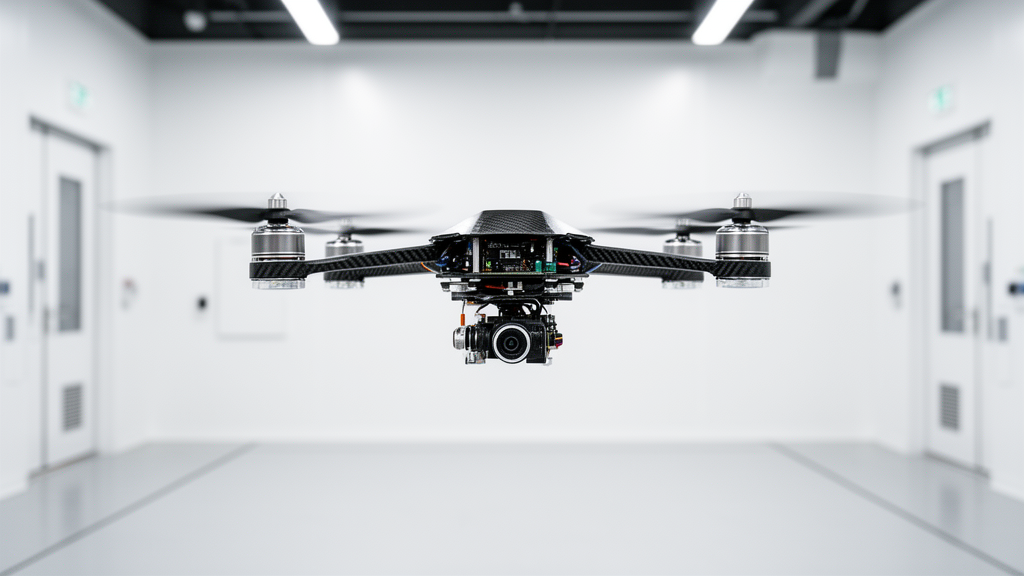
A newly developed dual-loop control architecture offers robust three-dimensional position tracking for quadrotors operating under environmental disturbances and model uncertainties. Published in the Journal of Intelligent & Robotic Systems, the engineering study introduces a hybrid framework combining an inner adaptive fuzzy feedback linearization controller with an outer sliding mode controller. The integrated control methodology is optimized using late acceptance hill climbing to maintain high-precision position and path tracking during dynamic aerial operations.

The research focuses on the complex technical problem of maintaining reliable quadrotor position control under demanding physical and aerodynamic constraints. Quadrotor flight dynamics involve strong nonlinear couplings across system states, physical actuator constraints, and inherent modeling errors.

To address these interrelated control challenges, the authors proposed a dual-loop architecture that divides stabilization and trajectory duties between two cooperative stages. The inner loop relies on a Fuzzy Adaptive Feedback Linearization Controller, designated as AFFLC, which is specifically tasked with cancelling structural nonlinearities and estimating system uncertainties online. Meanwhile, the outer loop utilizes a Sliding Mode Controller, or SMC, to enforce precise path following and robust position tracking across the desired flight trajectory.

To refine tracking performance, the framework incorporates a specialized asymmetric fuzzy adaptation mapping. This adaptive mechanism is formulated so that the adaptive gain scales nonlinearly with the magnitude of the tracking error while remaining small when the system is near the origin.

The dual-loop system incorporates Late Acceptance Hill Climbing, or LAHC, optimization to adjust the control parameters. Applying the LAHC optimization algorithm enhances the convergence speed of the tracking response, reduces unwanted oscillations within the generated control signals, and significantly improves system adaptability under varying payloads and changing dynamic operating conditions. Furthermore, the researchers verified the theoretical stability of the entire hybrid closed-loop structure using Lyapunov stability analysis.

Overall evaluation results indicate that the hybrid framework achieves more accurate three-dimensional trajectory tracking and demonstrates greater robustness against both external disturbances and internal uncertainties. Compared with computationally intensive deep learning approaches or heavy meta-heuristic optimization techniques, the proposed architecture generates smoother, low-cost control signals. Consequently, the authors conclude that the system provides a practical and implementable control solution for real-world quadrotor platforms.

Subject of Research: Robust quadrotor position control using dual-loop adaptive hybrid architectures

Article Title: Robust Quadrotor Position Tracking Using an LAHC-Optimized Dual-Loop Adaptive Fuzzy Feedback Linearization and Sliding Mode Control Framework

Article References: Spanogianopoulos, S., & Jalalnezhad, M. (2026). Robust Quadrotor Position Tracking Using an LAHC-Optimized Dual-Loop Adaptive Fuzzy Feedback Linearization and Sliding Mode Control Framework. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02478-7

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02478-7

Keywords: quadrotors, position tracking, dual-loop control, sliding mode control, feedback linearization, fuzzy adaptive control, Late Acceptance Hill Climbing, Lyapunov stability, actuator constraints, payload variations, wind disturbances, chattering reduction, nonlinear couplings, control signal optimization, three-dimensional tracking, aerial robotics

News Source: Denise Maddox. (November 18, 2026). Optimized Dual-Loop Control Framework Improves Robust Quadrotor Position Tracking. Scienmag.
Tags: actuator constraintsaerial roboticsChattering Reductioncontrol signal optimizationdual-loop controlfeedback linearizationfuzzy adaptive controlLate Acceptance Hill ClimbingLyapunov stabilitynonlinear couplingspayload variationsposition trackingquadrotorssliding-mode controlthree-dimensional trackingwind disturbances
Share12Tweet7Share2ShareShareShare1

Related Posts

Deep Learning Models Forecast Gravity Caisson Tilting From Early Construction Data

Deep Learning Models Forecast Gravity Caisson Tilting From Early Construction Data

November 18, 2026
Mucin-Responsive Nanomedicine Improves Tumour Penetration and Delivery in Mice

Mucin-Responsive Nanomedicine Improves Tumour Penetration and Delivery in Mice

November 18, 2026

Special Issue Highlights Advances in Superfunctional High-Entropy Alloys and Ceramics

November 18, 2026

Circular Timber Office Cuts Lifecycle Carbon Emissions by Nearly Half in Belgium

November 18, 2026

POPULAR NEWS

  • Early Sensory Differences Prospectively Predict Subsequent Autistic Traits in Longitudinal Cohort

    Early Sensory Differences Prospectively Predict Subsequent Autistic Traits in Longitudinal Cohort

    29 shares
    Share 12 Tweet 7
  • High-Power Spray Coagulation Boosts Efficiency in Colorectal Underwater Endoscopic Dissection

    29 shares
    Share 12 Tweet 7
  • Robotic Latissimus Dorsi Harvest Minimizes Incisions in Complex Breast Reconstruction

    29 shares
    Share 12 Tweet 7
  • Integrated Decision Framework Cuts Costs and Speeds Supply Network Recovery

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Review Outlines How Abemaciclib Prolongs Survival in Common Breast Cancers

Adult Influenza Brain Complications Show Substantial Clinical Overlap Across Diagnostic Categories

Quadrupled Hamstring Constructs Outperform Tape-Augmented Quadriceps Tendons in Cadaveric Knee Reconstructions

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 88 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.