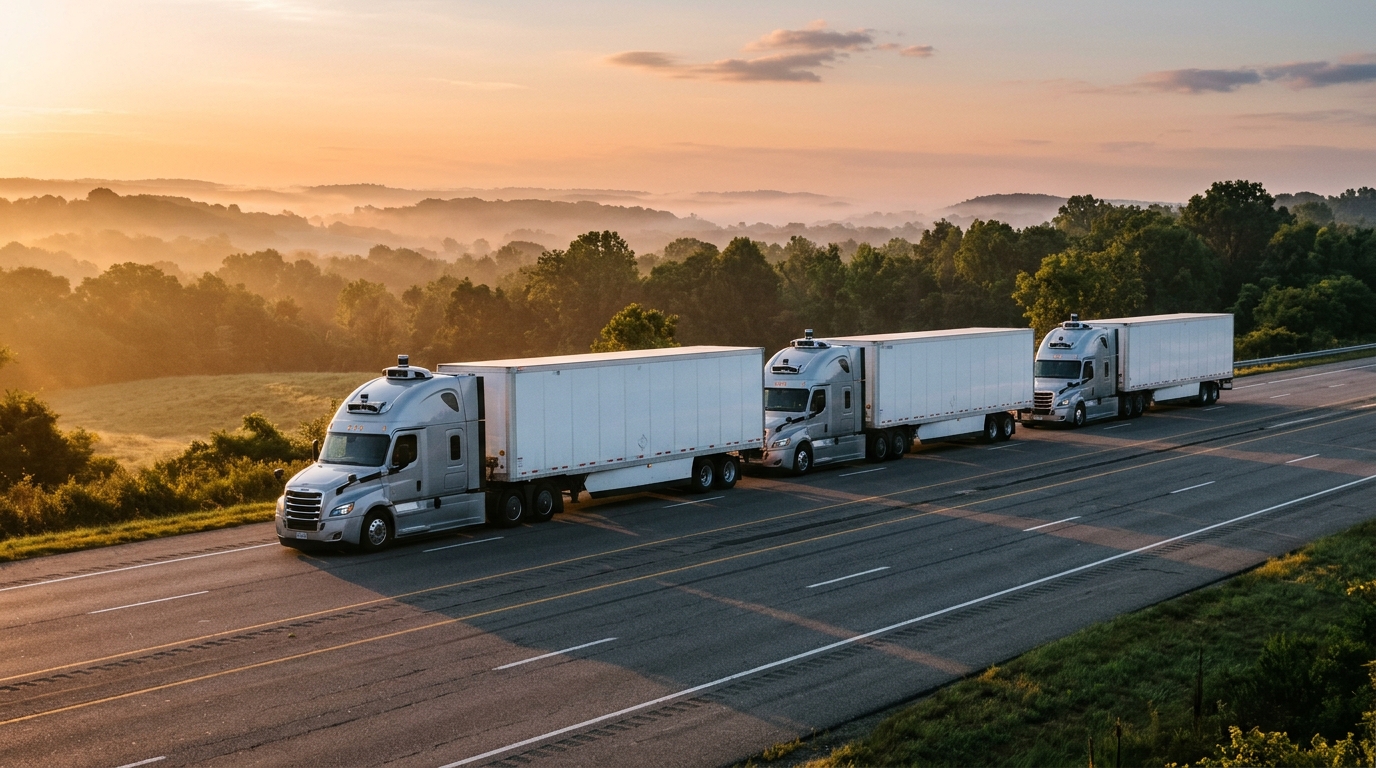
A research team from Southeast University and Monash University has developed a physics-informed platooning control framework that integrates traditional vehicle control methods with learning-based optimization techniques to improve the stability and tracking accuracy of autonomous vehicle platooning under real-world conditions. Published in the peer-reviewed journal Communications in Transportation Research, the study addresses operational difficulties in cooperative vehicle platooning—where multiple vehicles travel with short inter-vehicle distances to improve energy efficiency, reduce aerodynamic resistance, and enhance road capacity—amid real-world sensor uncertainties, imperfect vehicle dynamics models, and nonlinear actuator responses.
To establish reliable state estimation for subsequent control decisions, the researchers introduced a multi-source state fusion method that integrates measurements from wheel odometry, an inertial measurement unit, and a global positioning system. By combining continuous onboard motion information with global position corrections, the proposed fusion framework mitigates measurement uncertainties and provides dependable vehicle state estimation, which serves as the foundational input for the system’s control architecture.
Based on these estimated vehicle states, the researchers developed a model-based controller combining Model Predictive Control and Lateral Feedforward-Feedback Control. The controller deliberately separates longitudinal and lateral control tasks, allowing efficient computational optimization of vehicle speed and trajectory tracking while maintaining real-time performance.
To improve adaptability under changing driving conditions, the research team introduced a data-driven improvement module into the control pipeline. Within this module, an offline Conservative Q-Learning algorithm automatically calibrates key controller parameters from historical driving data. Simultaneously, a neural residual learning model compensates for discrepancies between theoretical control commands and actual vehicle responses caused by actuator delays and unmodeled vehicle dynamics.
The proposed framework was evaluated through both simulation experiments and real-world vehicle tests using a Robot Operating System-based two-vehicle platform equipped with multiple sensors. Experimental results demonstrated that the method improved vehicle platooning stability and tracking accuracy under realistic operating conditions. The learning-based compensation module effectively reduced control errors caused by hardware uncertainties, showing the potential of combining physical models with artificial intelligence for autonomous driving applications. The researchers noted that their work provides a practical approach to integrating physics-based control and data-driven learning for real-world autonomous vehicle systems while maintaining interpretability and safety.
The authors noted that the study provides fresh insights into the development of robust autonomous vehicle platooning systems, while outlining several avenues for future research. Although initial real-world evaluation confirmed improved stability and tracking accuracy on a two-vehicle test platform, upcoming studies may further investigate multi-vehicle platooning involving heterogeneous vehicle dynamics across different vehicle types, communication delays between vehicles, and more complex roadway environments to improve the scalability and reliability of cooperative autonomous driving technologies.
The research paper, titled “Physics-informed platooning with learning-augmented calibration and compensation: a real-world study,” was published on September 30, 2026. The study appeared in Communications in Transportation Research, an academic journal launched in 2021 with support provided by Tsinghua University and the China Intelligent Transportation Systems Association. Led by Editors-in-Chief Professor Xiaobo Qu of Tsinghua University, a member of the Academia Europaea, and Professor Xiaopeng (Shaw) Li from the University of Wisconsin–Madison, the peer-reviewed journal publishes original research and review articles focused on emerging transportation systems. It aims to serve as an international platform for showcasing innovative achievements in transportation and related fields, fostering academic exchange between China and the global community.
Communications in Transportation Research is indexed in major databases including SCIE, SSCI, Ei Compendex, Scopus, CSTPCD, CSCD, OAJ, DOAJ, and TRID. The journal was selected as a Q1 Top Journal in the Engineering and Technology category of the Chinese Academy of Sciences Journal Ranking List. In 2022, it was selected as a High-Starting-Point new journal project of the China Science and Technology Journal Excellence Action Plan. In 2024, it was selected for the Support the Development Project of High-Level International Scientific and Technological Journals and chosen as an English Journal Tier Project under Phase II of the China Science and Technology Journal Excellence Action Plan.
The publication has also attained leading citation rankings within the transportation domain. In 2024, it received an initial 2023 impact factor of 12.5, ranking first among 58 journals in the transportation category. In 2026, its 2025 impact factor was announced as 12.7, maintaining its top-ranked position among 66 journals in the category. Beginning with Volume 6 in 2026, Communications in Transportation Research is published by Tsinghua University Press on the SciOpen platform, with manuscript submissions handled through its online submission system.
Subject of Research: Physics-informed control framework for autonomous vehicle platooning
Article Title: Can physics and artificial intelligence make autonomous vehicle platooning more reliable?
Article References: Can physics and artificial intelligence make autonomous vehicle platooning more reliable?. Original publication (Bibliographic details unavailable.)
Image Credits: AI Generated
DOI: Not provided
Keywords: autonomous vehicles, vehicle platooning, physics-informed learning, model predictive control, sensor fusion, conservative Q-learning, cooperative driving, intelligent transportation, physics, artificial, intelligence, make
News Source: Katie Riggs. (November 7, 2026). Physics-Informed Learning Framework Improves Autonomous Vehicle Platooning Stability and Reliability. Scienmag.