

• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Saturday, October 31, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

by
October 28, 2026
in Technology
Reading Time: 2 mins read
0
Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

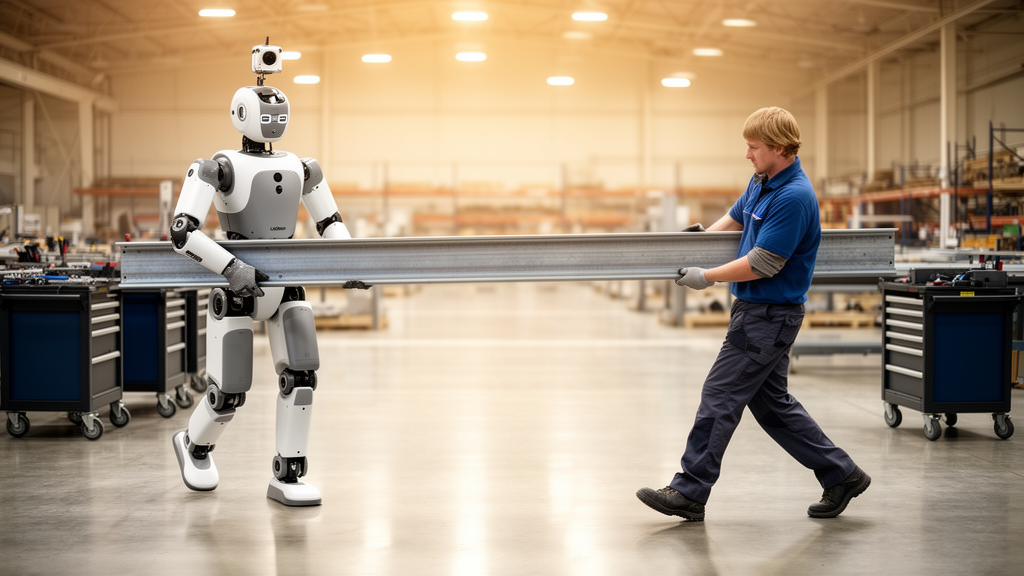
Engineers have demonstrated a control framework that lets a humanoid robot carry an object alongside a human partner, handling not only straight-line moves but also turns and curved, semi-circular paths of the kind that arise naturally when two agents share a load. The system was validated in real-world experiments on the Digit humanoid platform.

The framework rests on three components. A high-level planner generates dynamically feasible footstep plans by combining a model the researchers call the Interaction Linear Inverted Pendulum (I-LIP) with an admittance model and a model predictive control formulation. At the lowest level, a quadratic-programming-based whole-body controller executes those plans while accounting for the coupled dynamics of the humanoid and the object being carried together.

Between the two sits a stiffness modulation mechanism, which regulates the interaction between the robot and the object. Its role is to ensure convergence to a desired relative configuration, defined by the distance between the object and the robot’s center of mass.

To measure how well the collaboration actually works, the team proposes an efficiency metric that captures both task performance and inter-agent coordination. According to the authors, this metric highlights the role of compliance in collaborative tasks and offers insights into desirable trajectory characteristics across both the high- and low-level control layers.

The reported behaviors include translation, turning, and combined motions such as semi-circular trajectories, demonstrating versatility beyond simple point-to-point carrying. Because the planner explicitly supports both translational and rotational motion, the framework targets the full range of movements fundamental to co-transport scenarios rather than a single scripted task.

The I-LIP planner and the coupled-dynamics whole-body controller are designed to handle exactly that coupling between balance and shared load.

Subject of Research: A control framework enabling humanoid robots to collaboratively transport objects with human partners, validated on the Digit platform.

Article Title: Efficient and compliant control framework for versatile human-humanoid collaborative transportation

Article References: Kumbhar, S. S., Kulkarni, A. M., & Artemiadis, P. (2026). Efficient and compliant control framework for versatile human-humanoid collaborative transportation. Autonomous Robots, 50(4), Article 45. https://doi.org/10.1007/s10514-026-10271-6

Image Credits: AI Generated

DOI: 10.1007/s10514-026-10271-6

Keywords: humanoid robots, collaborative transportation, human-robot interaction, compliant control, I-LIP, whole-body control, stiffness modulation, Digit, model predictive control, co-transport, Efficient, compliant

News Source: Denise Maddox. (October 28, 2026). Research report: Efficient and compliant control framework for versatile human-humanoid collaborative transportation. Scienmag.


Tags: co-transportcollaborative transportationcompliantcompliant controlDigitefficientHuman-Robot Interactionhumanoid robotsI-LIPmodel predictive controlstiffness modulationwhole-body control
Share12Tweet7Share2ShareShareShare1

Related Posts

Systematic review maps sustainability tensions in offshore wind development

Systematic review maps sustainability tensions in offshore wind development

October 30, 2026
Amateur maps and sketches helped put Hong Kong's wartime pillboxes on official charts

Amateur maps and sketches helped put Hong Kong’s wartime pillboxes on official charts

October 30, 2026

Heavier logging trucks only pay off when the road network lets them work

October 30, 2026

Supersulfated cement outperforms Portland cement in curbing concrete’s alkali-silica reaction

October 30, 2026

POPULAR NEWS

  • Microbial Sources and Stress Shape the Hidden Endophytes of an Invasive Plant

    Microbial Sources and Stress Shape the Hidden Endophytes of an Invasive Plant

    29 shares
    Share 12 Tweet 7
  • Firebreaks Leave Lasting Scars in Grasslands While Wildfire Heals Fast

    29 shares
    Share 12 Tweet 7
  • ZNF207 shields glutamine transporter ASCT2 from degradation to fuel liver cancer growth

    29 shares
    Share 12 Tweet 7
  • Systematic review maps sustainability tensions in offshore wind development

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Microbial Sources and Stress Shape the Hidden Endophytes of an Invasive Plant

Firebreaks Leave Lasting Scars in Grasslands While Wildfire Heals Fast

ZNF207 shields glutamine transporter ASCT2 from degradation to fuel liver cancer growth

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 86 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.
