• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Monday, October 26, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Controller Rankings Shift When Uncertainty Is Weighted Differently

by
October 26, 2026
in Technology
Reading Time: 2 mins read
0
Controller Rankings Shift When Uncertainty Is Weighted Differently

Controller Rankings Shift When Uncertainty Is Weighted Differently

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

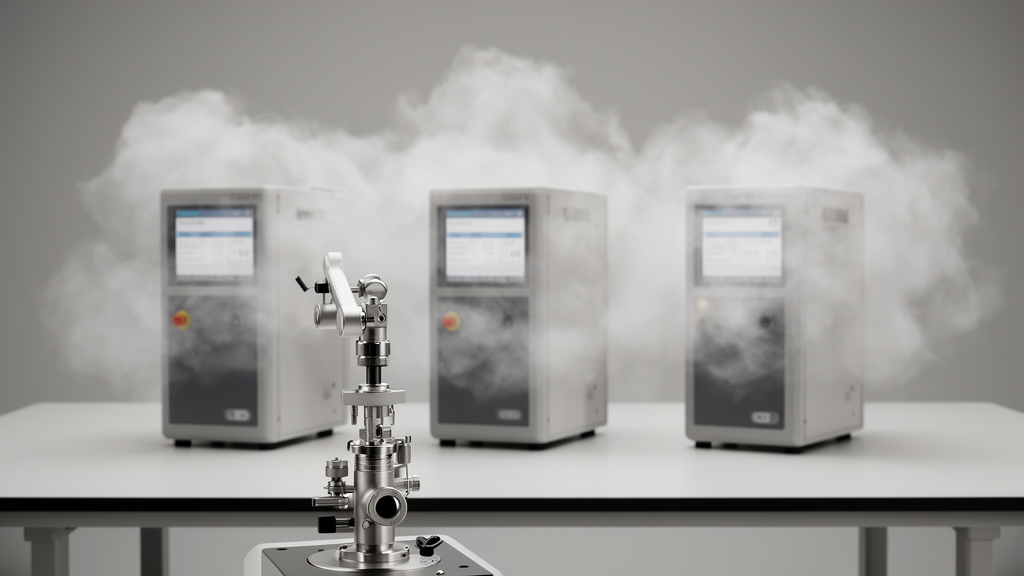
A simulation study comparing five fixed control algorithms found that statistically detectable performance differences did not always establish a unique engineering preference for a nonlinear rotary inverted pendulum. Across 30,000 closed-loop simulations, PID controllers recorded the lowest controller robustness index in every tested uncertainty band, yet the four leading indices were separated by no more than 3.87%. The results illustrate how closely matched controllers can differ significantly in a numerical score without possessing a clear, practically meaningful advantage.

The researchers evaluated the controllers on a numerically verified nonlinear rotary inverted pendulum model. They represented uncertainty using two independent Latin-hypercube realizations within matched ±10%, ±15% and ±20% bands. A four-metric score combined the controllers’ simulated performance, while a prespecified 5% practical margin defined whether one controller was separated sufficiently from another to support a unique preference. The benchmark therefore assessed not only whether controller scores differed, but also whether those differences exceeded its threshold for practical separation.

In the pooled ±15% uncertainty domain, all ten paired controller comparisons were detectable after Holm correction for multiple comparisons. The statistical result did not, however, yield a consistent practical winner: 69.40% of 2,000 scenario blocks lacked a unique practical preference under the common uncertainty score. A controller could therefore occupy a clear position in a statistical ranking while remaining effectively tied with alternative controllers under the study’s practical-separation criterion.

PID’s apparent lead was sensitive to the weighting of uncertainty in the analysis. It retained first rank in 99.95% of paired-bootstrap replicates, but its rank-one frequency fell to 63.16% and 43.06% in two weight-variation analyses. Post-review analyses showed that the principal practical-separation finding was robust to the tested controller robustness index coefficient, realization-specific median normalization and heavier-tailed dependence models. Command delay behaved differently: changing it altered separation among controllers that were otherwise near-tied. Because this was a simulation study, its findings are specific to the five-controller portfolio, chosen score definition, rotary inverted pendulum model and simulated uncertainty domain; they do not establish the controllers’ performance on physical systems or under unmodeled operating conditions.

Subject of Research: Reliability of controller preferences in a simulated rotary inverted pendulum under uncertainty

Article Title: Quantifying controller preference reliability under uncertainty in a rotary inverted pendulum benchmark

Article References: Coşkun, Y., Özyılmaz, L., & Aydın, M. (2026). Quantifying controller preference reliability under uncertainty in a rotary inverted pendulum benchmark. Scientific Reports. https://doi.org/10.1038/s41598-026-76797-y

Image Credits: AI Generated

DOI: 10.1038/s41598-026-76797-y

Keywords: rotary inverted pendulum, controller comparison, uncertainty quantification, robustness index, Latin hypercube sampling, sensitivity analysis, practical significance, control engineering, Quantifying, controller, preference, reliability

News Source: Denise Maddox. (October 26, 2026). Controller Rankings Shift When Uncertainty Is Weighted Differently. Scienmag.
Tags: control engineeringcontrollercontroller comparisonLatin hypercube samplingpractical significancepreferenceQuantifyingreliabilityrobustness indexrotary inverted pendulumSensitivity analysisuncertainty quantification
Share12Tweet7Share2ShareShareShare1

Related Posts

Career support linked to student well-being, but moderation evidence remains exploratory

Career support linked to student well-being, but moderation evidence remains exploratory

October 26, 2026
Clay Strength With Polyester Resin Depends Strongly on Initial Moisture

Clay Strength With Polyester Resin Depends Strongly on Initial Moisture

October 26, 2026

Deeper Foundation Treatment Increases Uneven Settlement in Coastal Soil Model

October 26, 2026

AI model sharpens entrepreneurial project recommendations from sparse user data

October 26, 2026

POPULAR NEWS

  • Hepatitis B vaccination gaps cluster by community in eight African countries

    Hepatitis B vaccination gaps cluster by community in eight African countries

    29 shares
    Share 12 Tweet 7
  • Controller Rankings Shift When Uncertainty Is Weighted Differently

    29 shares
    Share 12 Tweet 7
  • Career support linked to student well-being, but moderation evidence remains exploratory

    29 shares
    Share 12 Tweet 7
  • Clay Strength With Polyester Resin Depends Strongly on Initial Moisture

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Hepatitis B vaccination gaps cluster by community in eight African countries

Controller Rankings Shift When Uncertainty Is Weighted Differently

Career support linked to student well-being, but moderation evidence remains exploratory

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 85 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.