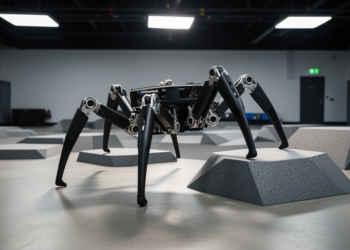
Hexapod Simulation Explores Distributed Active Inference for Robot Locomotion Without Central Control
A computational study demonstrates how decentralized predictive controllers coordinate legged locomotion through local active inference and mechanical coupling without a ...