Bearing Control Coordinates Unicycle Robots Despite Unknown Leader Velocities
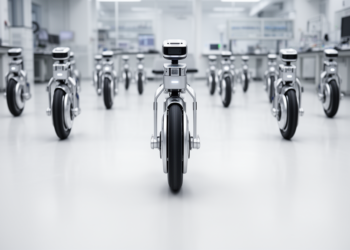
A bearing-based control framework enables unicycle follower robots to achieve and maintain target formations without measuring leader or neighbor velocities.
A bearing-based control framework enables unicycle follower robots to achieve and maintain target formations without measuring leader or neighbor velocities.