Discrete-Time Geometric Backstepping Improves Aggressive Quadrotor Trajectory Tracking
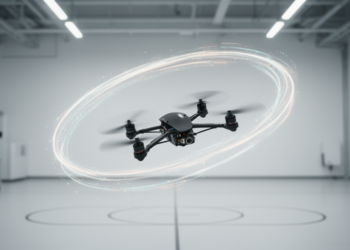
A discrete-time geometric backstepping framework on SO(3) resolves sampling inconsistencies to stabilize aggressive quadrotor trajectory tracking.
A discrete-time geometric backstepping framework on SO(3) resolves sampling inconsistencies to stabilize aggressive quadrotor trajectory tracking.