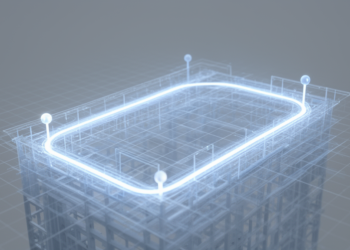
Reconstruction Framework Improves Path Length and Optimality in Grid Navigation
Researchers introduced SBCR-A*, an algorithm pipeline that reconstructs grid-based paths into straight feasible segments to improve geometric optimality.
Researchers introduced SBCR-A*, an algorithm pipeline that reconstructs grid-based paths into straight feasible segments to improve geometric optimality.
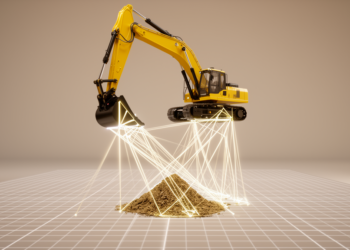
Physics-based excavator simulations show that planar path planning drastically cuts computation time while maintaining compact trajectories and kinematic stability.
Researchers developed AFI-RRT*, an adaptive path planning framework that significantly reduces execution time and search-tree size while producing shorter paths ...
Engineers have developed an improved A* path planning algorithm that guides autonomous orchard robots safely between irrigation ditches and low-hanging ...
A MATLAB simulation combining Theta* planning, potential field avoidance, Pure Pursuit tracking and LIDAR mapping reached the goal in nine ...
A new study combines an improved graph capsule neural network with a user-aware A* path planning algorithm to create an ...
Researchers have developed a coordinated optimization framework that uses mutation-enhanced particle swarm optimization to arrange 53 satellite components under attitude-control ...
Researchers have developed an adaptive logistic regression model that lets low-cost autonomous robots classify obstacles and steer through dense environments ...