• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Tuesday, November 17, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Shark Algorithm and Dynamic Modeling Optimize Four-Finger Cable Sorting Robot

by
November 17, 2026
in Technology
Reading Time: 2 mins read
0
Shark Algorithm and Dynamic Modeling Optimize Four-Finger Cable Sorting Robot

Shark Algorithm and Dynamic Modeling Optimize Four-Finger Cable Sorting Robot

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

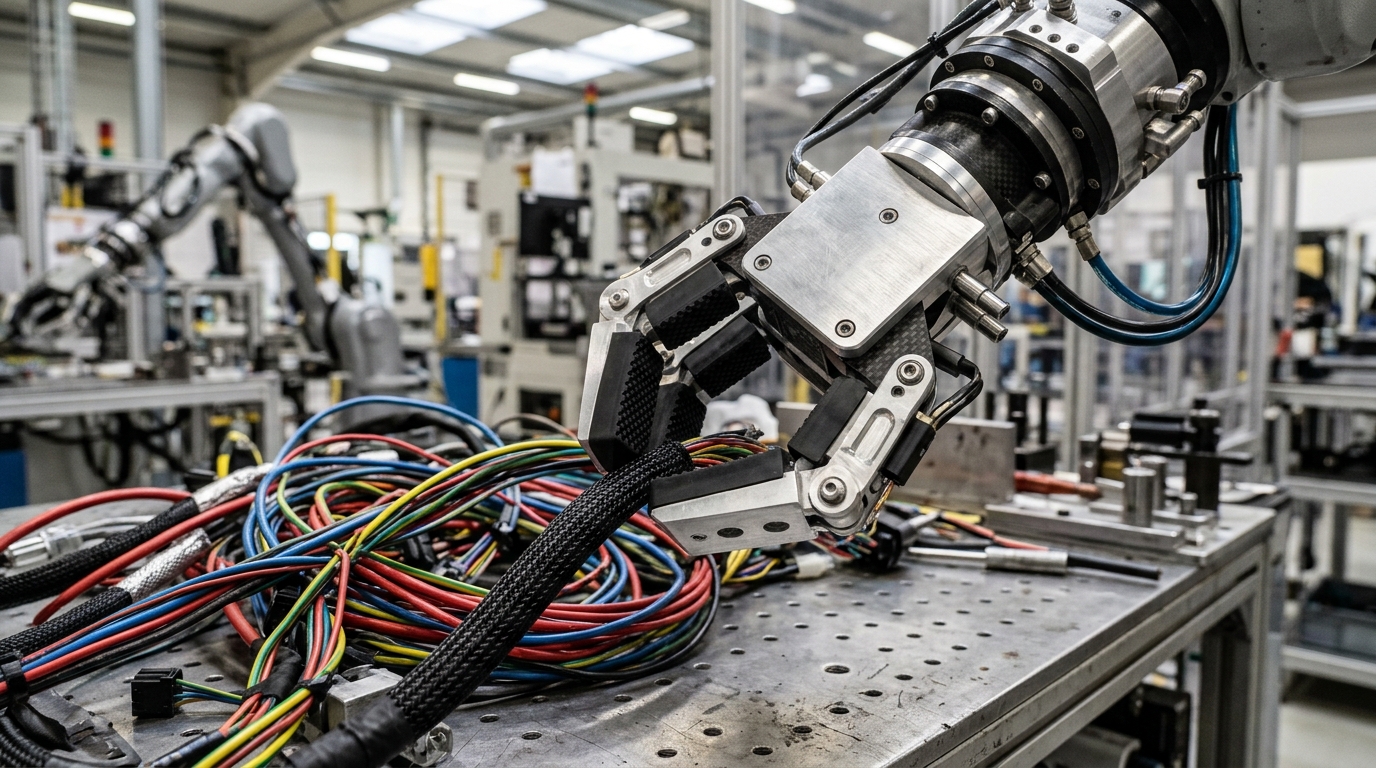
A structural parameter optimization model combining dynamic modeling with an improved Genghis Khan shark algorithm has successfully resolved structural and dynamic coupling challenges in a four-finger cable-driven sorting robot, according to an original research study published in Frontiers in Mechanical Engineering. The study, conducted by researcher Xiaona Cai of the Guangdong University of Science and Technology in Dongguan, China, establishes a closed-loop framework that simultaneously analyzes physical robot parameters and operational dynamic responses. Experimental validation showed that the optimization method demonstrates high computational efficiency, recording an inference time of 48.62 milliseconds while restricting total computational load to 312.47 MFlops.

The research directly targeted a recognized engineering limitation in cable-driven robotics: the lack of collaborative optimization bridging structural parameters and dynamic responses in multi-fingered sorting systems.

To capture the mechanical interactions of the robotic end-effector accurately, the study established a rigid-flexible coupled dynamic model formulated through Lagrange’s equation of the second kind. This governing mathematical formulation explicitly depicts joint flexibility throughout the four articulated fingers of the robot.

For the numerical solving phase, the researcher incorporated an adaptive Lévy flight perturbation mechanism into the Genghis Khan shark algorithm. This algorithmic enhancement enabled the formation of a unified closed-loop optimization framework that directly integrates dynamic modeling, numerical solution, and parametric feedback into a single continuous process.

The root mean square values of the joint driving torques were reduced to as low as 8.93 N·m across the operational cycle.

The structural parameter optimization framework also satisfied stringent structural stiffness criteria under operational load conditions. In terms of mechanical stiffness, the maximum structural deformation observed in the robotic mechanism was restricted to between 0.32 and 0.41 millimeters. Concurrently, the maximum equivalent stress measured throughout the structure ranged between 112.4 and 128.6 MPa. All resulting stress and deformation values satisfied the required strength constraints established for aluminum alloy materials.

In addition to structural stiffness and reduced driving torques, the optimized robotic hand exhibited notable optimization gains and lightweight physical dimensions. The optimization method achieved a fitness improvement rate ranging from 46.5% to 51.2%, while total hand mass was maintained between 2.75 and 2.96 kilograms. Cai concluded that the collaborative mechanism of dynamic modeling and the improved Genghis Khan shark algorithm effectively solves the coupling optimization problem, providing key technical support for structural design in high-speed sorting scenarios such as food, electronics, and automotive components.

Subject of Research: Structural parameter and dynamic response optimization for cable-driven sorting robots

Article Title: Structural optimization design of Sorting Robots Based on dynamic modeling and Genghis Khan Shark Algorithm

Article References: Cai, X. (2026). Structural optimization design of Sorting Robots Based on dynamic modeling and Genghis Khan Shark Algorithm. Frontiers in Mechanical Engineering, 12, Article 1994122. https://doi.org/10.3389/fmech.2026.1994122

Image Credits: AI Generated

DOI: 10.3389/fmech.2026.1994122

Keywords: four-finger cable-driven sorting robot, cable-driven robots, Genghis Khan shark algorithm, dynamic modeling, structural parameter optimization, rigid-flexible coupling, Lagrange's equation of the second kind, joint flexibility, rope-wheel transmission, Lévy flight perturbation, joint driving torque, structural deformation, equivalent stress, aluminum alloy constraints, computational load, hand mass, high-speed sorting

News Source: Denise Maddox. (November 17, 2026). Shark Algorithm and Dynamic Modeling Optimize Four-Finger Cable Sorting Robot. Scienmag.
Tags: aluminum alloy constraintscable-driven robotscomputational loaddynamic modelingequivalent stressfour-finger cable-driven sorting robotGenghis Khan shark algorithmhand masshigh-speed sortingjoint driving torquejoint flexibilityLagrange's equation of the second kindLévy flight perturbationrigid–flexible couplingrope-wheel transmissionstructural deformationstructural parameter optimization
Share12Tweet7Share2ShareShareShare1

Related Posts

Shared Deep Learning Framework Enhances Translation Quality Assessment and Domain Adaptation

Shared Deep Learning Framework Enhances Translation Quality Assessment and Domain Adaptation

November 17, 2026
Water-Film Cooling Reduces Photovoltaic Backsheet Temperatures Across Outdoor Testing Days

Water-Film Cooling Reduces Photovoltaic Backsheet Temperatures Across Outdoor Testing Days

November 17, 2026

Feasibility Gate Cuts Non-Executable Robotic Commands in Natural Language Task Allocation

November 17, 2026

Systematic Review Evaluates Noble Metal Plasmonic Enhancements in Photoelectrochemical Water Splitting

November 17, 2026

POPULAR NEWS

  • Endometrial Receptivity During Embryo Implantation Linked to Endoplasmic Reticulum Stress

    Endometrial Receptivity During Embryo Implantation Linked to Endoplasmic Reticulum Stress

    29 shares
    Share 12 Tweet 7
  • Floral and Genetic Traits Differentiate Dwarf Succulent Species in South Africa

    29 shares
    Share 12 Tweet 7
  • Protocol Outlines Precise Chromosomal DNA Manipulations in Plants Using Programmable Recombinases

    29 shares
    Share 12 Tweet 7
  • Mild Respiratory Viruses Do Not Accelerate Biological Immune Aging After Recovery

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Cardiac Protein MYBPHL Rises to Protect Against Bacterial Sepsis Myocardial Injury

Shark Algorithm and Dynamic Modeling Optimize Four-Finger Cable Sorting Robot

Community-Based Wheelchair Skills Training Shows Potential Cost-Effectiveness in Irish Study

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 88 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.