• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Saturday, November 7, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Semantic Reinforcement Planning Boosts Obstacle Avoidance for Mobile Robots

by
November 7, 2026
in Technology
Reading Time: 2 mins read
0
Semantic Reinforcement Planning Boosts Obstacle Avoidance for Mobile Robots

Semantic Reinforcement Planning Boosts Obstacle Avoidance for Mobile Robots

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

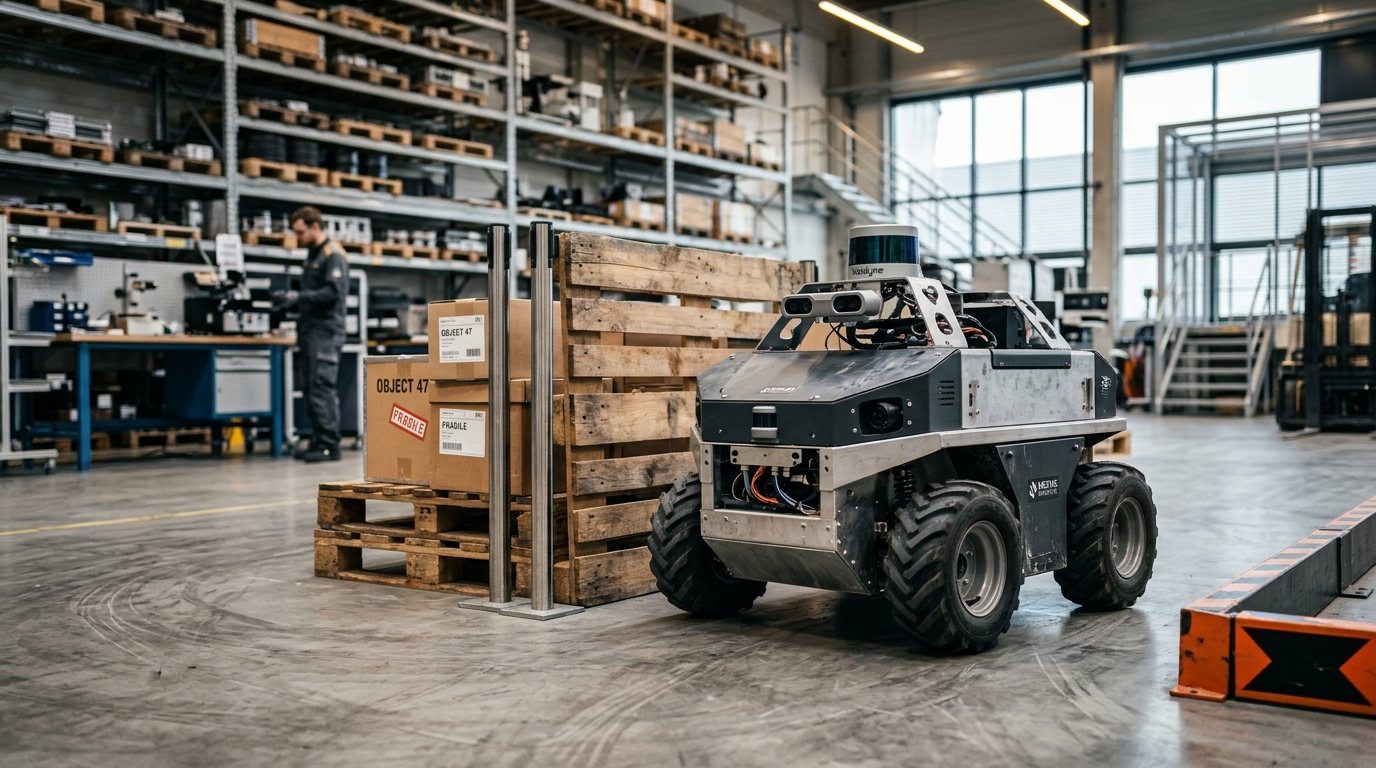
Researchers Huanhuan Zheng and Jiayang Wu have introduced a Semantic-Augmented Reinforcement Planning framework, known as SARP, designed for mobile robot obstacle avoidance and path optimization in complex and dynamic environments. Reporting in the journal Neural Processing Letters on 06 November 2026, the authors detail how the newly developed framework tackles difficult navigation challenges by establishing semantically enriched state representations. To build these comprehensive state representations, the SARP architecture integrates semantic embeddings extracted from a pre-trained language encoder directly into reinforcement learning, effectively merging real-time geometric perception with broader contextual knowledge.

To govern robotic navigation decisions and trajectory planning, SARP incorporates a specialized semantic-guided policy optimization mechanism. This policy optimization mechanism is formulated to systematically align operational efficiency, physical safety, and specific task intent during autonomous transit.

Asynchronous semantic updates decouple language encoding from the high-frequency control loop.

The researchers evaluated the navigation performance of SARP across three distinct experimental environments: dynamic maze scenarios, corridor crossing scenarios, and crowded field scenarios. Across all three testing environments, SARP substantially outperformed conventional reinforcement learning baselines in mobile robot obstacle avoidance and path optimization. In addition, SARP achieved navigation performance that was competitive with or slightly superior to representative large-language-model-aware navigation approaches evaluated within the same experimental conditions.

Beyond achieving high navigation success, SARP accomplished these results while requiring substantially lower online semantic inference overhead than representative large-language-model-aware methods. Detailed system profiling conducted on standard desktop platforms as well as embedded NVIDIA platforms further demonstrated a highly favorable performance-latency trade-off.

Subject of Research: Mobile robot obstacle avoidance and path optimization

Article Title: SARP: A Semantic-Augmented Reinforcement Planning Framework for Mobile Robot Obstacle Avoidance and Path Optimization

Article References: Zheng, H., & Wu, J. (2026). SARP: A Semantic-Augmented Reinforcement Planning Framework for Mobile Robot Obstacle Avoidance and Path Optimization. Neural Processing Letters. https://doi.org/10.1007/s11063-026-11888-5

Image Credits: AI Generated

DOI: 10.1007/s11063-026-11888-5

Keywords: mobile robotics, reinforcement learning, path optimization, obstacle avoidance, semantic embeddings, language encoders, edge computing, robot navigation, SARP, Semantic-Augmented, Reinforcement, Planning

News Source: Denise Maddox. (November 7, 2026). Semantic Reinforcement Planning Boosts Obstacle Avoidance for Mobile Robots. Scienmag.
Tags: Edge Computinglanguage encodersmobile roboticsobstacle avoidancepath optimizationplanningreinforcementReinforcement Learningrobot navigationSARPsemantic embeddingsSemantic-Augmented
Share12Tweet7Share2ShareShareShare1

Related Posts

Homomorphic Encryption Framework Balances Distributed Datasets and Boosts Federated Learning Accuracy

Homomorphic Encryption Framework Balances Distributed Datasets and Boosts Federated Learning Accuracy

November 7, 2026
Neuro-Fuzzy Architecture Improves Appliance Disaggregation and Uncertainty Estimation in Microgrids

Neuro-Fuzzy Architecture Improves Appliance Disaggregation and Uncertainty Estimation in Microgrids

November 7, 2026

Graph Convolutional Network Recognizes Martial Arts Categories on Edge Hardware

November 7, 2026

Reinforcement Learning Outperforms Algorithmic Planning in Simulated Automotive Wire Harness Assembly

November 7, 2026

POPULAR NEWS

  • Research report: Bazi Bushen Attenuates Skeletal Muscle Decline Associated With Oestrogen Deficiency and Modulates FGFR1/ERK Signalling

    Research report: Bazi Bushen Attenuates Skeletal Muscle Decline Associated With Oestrogen Deficiency and Modulates FGFR1/ERK Signalling

    29 shares
    Share 12 Tweet 7
  • Cholesterol Binding Stabilizes THIK-1 Channel and Promotes Atherosclerosis

    29 shares
    Share 12 Tweet 7
  • Enzymes boost activity and fluid flow in crowded protein droplets

    29 shares
    Share 12 Tweet 7
  • First Record of the Clouded Reed Snake in Yunnan Expands Known Range

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Autonomous Grazing Maintains Dutch River Floodplains at Lower Cost

Four Plasma Proteins Linked to Macrovascular Complications in Type 2 Diabetes

Framework Reassesses Radiation Dose Constraints for IDH-Wildtype Glioblastoma Treatment

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 86 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.