A newly developed robot-assisted active shoulder simulator has demonstrated the ability to reproduce stable, muscle-driven glenohumeral abduction up to 60 degrees across nineteen fresh-frozen cadaveric specimens. The experimental platform successfully combined physiological muscle actuation with robotic constraint management, providing a framework for continuous, synchronized biomechanical analysis during dynamic movement.
Developing stable and repeatable muscle-driven shoulder simulations has long remained a technical hurdle in ex vivo research. Dynamic shoulder simulation is essential for evaluating biomechanical variables that cannot be measured directly in vivo during active movement, including joint reaction forces, joint torques, and glenohumeral translations.
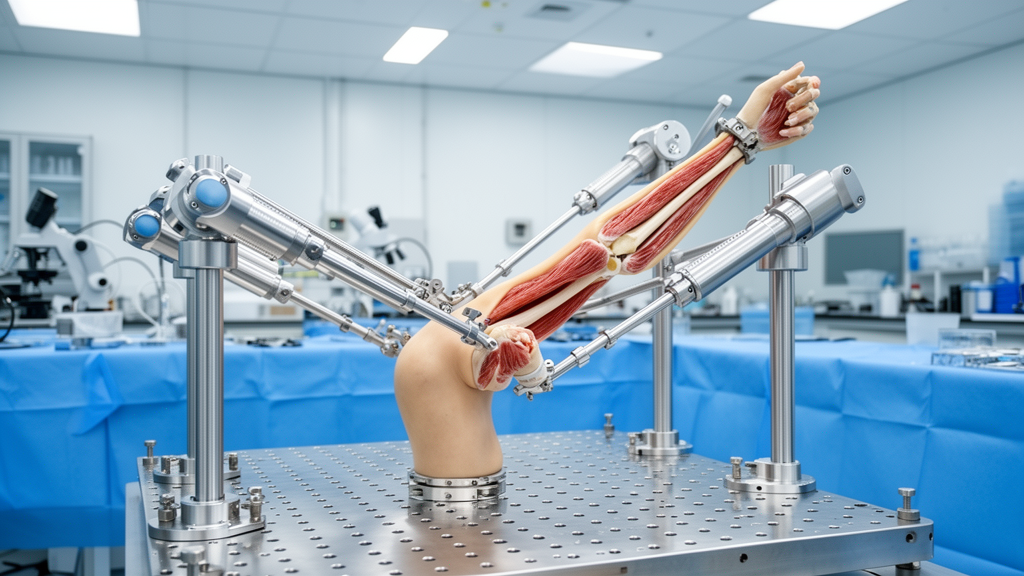
To overcome these experimental difficulties, researchers established the robot-assisted active shoulder simulator, which integrates six cable-driven actuators. These actuators were configured to apply physiological tensile forces directly to the rotator cuff and the deltoid muscle group during testing.
An industrial robot operated as an active load-application and compensation interface throughout active scapular-plane glenohumeral abduction. The robotic system maintained defined mechanical boundary conditions and collected synchronized kinematic and kinetic data while employing closed-loop force control to regulate actuator loading.
Under the experimental protocol, internal rotation and horizontal adduction were constrained to 0 degrees. Translational force targets were applied to maintain glenohumeral joint compression while muscle force ratios were continuously updated across the entire range of motion.
Testing confirmed that active glenohumeral abduction to 60 degrees was successfully achieved in all nineteen shoulder specimens. The industrial robot actively compensated for emerging external loads and torques, ensuring that the cable-driven actuators remained the primary drivers of joint abduction.
Measurements revealed that mean total muscle force increased significantly with abduction angle, rising from 81 ± 36 N/kg at 20 degrees to 107 ± 28 N/kg at 60 degrees. Directional translation analyses showed that superior translation increased significantly as the joint abducted, whereas medial and posterior translations exhibited no significant angle-dependent changes.
Joint torques also varied across the movement arc, with horizontal adduction torque increasing from 20 degrees to 40 degrees and remaining elevated at 60 degrees, while internal rotation torque reached its maximum magnitude at 40 degrees. The authors concluded that this robotic framework establishes a feasible methodological advance for investigating shoulder stability, complex dynamic motions, and dynamic joint loading.
The motivation behind developing the simulator centers on longstanding difficulties in biomechanical testing: achieving stable and repeatable muscle-driven shoulder motion ex vivo has remained hard to accomplish. Such laboratory simulation is nonetheless critical because clinically relevant biomechanical variables cannot be measured directly during active movement in vivo. Specifically, researchers cannot directly capture internal joint reaction forces, glenohumeral translations, or joint torques while dynamic motion occurs in living subjects. By establishing the robot-assisted active shoulder simulator, or RAASS, the methodology creates a repeatable platform for examining active shoulder mechanics outside the body.
The technical framework couples targeted anatomical actuation with closed-loop robotic control. In the simulator, six cable-driven actuators apply mechanical forces directly to the deltoid muscle group and the rotator cuff. Loading across these cable actuators is regulated through closed-loop force control, while muscle force ratios are actively updated across the full range of motion. Simultaneously, translational force targets are enforced to maintain joint compression throughout the test. Operating alongside these actuators, an industrial robot maintains defined boundary conditions by constraining internal rotation and horizontal adduction to 0 degrees during active scapular-plane glenohumeral abduction across nineteen fresh-frozen cadaveric shoulders.
A vital technical feature of the system is the function of the industrial robot as an active load-application and compensation interface. As cadaveric shoulders undergo active abduction, unwanted secondary torques and external loads emerge. Rather than permitting these forces to disrupt the movement, the robotic system actively compensates for emerging external loads and torques. This robotic compensation allows the cable-driven actuators to remain the primary drivers of joint motion, ensuring that the movement is muscle-driven while achieving successful reproduction of active glenohumeral abduction up to 60 degrees in all nineteen specimens.
The synchronized kinetic and kinematic data collected during active abduction provide quantitative evidence of how loads, displacements, and torques interact across the range of motion. Mean total muscle force increased significantly with abduction angle, rising from 81 ± 36 N/kg at 20 degrees to 107 ± 28 N/kg at 60 degrees. Directional movement analyses demonstrated that superior translation increased significantly with abduction, whereas posterior and medial translations showed no significant angle-dependent changes. Over the same motion arc, horizontal adduction torque increased between 20 degrees and 40 degrees and remained elevated at 60 degrees, while internal rotation torque reached its greatest magnitude at 40 degrees.
Beyond verifying that active glenohumeral abduction to 60 degrees could be reproduced across all specimens, the study demonstrates the feasibility of combining muscle-driven motion with robotic constraint and load management. The simulator provides continuous, synchronized measurement of muscle forces, joint translations, joint torques, and kinematics. According to the authors, establishing the robot as an active compensation interface represents an important methodological advance for investigating shoulder stability, dynamic joint loading, and more complex dynamic shoulder motions.
Subject of Research: Robot-assisted ex vivo biomechanical simulation of active shoulder abduction
Article Title: Establishment of a robot-assisted ex vivo active shoulder simulator
Article References: Albert, A., Gehling, J., Sußiek, J., Engelmann, W., Wermers, J., & Katthagen, J. C. (2026). Establishment of a robot-assisted ex vivo active shoulder simulator. Frontiers in Bioengineering and Biotechnology, 14, Article 1924331. https://doi.org/10.3389/fbioe.2026.1924331
Image Credits: AI Generated
DOI: 10.3389/fbioe.2026.1924331
Keywords: active shoulder simulator, glenohumeral abduction, cadaveric shoulder model, ex vivo simulation, shoulder biomechanics, rotator cuff, deltoid muscle group, cable-driven actuators, closed-loop force control, joint reaction forces, glenohumeral translation, joint torques, industrial robotics, scapular plane, dynamic joint motion, joint compression, superior translation, horizontal adduction torque
News Source: Denise Maddox. (November 14, 2026). Robot-Assisted Simulator Successfully Achieves Active Dynamic Shoulder Abduction in Cadaveric Specimens. Scienmag.