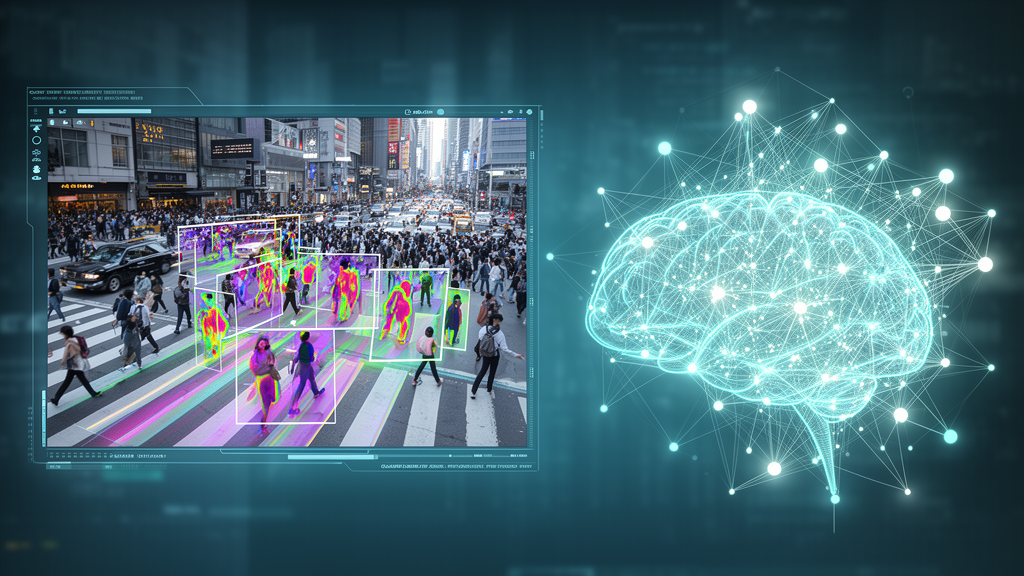
Multi-object tracking (MOT) serves as a critical foundation for intelligent transportation, autonomous driving, mobile robotics, and large-scale video analysis. Recent advancements have seen a significant shift from the conventional tracking-by-detection paradigm, which relies heavily on frame-wise association of detections, toward end-to-end transformer-based formulations. In these newer query-based frameworks, such as MOTR and MOTRv2, object trajectories are represented and propagated across frames as learned latent queries. While this approach offers a more unified and streamlined tracking pipeline, it introduces a reliance on the integrity of these propagated states. When a track query is degraded by factors like partial occlusion, missed observations, camera motion, or ambiguous object interactions, it can persist through subsequent decoding layers, negatively impacting future trajectory evolution and identity consistency. To address this challenge, researchers have introduced TRAQ-query, a method for trajectory reliability-aware query modulation that estimates the suitability of these latent states for propagation and regulates them through bounded interpolation.
The core mechanism of TRAQ-query operates as an adaptive layer within the existing tracking pipeline. Rather than relying on simple confidence thresholds or hard termination triggers, which often discard historical trajectory data, the method treats propagation reliability as a continuous quantity. The overall architecture incorporates three primary components: a trajectory reliability estimation head, Motion-Consistency Intersection-over-Union (MCIoU) based soft reliability supervision, and reliability-conditioned query modulation. The reliability head, a lightweight two-layer multilayer perceptron with 67,329 parameters, takes as input a descriptor composed of the current trajectory representation and short-term geometric information, including bounding-box variations. This design allows the tracker to distinguish between reliable states that are suitable for continued propagation and states that have become degraded. Crucially, the system uses MCIoU during training to provide a bounded, retrospective signal of geometric consistency, ensuring the reliability score remains grounded in the short-term geometric evolution of the target objects.
Following the standard query-interaction update in the baseline tracker, the predicted reliability score directly controls a modulation operator that balances the existing query against a fresh-query reference derived from the model’s initialization space. This interpolation process is governed by a modulation weight, which is dynamically adjusted based on the reliability estimate. If a track query exhibits high reliability, it remains largely unchanged, thereby preserving the temporal continuity established by the transformer decoder. Conversely, for queries that show signs of degradation, the modulation mechanism applies a stronger correction by shifting the state toward the fresh-query reference. This continuous adjustment prevents the accumulation of propagation errors without the need for abrupt, binary resets or the deletion of potentially useful historical information, maintaining a smoother transitions for active tracking trajectories.
The implementation of TRAQ-query follows a freeze-main adaptation protocol that ensures the baseline tracking parameters remain stable while optimizing the reliability component. During this phase, the backbone, transformer encoder and decoder, prediction heads, and the query-interaction module are held fixed. Only the reliability head is optimized against the MCIoU-based supervisory target. This design isolates the reliability-conditioning signal from the underlying tracker’s training objective, effectively creating a plugin-like module that does not require end-to-end retraining of the massive vision-transformer backbone. Parameter-level verification confirms that the original tracking network’s internal weights remain identical before and after the adaptation, guaranteeing that the baseline architecture’s functionality remains consistent while gaining the benefits of intelligent query regulation.
Experimental validation on the complete 200-video BDD100K vehicle validation split demonstrates the performance gains provided by this regulation. Compared to the MOTRv2-style baseline using the same controlled proposal database, TRAQ-query improves Higher Order Tracking Accuracy (HOTA) from 16.657 to 18.252, Multiple Object Tracking Accuracy (MOTA) from 1.769 to 2.333, and Identification F1 score (IDF1) from 12.646 to 14.562. Perhaps most significantly, the method achieves a reduction of 11,780 in false negatives, signaling a robust improvement in target coverage. These metrics illustrate the method’s ability to recover and maintain trajectory hypotheses that would otherwise be lost during the propagation process due to occlusions or localization errors.
Further analysis reveals a nuanced trade-off between target coverage and association quality that warrants careful management. At the canonical output threshold, the increased detection-side coverage is accompanied by a rise in identity switches and false positives, highlighting that higher detection rates do not automatically translate to perfect identity association. To dissect this, the research team employed a matched-coverage operating point where the total number of reported detections is held equal to the baseline. In this controlled comparison, TRAQ-query maintains higher HOTA, MOTA, and IDF1 values, with identity switches remaining largely unchanged. This finding suggests that the association degradation observed at the canonical point is at least partially induced by the tracker’s increased output density rather than being a fundamental flaw in the modulation mechanism.
The team also conducted a prospective analysis to determine the predictive validity of the learned reliability signal. By comparing the reliability estimates to the original tracker confidence scores, they demonstrated that the reliability head is substantially more informative regarding next-frame localization quality, achieving a Spearman correlation of 0.478 compared to 0.242 for the tracker confidence. This result confirms that the reliability head captures specific geometric consistency features relevant to future propagation stability that are not implicitly encoded in the standard detector score. While the tracker confidence remains more discriminative for overall identity-switch events, the reliability estimate provides a superior anticipatory mechanism for the geometric health of the trajectory, supporting its use as a specialized signal for temporal regulation.
To ensure that the performance improvements are not limited to the BDD100K diagnostic setting, the researchers performed cross-benchmark validation on DanceTrack using the official pretrained MOTRv2 checkpoint and its corresponding YOLOX proposal database. On this benchmark, which features complex multi-human tracking, TRAQ-query achieved 70.7 HOTA, 92.2 MOTA, and 72.9 IDF1, outperforming the published MOTRv2 reference of 69.9 HOTA, 91.9 MOTA, and 71.7 IDF1. The consistency of these results across distinct datasets and tracking domains indicates that reliability-conditioned query modulation is an effective strategy that generalizes beyond the specific configuration of the BDD100K baseline, providing a performance uplift to already high-performance models.
Resource management also plays a critical role in the scalability of query-based trackers. Unconstrained query propagation can lead to rare but severe query accumulation, potentially straining GPU memory in difficult sequences. To mitigate this, the study introduced a fixed-query budget protocol based on the maximum observed hypothesis count of the baseline tracker. When the number of active trajectories exceeds this limit, excess queries with the lowest confidence are pruned. Under this constraint, TRAQ-query maintains its tracking performance gains while keeping peak reserved memory and per-frame latency comparable to the baseline. This effectively addresses the risk of rare but severe memory growth, demonstrating that the method is suitable for deployment in demanding, large-scale multi-object tracking environments.
Despite these successes, the research identifies several clear limitations. The absence of usable frame-level occlusion or visibility labels in the BDD100K evaluation means the analysis cannot explicitly distinguish performance in hidden-state scenarios. Furthermore, while the method shows strong results on MOTRv2-based frameworks, universal generalization across every variety of architecture, detector configuration, or object category remains unproven. The researchers emphasize that reliability-conditioned query regulation is a powerful tool for controlling temporal state propagation, but it remains a complement to, rather than a replacement for, robust association and identity management. Further work investigating the role of these techniques in other transformer-based tracking frameworks and on benchmarks with more granular visibility annotation will be essential for realizing the full potential of reliability-aware tracking systems.
Subject of Research: Trajectory reliability-aware query modulation for transformer-based multi-object tracking.
Article Title: TRAQ-query: trajectory reliability-aware query modulation for transformer-based multi-object tracking
Article References: Gao, W. (2026). TRAQ-query: trajectory reliability-aware query modulation for transformer-based multi-object tracking. Journal of King Saud University Computer and Information Sciences, 38(10), Article 1022. https://doi.org/10.1007/s44443-026-01495-8
Image Credits: AI Generated
DOI: 10.1007/s44443-026-01495-8
Keywords: Multi-object tracking, Transformer models, Query propagation, Trajectory reliability, Motion consistency, Computer vision, Autonomous driving, Object localization, Deep learning, Temporal tracking, BDD100K, DanceTrack, Representation learning, Attention mechanisms, Performance optimization, Inference stability, Query modulation, Geometric consistency
News Source: Blake Davidson. (November 18, 2026). Reliability-Aware Query Modulation Improves Accuracy in Transformer-Based Multi-Object Tracking. Scienmag.