• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Thursday, November 19, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Receding-Horizon Trajectory Planner Improves Robotic Arm Path Tracking and Replanning Efficiency

by
November 19, 2026
in Technology
Reading Time: 2 mins read
0
Receding-Horizon Trajectory Planner Improves Robotic Arm Path Tracking and Replanning Efficiency

Receding-Horizon Trajectory Planner Improves Robotic Arm Path Tracking and Replanning Efficiency

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

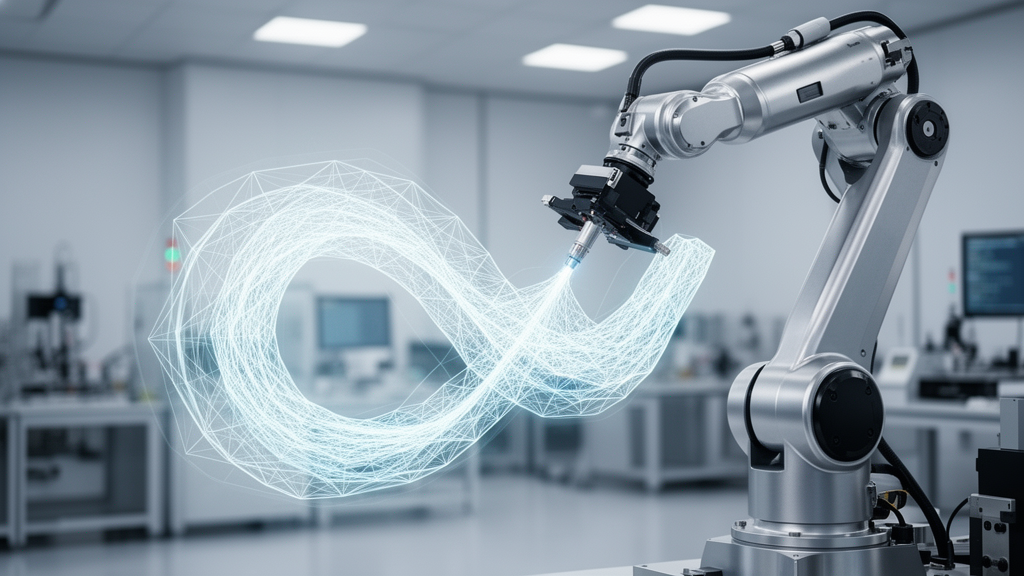
A novel receding-horizon trajectory optimization approach for robot manipulator arms enables seamless switching between unconstrained free-space motions and predefined path segments during online replanning. Developed to address manipulation scenarios such as human–robot interaction, the planning framework systematically unites free-space movements with constrained path tracking. The authors report that the method remains effective even when executing long task sequences that extend beyond the duration of the active planning horizon.

The optimization strategy functions by dividing the receding planning horizon into multiple distinct segments centered around waypoints, contingent upon their reachability. Within this segmented framework, distinct motion conditions can be established for each horizon segment, allowing either path-following constraints or free-space motion to be individually assigned. Furthermore, the trajectory planner accommodates task-specific tolerances defined around the designated waypoints as well as along the predefined path segments.

Evaluations conducted across both numerical simulations and physical experiments demonstrated performance advantages over several established planning techniques. The proposed receding-horizon planner achieved shorter overall trajectory durations than point-to-point model predictive control. When compared with classical path-following methods in free-space motion, the approach demonstrated superior computation times and higher planning success rates. Additionally, the planner showed significantly improved computational efficiency relative to offline planning approaches while continuing to deliver good trajectory quality.

To validate the online replanning capabilities of the planner under dynamic conditions, the researchers deployed the system in an experimental drawing task using a KUKA LBR iiwa 14 R820 robot manipulator arm. During the experimental demonstration, the robotic manipulator was tasked with drawing a path onto a whiteboard surface. The setup tested the system by having the whiteboard physically moved while the drawing was underway, confirming the planner’s ability to recalculate and maintain trajectories in real time.

Subject of Research: Receding-horizon trajectory optimization for robot manipulator arms

Article Title: Receding Horizon Trajectory Optimization Through Path Segments and Waypoints

Article References: Beck, F., Oelerich, T., Nhat Vu, M., Hartl-Nesic, C., & Kugi, A. (2026). Receding Horizon Trajectory Optimization Through Path Segments and Waypoints. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02457-y

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02457-y

Keywords: robot manipulator arms, trajectory optimization, receding-horizon planning, path segments, waypoints, free-space motion, path-following constraints, online replanning, human-robot interaction, point-to-point MPC, computational efficiency, trajectory duration, planning horizon, KUKA LBR iiwa, robot drawing task, motion planning

News Source: Denise Maddox. (November 19, 2026). Receding-Horizon Trajectory Planner Improves Robotic Arm Path Tracking and Replanning Efficiency. Scienmag.
Tags: Computational efficiencyfree-space motionHuman-Robot InteractionKUKA LBR iiwamotion planningonline replanningpath segmentspath-following constraintsplanning horizonpoint-to-point MPCreceding-horizon planningrobot drawing taskrobot manipulator armstrajectory durationtrajectory optimizationwaypoints
Share12Tweet7Share2ShareShareShare1

Related Posts

Planar Path Planning Slashes Excavator Computation Time in Physics Simulation Benchmark

Planar Path Planning Slashes Excavator Computation Time in Physics Simulation Benchmark

November 19, 2026
Banana Pseudostem Biochar Catalyst Drives Rapid Hydrogen Generation from Ammonia Borane

Banana Pseudostem Biochar Catalyst Drives Rapid Hydrogen Generation from Ammonia Borane

November 19, 2026

Researchers Examine Artificial Intelligence Applications and Governance Challenges Across Financial Systems

November 19, 2026

Asymmetric Virtual Machine Relocation Cuts Cloud Energy Use in Heterogeneous Server Clusters

November 19, 2026

POPULAR NEWS

  • East Hararghe Farmers Show Mixed Perceptions Toward Irrigated Cluster Wheat Farming

    East Hararghe Farmers Show Mixed Perceptions Toward Irrigated Cluster Wheat Farming

    29 shares
    Share 12 Tweet 7
  • Fruit and Vegetable Consumption Declined Among Iranian Adults With Hypertension Over 15 Years

    29 shares
    Share 12 Tweet 7
  • Multiscale Fusion Dehazing Algorithm Preserves Sharp Edges in Foggy Driving Vision

    29 shares
    Share 12 Tweet 7
  • Periorbital Anthrax Mimicked Necrotizing Infection Following Soil Trauma in Case Report

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Clinical Adjustments During ACTH Therapy Signal Refractory Infantile Spasms

Multimodal Machine Learning Models Predict Postoperative Complications in Crohn’s Disease

American Crocodile Movement Intensity Was Higher During Wet Season in Costa Rica

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 89 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.