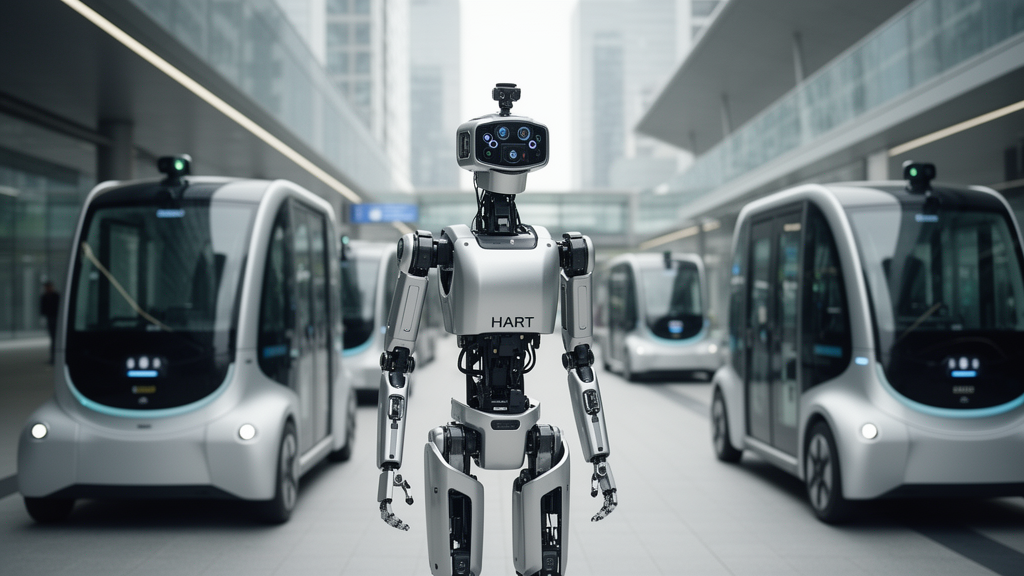
An autonomous vehicle-driving control system has been developed for the full-sized humanoid platform known as HART, or Human Assistive RoboT. The platform is constructed as a kinematically resizable biped designed to operate various types of vehicles by altering its physical mechanical dimensions to accommodate given circumstances.
Central to the platform’s operation is a landmark-based wayfinding navigation control architecture. This architecture was designed to enable HART to steer and control an assigned vehicle within spatially configured environments by referencing environmental landmarks.
The navigation process begins with a path-planning stage that generates a guideline trajectory. This trajectory consists of a series of waypoints linking the vehicle’s starting point to its designated goal destination, which is subsequently supplied to a landmark recognition module.
Within the landmark recognition module, the guideline trajectory data and Global Navigation Satellite System (GNSS) measurements serve as primary references. The system integrates these positioning references with real-time incoming image data to perform lane and intersection detection.
Based on the detected intersections acting as landmark waypoints, the recognition module calculates and generates recommended motions. These adaptive motions direct HART to manipulate the primary mechanical control inputs of the vehicle during transit.
To enhance the perception performance of the landmark recognition module, the researchers incorporated an intersection classifier based on a convolutional neural network. The development of this classifier included evaluations of multiple network structures and hyperparameters, as well as performance comparisons with alternative models.
The complete navigation control architecture and autonomous driving capability of the HART platform were subsequently tested and evaluated through experimental trials in a real-world setting.
Subject of Research: Autonomous vehicle-driving control system for the full-sized humanoid robot HART
Article Title: Vehicle-Driving in Spatially Configured Workspace by a Full-Sized Humanoid Platform, HART
Article References: Yang, J., Bickford, H., Esteves, A., Wisdom, J., & Sohn, K. (2026). Vehicle-Driving in Spatially Configured Workspace by a Full-Sized Humanoid Platform, HART. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02492-9
Image Credits: AI Generated
DOI: 10.1007/s10846-026-02492-9
Keywords: HART, Human Assistive RoboT, humanoid platform, kinematically resizable biped, autonomous vehicle driving, wayfinding navigation, landmark recognition, path planning, guideline trajectory, waypoint navigation, GNSS data, lane detection, intersection detection, convolutional neural networks, intersection classifier, vehicle control manipulation, spatially configured environments, real-world experimentation
News Source: Denise Maddox. (November 17, 2026). Full-Sized Humanoid Platform HART Navigates Vehicles Using Landmark Wayfinding Architecture. Scienmag.