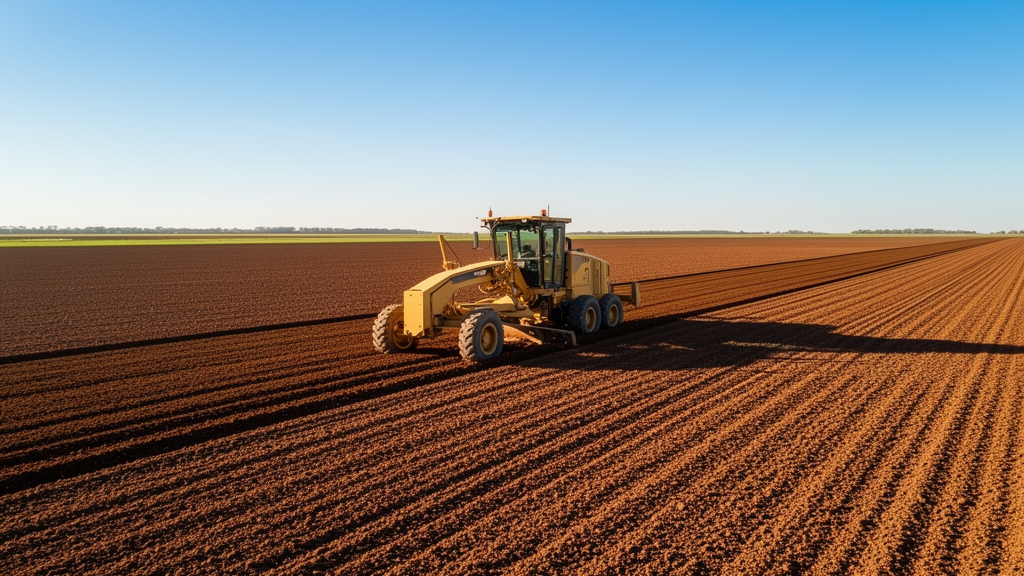
Agricultural engineering researchers have developed an integrated modeling, optimization, and smoothing framework based on an improved ant colony optimization algorithm that substantially enhances autonomous grader path planning during farmland levelling operations. In comprehensive field trials and simulated terrain evaluations, the newly designed algorithm reduced the required inter-region operational travel distance by 24.41 percent while simultaneously improving the thoroughness of soil reallocation across uneven agricultural plots. Field land levelling represents an essential preparatory procedure in modern crop production, establishing uniform surface elevations that ensure equitable irrigation distribution, facilitate efficient drainage, and promote the reliable navigation of mechanized agricultural equipment. By coupling kinematic motion constraints directly with real-time soil excavation and backfill allocations, the computational strategy resolves persistent operational inefficiencies where autonomous machinery previously performed redundant passes, suffered steering oscillations, or traversed empty paths without contributing to necessary topographical leveling.
Traditional farmland grading has long depended on the subjective visual assessments and manual control skills of tractor operators, who manipulate levelling scrapers to strip elevated ground and deposit earth into depressed sectors. Manual earthmoving frequently results in repetitive, uncoordinated passes that unnecessarily elevate machinery fuel consumption, exhaust emissions, and operator labor duration. While the advent of high-precision global navigation satellite systems, automated steering actuators, and electro-hydraulic blade controls has catalyzed a transition toward autonomous machinery, algorithmic trajectory generation has struggled to balance mechanical limitations with dynamic terrain alterations. Conventional coverage path planning methodologies typically deploy rigid geometric routines such as standard S-shaped sweeps, outward spirals, or simple diagonal swaths across field boundaries. These inflexible trajectories regularly overlook the shifting distribution of excavable soil, causing tractors to run with overloaded blades, haul empty buckets across long distances, or miss critical topographical pockets that ultimately require corrective passes.
To address these interrelated physical challenges, the research team conceptualized autonomous land levelling as a multi-constrained, combinatorial sequential decision problem executed across a directed operational graph. In contrast to ordinary robot routing where geometric distance serves as the solitary cost metric, grading operations entail a continuous cycle of loading, transporting, and unloading earth under variable physical states. The operational terrain was first captured through tractor-mounted LiDAR scanning on an experimental agricultural site in Jingkou District, Zhenjiang City, generating a high-resolution digital elevation model. The operational field surface was subsequently discretized into a regular grid of rows and columns based on the scraper width and overall machine system length. Natural neighborhood interpolation established local cell elevations against an overarching target elevation, identifying whether individual zones required excavation, demanded backfill, or required no intervention, while safety boundary buffers and no-go masks isolated untraversable bunds, ditches, and headlands.
The researchers clustered the segmented grid into discrete operational excavation and filling regions using an enhanced K-means++ clustering protocol that initialized cluster centroids via squared distance probabilities, avoiding the local entrapment typical of random seeding. The path planning task was then formulated over a directed graph where nodes represented soil management clusters and edges represented permissible transitions. Crucially, the mathematical model coupled vehicle motion with dynamic state tracking at every progressive transition step. The grading bucket payload was modeled alongside residual excavable volumes in high zones and remaining backfill capacities in depressions, preventing the algorithm from scheduling visits to depleted excavation zones or full infill targets. A composite cost denominator normalized three competing logistical penalties: Euclidean travel distance, estimated travel time based on a nominal travel speed of 0.95 meters per second, and a load-dependent energy consumption proxy that penalized moving heavy soil burdens over extended spans.
The standard ant colony optimization metaheuristic was fundamentally re-engineered into an improved variant named IACO to overcome systemic tendencies toward premature convergence, search stagnation, and blind exploratory wandering. Standard implementations maintain fixed pheromone concentration weights, static heuristic sensitivity factors, and invariant evaporation rates that cannot adapt to the shifting terrain states of late-stage leveling. The proposed framework introduced a linear scheduling mechanism that dynamically adjusts the pheromone concentration weight as iteration counts progress, paired with a non-linear updating rule for the heuristic factor based on edge visitation diversity. Furthermore, the pheromone evaporation coefficient was adaptively modulated in response to cost improvement trends and stagnation counters, while a cut-fill imbalance coefficient dynamically reweighted the importance of effective earthwork gain. Candidate neighbor choices from each current node were pruned to a Top-K candidate set, effectively suppressing low-utility branches and accelerating computational throughput across complex networks.
To protect against runaway pheromone accumulation on sub-optimal routes while safeguarding exploration diversity, the algorithm incorporated a maximum-minimum pheromone bounding mechanism alongside an elite reinforcement strategy. Pheromones were deposited exclusively along the top K elite routes identified in each search cycle, with increments calibrated proportionally to net earthmoving gain divided by total route length. Pheromone concentrations across all network edges were strictly constrained within predefined upper and lower thresholds, preventing search freeze-outs on dominant paths. Beyond combinatorial sequence generation, the framework tackled physical vehicle traceability by processing discrete regional sequences through a multi-stage smoothing pipeline. Inter-region connecting segments were simplified into direct linear corridors where boundary passability permitted, whereas internal operational segments within field clusters were smoothed using parametric cubic Bézier curves. The concatenated global trajectory was then resampled and corrected to ensure that path curvature strictly adhered to the minimum turning radius of the tractor-scraper implement.
The computational performance of the proposed algorithm was systematically evaluated in MATLAB simulations against traditional ant colony optimization and an advanced multi-objective decomposition benchmark, MOEA/D-ACO, across thirty independent runs. Using identical digital elevation inputs, boundary restrictions, and scraper capacities on a representative test field, the enhanced method demonstrated superior convergence behavior and trajectory efficiency. The optimal path length generated by IACO reached 1314.37 meters, representing a 24.41 percent reduction compared to the 1738.91 meters demanded by the traditional ant colony approach, and notably shorter than the 1679.30 meters recorded for the multi-objective benchmark. Concurrently, the average leveling rate achieved across excavation regions climbed from 73.93 percent under traditional ant colony routing to 83.81 percent with IACO, while the average filling region leveling rate reached a complete 100 percent, outperforming the benchmark rates of 90.62 percent and 93.40 percent respectively.
Trajectory feasibility and mechanical operational smoothness likewise showed substantial improvements in numerical simulations. The complete algorithm reduced the total number of turning maneuvers from 637 to 574, while lowering the cumulative steering angle by 15.27 percent, dropping from 201,675.8 degrees down to 170,872.2 degrees. Comprehensive performance, measured via an objective function that evaluates net earthwork gain against combined travel, time, and load costs, improved by 14.10 percent from an initial value of 8.86 down to 7.61. To isolate the individual contributions of each algorithmic component, the investigators executed an ablation study comprising four distinct variants across thirty runs each. Eliminating adaptive parameter tuning increased the mean objective value to 30.45 and degraded success rates to 74.07 percent. Removing elite deposition delayed convergence from 94 iterations to 122 iterations, while omitting the maximum-minimum pheromone bounds induced severe instability, raising the mean objective score to 32.35 and expanding path length to 2365.87 meters.
The research team broadened their numerical validation by benchmarking the enhanced ant colony system against prominent metaheuristics, including genetic algorithms, particle swarm optimization, and northern goshawk optimization. Continuous metaheuristic algorithms required a continuous random-key priority encoding paired with dedicated feasibility-repair operators to enforce discrete topological passability and load capacities. In these comparative trials, the northern goshawk and particle swarm techniques achieved mean objective values of 21.12 and 25.11, yet neither matched the comprehensive objective score of 19.03 or the 91.91 percent feasibility rate demonstrated by IACO. Supplementary evaluations on standard unimodal, multimodal, and hybrid benchmark functions from the CEC2017 test suite confirmed that the core search mechanisms preserved robust global exploration capabilities without succumbing to local optima traps. Although continuous numerical problems differ from discrete operational routing, the benchmark data corroborated the mathematical vitality of the adaptive exploratory operators under complex combinatorial settings.
Sensitivity analyses were also conducted to evaluate how variations in cost-weight parameters influenced algorithmic outputs. The composite cost function balances travel distance, travel duration, and load-related energy expenditure through weighting coefficients designated as lambda d, lambda t, and lambda p, which collectively sum to unity. Five distinct configurations were tested: a balanced scheme, distance-priority weighting, time-priority weighting, energy-priority weighting, and a baseline mixed-priority setup allocating 0.40 to distance and 0.30 each to duration and energy. When energy minimization was prioritized, the algorithm effectively suppressed long-distance transport under loaded conditions, though total path distance increased slightly to 1708.68 meters. Under distance prioritization, planned routes contracted but exhibited slightly lower leveling completeness. Across all evaluated weight combinations, the algorithm consistently generated valid, executable paths with feasibility rates remaining above 74 percent, verifying that the optimization system is resilient to empirical operational parameter tuning.
Physical field validation was conducted on a plot measuring 119 meters by 59 meters in Zhenjiang, China, following rice harvesting and tillage. An automated agricultural system, utilizing a YTO Dongfanghong 1104 tractor equipped with an electro-hydraulic scraper and GNSS positioning, executed paths planned by both methods. Operating logs confirmed that while planning assumed a nominal speed of 0.95 meters per second, actual field speeds ranged from 0.54 to 2.76 meters per second, averaging 1.32 meters per second. Field results revealed that the enhanced algorithm decreased operational path length from 2260.59 meters to 1708.69 meters and curtailed turns from 828 to 746. Post-levelling topographical surveys verified marked terrain improvements: maximum field elevation difference fell from 39.26 centimeters to 8.40 centimeters under IACO, compared to 19.90 centimeters under traditional routing. Surface flatness error dropped to 3.60 centimeters, and the proportion of field elevation points falling within the five-centimeter accuracy threshold reached 92.55 percent, demonstrating superior levelling consistency.
Subject of Research: Autonomous agricultural land levelling path planning using an improved ant colony optimization algorithm
Article Title: Optimization of satellite navigation-based grader path planning using an enhanced ant colony optimization algorithm
Article References: Chen, W., Wei, X., Song, Q., Sun, L., Zheng, Y., Jin, C., Liu, C., Zhang, S., Yi, S., Xu, S., Zhu, Z., & Li, C. (2026). Optimization of satellite navigation-based grader path planning using an enhanced ant colony optimization algorithm. Smart Agricultural Technology, 15, Article 102718. https://doi.org/10.1016/j.atech.2026.102718
Image Credits: AI Generated
DOI: 10.1016/j.atech.2026.102718
Keywords: land levelling, ant colony optimization, autonomous agricultural machinery, grader path planning, global navigation satellite systems, LiDAR elevation mapping, earthwork allocation, blade load capacity, path smoothing, minimum turning radius, digital elevation model, field surface flatness, agricultural robotics, kinematic constraints, metaheuristic optimization, tractor-scraper systems
News Source: Denise Maddox. (November 13, 2026). Enhanced ant colony algorithm optimizes autonomous grader path planning for farmland levelling. Scienmag.