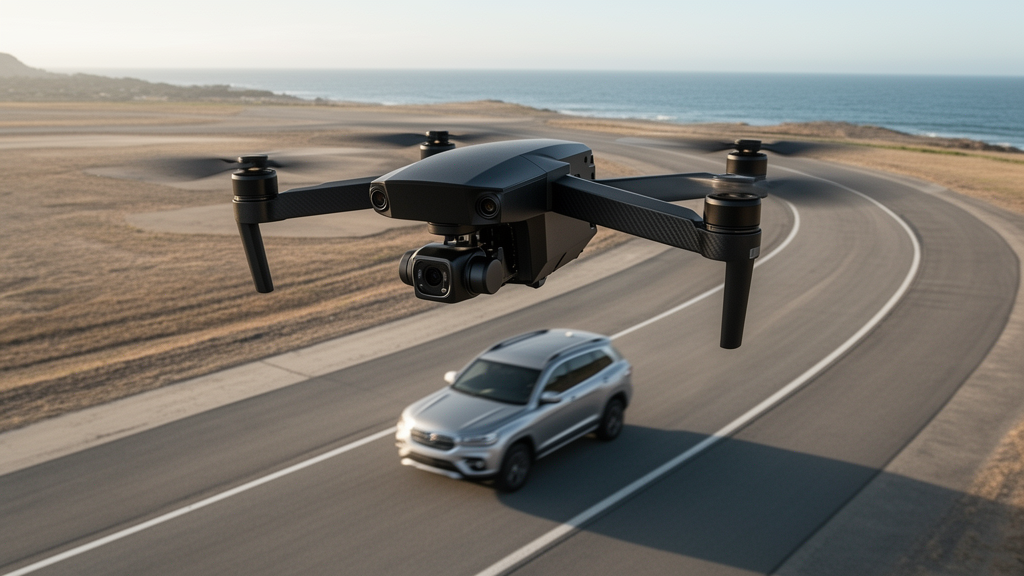
Autonomous surveillance systems must constantly negotiate an operational dilemma: an autonomous agent with a limited sensor footprint must decide at every instant whether to keep tracking a known, moving target or to break away and reconnoiter unobserved regions. In a computational study published in Discover Applied Sciences, researchers Johan Schubert, Farzad Kamrani, and Tove Gustavi demonstrated an active inference route-planning framework that directs an autonomous agent through continuous persistent surveillance missions. Evaluated across 1,000 simulated trials within a synthetic two-dimensional environment, the proposed motion control method directed a single-sensor leader governing a ten-drone swarm, enabling the system to sustain situational awareness without human intervention. When operating with a 100-meter sensor radius, the active inference controller exceeded standard benchmark performance in target observation by an average margin of 51 percent to 69 percent across multiple tracking metrics. By minimizing variational free energy over a spatially distributed operational picture, the autonomous controller systematically balanced the competing operational demands of tactical exploitation and exploratory searching.
Persistent surveillance requires autonomous platforms to monitor designated geographic areas over indefinitely extended periods. Real-world applications for these autonomous systems span perimeter defense around critical industrial infrastructure and military installations, coastal surveillance along public beaches to avert drowning accidents, and ecological monitoring of wildlife populations within fragile natural habitats. Unmanned aerial vehicles serve as particularly capable platforms for such missions due to their operational speed, expansive aerial perspectives, and relatively unconstrained operational airspace free of ground obstacles. However, when autonomous aircraft must track multiple mobile entities across a large operational arena while also monitoring stationary sectors, trajectory planning becomes a multi-objective optimization challenge. If an agent focuses exclusively on target following, unmonitored sectors decay in informational reliability; conversely, if an agent adheres strictly to rigid search circuits, dynamic targets can easily slip out of sensor range and become lost. Addressing this operational tension requires an intelligent decision architecture that can autonomously quantify spatial uncertainty and dynamically prioritize waypoints.
To solve this navigational challenge, the researchers turned to the free energy principle and the active inference framework, an established theoretical paradigm in cognitive science and decision theory. Rooted in the premise that adaptive biological organisms maintain homeostasis by actively countering environmental perturbations and minimizing informational surprise, active inference coordinates sensory perception and physical action within a unified mathematical architecture. Because calculating raw informational surprise directly is mathematically intractable, the agent instead minimizes an analytical upper bound termed variational free energy. In biological and computational systems alike, active inference operates through two complementary mechanisms: updating internal representations to reflect incoming sensory evidence, or executing actions that alter the physical state of the agent relative to the environment so that future observations match internal predictions. The study formulated trajectory planning as a localized, greedy action-selection mechanism driven by the spatial distribution of variational free energy within the active sensor footprint.
Rather than modeling the external environment through classic probability densities, the investigators developed a generative world model grounded in Dempster-Shafer theory of evidence. Representing the surveillance environment as a two-dimensional grid of discrete spatial cells, the framework assigns independent frames of discernment to individual cells to avoid combinatorial computational explosions. In classical probability theory, assigning a probability below one to an event automatically mandates that the remaining probability mass supports its complement. In contrast, Dempster-Shafer theory explicitly separates affirmative evidence supporting target presence from negative evidence indicating target absence, allocating any remaining mass to epistemic uncertainty. For each cell, the agent stores independent basic beliefs for target presence and absence, allowing the system to distinguish between verified emptiness and an absolute lack of observation. This formulation reflects operational scouting realities where incomplete sensor sweeps do not instantly imply that a monitored region is definitively vacant.
Because physical targets move and real-world environments evolve, older sensory data steadily loses operational reliability over time. To model this temporal decay of information without requiring complex trajectory histories, the researchers incorporated explicit spatial diffusion mechanisms into the evidence map. Between consecutive simulation ticks, basic beliefs associated with target presence diffuse outward into surrounding neighbor cells according to a random-walk formulation, causing the spatial certainty of past target detections to spread and dilute much like an expanding physical dispersion. Conversely, basic beliefs signifying target absence contract inward across time, enforcing the physical constraint that a cell can only be presumed empty if its surrounding neighborhood is likewise vacant. This dual diffusion algorithm continually generates a dynamic situational awareness map that naturally elevates uncertainty in sectors that have not been recently visited, thereby creating informational gradients that actively draw the autonomous agent back toward neglected sectors.
Complementing the generative evidence model, the framework incorporates an explicit generative process that mathematically processes new sensory inputs through Bayesian inference. The simulated agent is equipped with an intelligent soft-output image sensor that provides graded classification confidences rather than binary presence labels, closely mirroring the operational characteristics of modern machine learning object detectors. The simulated sensor model assumes perfect detection within its line of sight without false alarms, applying a two-dimensional Gaussian decay function to model decreasing classification confidence as the physical distance between the sensor and a detected target increases. When targets are observed, the sensor projects Gaussian spatial distributions over neighboring coordinates to reflect localization uncertainty. These observations update an ongoing Bayesian posterior distribution across all grid cells inside the sensor radius, combining the previous posterior as a prior with the Gaussian likelihood model to produce an updated probabilistic estimate of target occupancy.
The central innovation of the control strategy lies in the mathematical synthesis of the Dempster-Shafer evidence map and the Bayesian observation process to compute variational free energy. Because the generative world model stores multi-subset basic beliefs while the Bayesian process yields standard point-probability distributions, the agent applies a pignistic transformation to translate the evidence map into compatible probability values. For every grid cell within the circular sensor footprint, the algorithm computes the variational free energy by summing two distinct components: the Kullback-Leibler divergence between the pignistic state probability and the Bayesian posterior distribution, and the observation surprisal represented by the negative logarithm of the observation probability. Surprisal approaches infinity outside the sensor boundary due to the total absence of incoming observations, establishing a natural mathematical rationale for restricting free energy evaluations strictly to the interior of the sensor footprint.
The physical simulation environment was implemented in MATLAB utilizing an in-house Multi-Agent Dynamic Simulator to model the aerodynamics and mutual spacing of a ten-drone swarm. Within this swarm architecture, only a single designated leader drone carries the sensor payload, executes algorithmic calculations, updates the situational awareness map, and selects common navigation waypoints. The nine follower drones maintain flight formation and avoid inter-vehicle collisions via an automated spring-damper low-level flight controller. At each 0.2-second decision interval, the leader computes variational free energy across all cells in its sensor range and identifies the coordinate that minimizes the objective function. The leader then places a new flight waypoint at a distance equal to half the sensor radius along the vector toward that minimum coordinate, ensuring footprint overlap between successive maneuvers. Computational complexity per simulation step was bounded by a polynomial formulation, requiring an average of only 0.12 seconds per step on standard laptop hardware.
The quantitative performance of the variational free energy controller was verified across 1,000 distinct 500-second simulations executed over a 580-meter by 380-meter terrain grid containing four stationary targets and three mobile targets moving along straight trajectories at speeds between 1.0 and 2.0 meters per second. The active inference strategy was benchmarked directly against four comparative control mechanisms: divergence-only control, surprisal-only control, an unguided random walk, and a preplanned fixed-track looping path designed for systematic area coverage. Results showed that with a 100-meter sensor radius, the variational free energy method achieved an average target observation duration of 219.8 seconds, outperforming the fixed-track benchmark by 51.1 percent and outperforming the divergence-only method. Furthermore, variational free energy yielded a 69.2 percent improvement over the fixed-track approach in maintaining basic belief density within a ten-meter radius of true target coordinates, with the mathematical divergence component driving the dominant share of tracking performance.
Despite its superior tracking endurance and autonomous responsiveness, the variational free energy framework revealed clear operational trade-offs and structural limitations. While the fixed-track benchmark detected every single target across 100 percent of the scenarios due to its rigid spatial sweep, the reactive tracking tendencies of the free energy controller occasionally caused it to fixate on known targets, detecting two or more targets in 84.7 percent of runs and all three targets in 46.4 percent of trials. Additionally, the experimental findings were derived under idealized sensor simplifications that omitted real-world false alarms, terrain occlusions, and severe atmospheric interference, and were evaluated on a specific ten-drone configuration. The authors emphasized that runtime and tracking effectiveness should not be extrapolated to larger fleets or denser target arrays without further empirical testing. To build upon these findings, future research will explore expanding the architecture to expected free energy formulations that plan across multi-step trajectory policies.
Subject of Research: Active inference and variational free energy motion control for autonomous drone surveillance
Article Title: Active inference motion control for autonomous persistent surveillance
Article References: Schubert, J., Kamrani, F., & Gustavi, T. (2026). Active inference motion control for autonomous persistent surveillance. Discover Applied Sciences, 8(11), Article 1265. https://doi.org/10.1007/s42452-026-09673-z
Image Credits: AI Generated
DOI: 10.1007/s42452-026-09673-z
Keywords: active inference, variational free energy, autonomous surveillance, unmanned aerial vehicles, persistent monitoring, dempster-shafer theory, evidence mapping, swarm robotics, target tracking, bayesian updating, pignistic transformation, kullback-leibler divergence, motion control, trajectory planning, sensor modeling, surprisal minimization, computer simulation
News Source: Denise Maddox. (November 12, 2026). Active Inference Route Planning Boosts Drone Surveillance Target Tracking in Simulations. Scienmag.