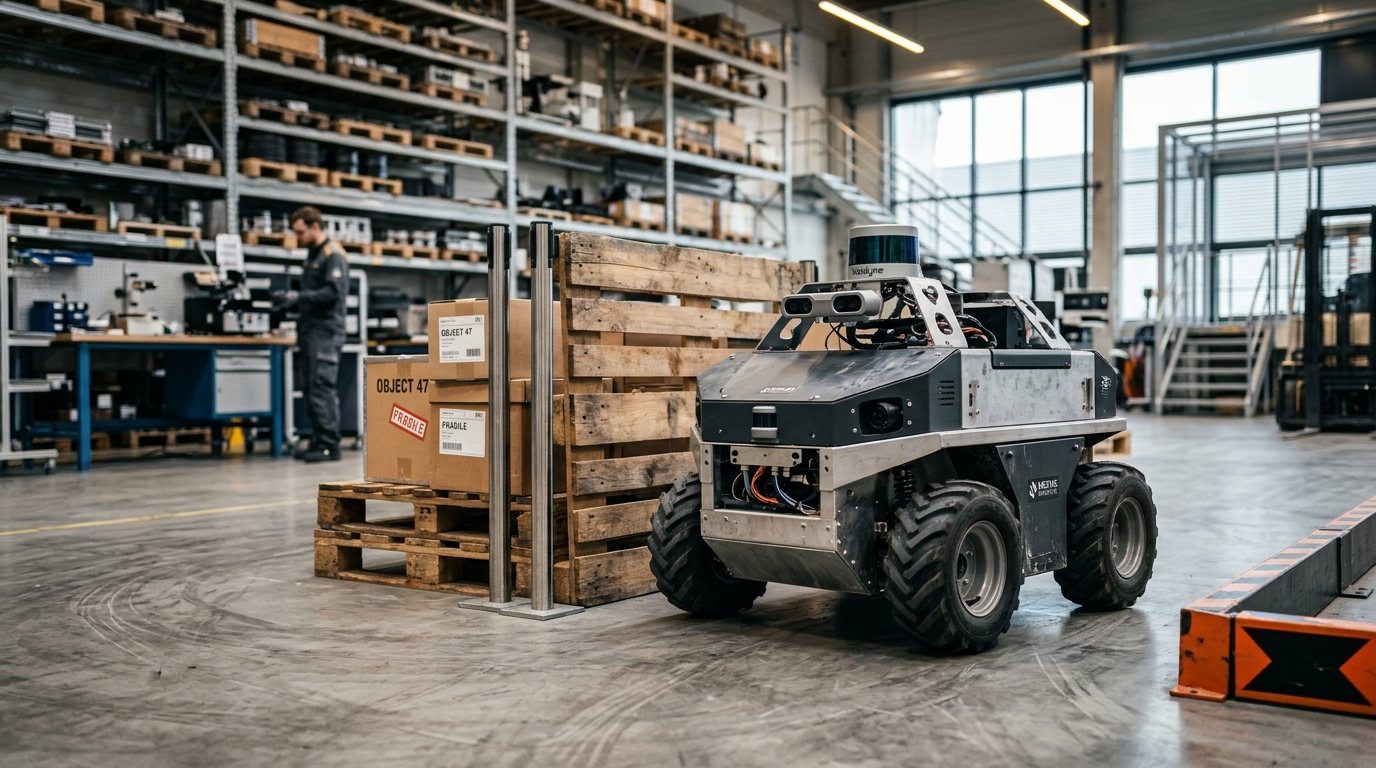
Researchers Huanhuan Zheng and Jiayang Wu have introduced a Semantic-Augmented Reinforcement Planning framework, known as SARP, designed for mobile robot obstacle avoidance and path optimization in complex and dynamic environments. Reporting in the journal Neural Processing Letters on 06 November 2026, the authors detail how the newly developed framework tackles difficult navigation challenges by establishing semantically enriched state representations. To build these comprehensive state representations, the SARP architecture integrates semantic embeddings extracted from a pre-trained language encoder directly into reinforcement learning, effectively merging real-time geometric perception with broader contextual knowledge.
To govern robotic navigation decisions and trajectory planning, SARP incorporates a specialized semantic-guided policy optimization mechanism. This policy optimization mechanism is formulated to systematically align operational efficiency, physical safety, and specific task intent during autonomous transit.
Asynchronous semantic updates decouple language encoding from the high-frequency control loop.
The researchers evaluated the navigation performance of SARP across three distinct experimental environments: dynamic maze scenarios, corridor crossing scenarios, and crowded field scenarios. Across all three testing environments, SARP substantially outperformed conventional reinforcement learning baselines in mobile robot obstacle avoidance and path optimization. In addition, SARP achieved navigation performance that was competitive with or slightly superior to representative large-language-model-aware navigation approaches evaluated within the same experimental conditions.
Beyond achieving high navigation success, SARP accomplished these results while requiring substantially lower online semantic inference overhead than representative large-language-model-aware methods. Detailed system profiling conducted on standard desktop platforms as well as embedded NVIDIA platforms further demonstrated a highly favorable performance-latency trade-off.
Subject of Research: Mobile robot obstacle avoidance and path optimization
Article Title: SARP: A Semantic-Augmented Reinforcement Planning Framework for Mobile Robot Obstacle Avoidance and Path Optimization
Article References: Zheng, H., & Wu, J. (2026). SARP: A Semantic-Augmented Reinforcement Planning Framework for Mobile Robot Obstacle Avoidance and Path Optimization. Neural Processing Letters. https://doi.org/10.1007/s11063-026-11888-5
Image Credits: AI Generated
DOI: 10.1007/s11063-026-11888-5
Keywords: mobile robotics, reinforcement learning, path optimization, obstacle avoidance, semantic embeddings, language encoders, edge computing, robot navigation, SARP, Semantic-Augmented, Reinforcement, Planning
News Source: Denise Maddox. (November 7, 2026). Semantic Reinforcement Planning Boosts Obstacle Avoidance for Mobile Robots. Scienmag.