• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Monday, October 26, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Lightweight SLAM System Helps Robots Navigate Crowded, Changing Scenes

by
October 26, 2026
in Technology
Reading Time: 2 mins read
0
Lightweight SLAM System Helps Robots Navigate Crowded, Changing Scenes

Lightweight SLAM System Helps Robots Navigate Crowded, Changing Scenes

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

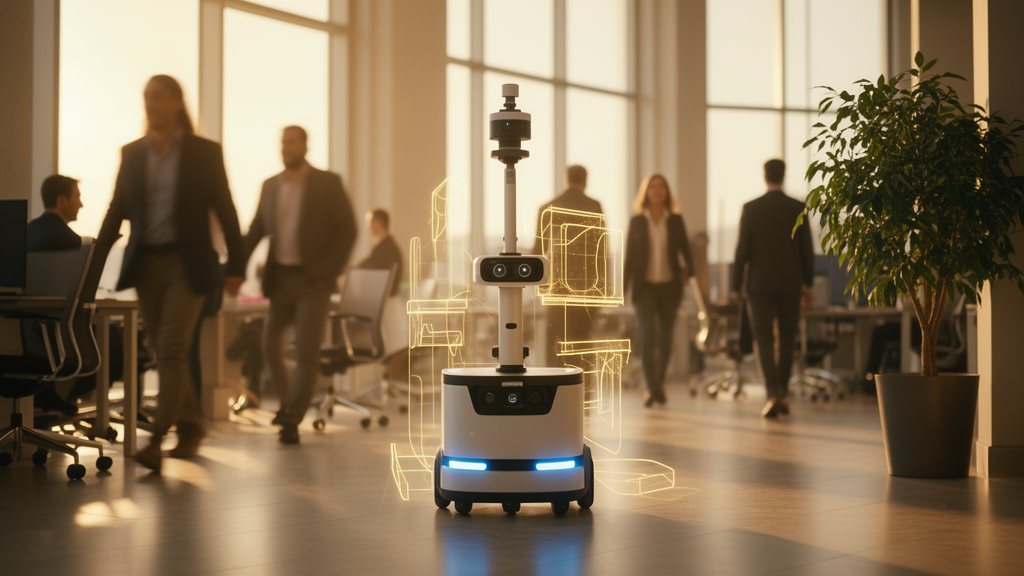
Robots that build maps from camera images face a stubborn problem: the world refuses to hold still. Walking people, passing cars, and shifting furniture inject observations that violate the static-scene assumption underlying visual simultaneous localization and mapping, or VSLAM, corrupting both camera-pose estimates and the maps built from them. A new system called EVS-SLAM, described in the journal Autonomous Robots, tackles this challenge with an architecture designed specifically for the constrained computers that ride aboard autonomous robots rather than for data-center GPUs.

EVS-SLAM is a modular RGB-D and stereo VSLAM system built to run on an NVIDIA Jetson AGX Xavier, an embedded companion computer common in mobile robotics. Its key component is DeepLabV3-ResNet50-EO, a deployment-adapted implementation of the DeepLabV3 semantic segmentation network with a ResNet50 backbone. The segmentation masks classify ORB feature observations as either static or potentially dynamic.

Potentially dynamic observations are excluded before feature matching, camera-pose estimation, and map construction, so moving objects never contaminate the geometric calculations that keep a robot's estimated trajectory aligned with reality. Evaluation on the KITTI and TUM benchmarks showed trajectory accuracy competitive with representative dynamic-scene VSLAM systems. The most striking results came from a controlled ablation on the same hardware platform: jointly enabling semantic segmentation and dynamic-feature filtering reduced the mean absolute trajectory error, measured as RMSE, by 92.84 to 97.42 percent on the TUM RGB-D walking sequences, where people stride through the camera's field of view.

Outdoors, the picture was more nuanced. On selected KITTI stereo sequences, the absolute pose error RMSE changed by amounts ranging from a 5.72 percent improvement to a 1.93 percent degradation, and those shifts were comparable to run-to-run variability. The authors conclude that the benefit of dynamic filtering is scene-dependent, a candid assessment that matters for anyone planning deployments in environments where motion is occasional rather than constant.

Speed is where embedded systems live or die, and EVS-SLAM posts credible numbers. Concurrent CPU-GPU execution yielded effective processing throughputs of 13.76 frames per second on KITTI and 19.20 frames per second on TUM. Notably, the dynamic-feature filtering step itself accounted for less than 1 percent of total latency, meaning the semantic screening adds little overhead to the real-time pipeline even though it reshapes which observations reach the estimator.

Beyond benchmarks, the team demonstrated onboard operation in qualitative real-world deployments spanning indoor scenes, urban streets, and parking lots, showing that the pipeline runs on the target hardware in conditions robots actually encounter.

Subject of Research: A lightweight visual SLAM system using semantic segmentation for autonomous robots in dynamic environments

Article Title: EVS-SLAM: a lightweight visual SLAM system for autonomous robots in dynamic environments

Article References: Moreno, L., Moreno, H. A., & Flores, G. (2026). EVS-SLAM: a lightweight visual SLAM system for autonomous robots in dynamic environments. Autonomous Robots, 50(4), Article 46. https://doi.org/10.1007/s10514-026-10273-4

Image Credits: AI Generated

DOI: 10.1007/s10514-026-10273-4

Keywords: visual SLAM, semantic segmentation, dynamic environments, autonomous robots, embedded computing, NVIDIA Jetson, ORB features, KITTI benchmark, TUM RGB-D, trajectory estimation, RGB-D camera, robotics

News Source: Denise Maddox. (October 26, 2026). Lightweight SLAM System Helps Robots Navigate Crowded, Changing Scenes. Scienmag.
Tags: Autonomous robotsDynamic environmentsembedded computingKITTI benchmarkNVIDIA JetsonORB featuresRGB-D cameraRoboticssemantic segmentationtrajectory estimationTUM RGB-Dvisual SLAM
Share12Tweet7Share2ShareShareShare1

Related Posts

Cheaper inertial sensors could match high-end units for onboard railway track inspection

Cheaper inertial sensors could match high-end units for onboard railway track inspection

October 26, 2026
Dirac buffer layers reshape topological terahertz laser cavities for power and robustness

Dirac buffer layers reshape topological terahertz laser cavities for power and robustness

October 26, 2026

New probabilistic tool reads Milankovitch cycles to date ancient sediments

October 26, 2026

Cyclodextrin Hydrogels Deliver Skin-Brightening Actives and Antifungal Protection in One Formulation

October 26, 2026

POPULAR NEWS

  • Four New Lepiota Mushroom Species Uncovered in Hebei Province, China

    Four New Lepiota Mushroom Species Uncovered in Hebei Province, China

    29 shares
    Share 12 Tweet 7
  • Spermidine and CaSPDS gene sustain salt tolerance in pepper seedlings

    29 shares
    Share 12 Tweet 7
  • Cheaper inertial sensors could match high-end units for onboard railway track inspection

    29 shares
    Share 12 Tweet 7
  • Sea ice supplies carbon equal to 14.7% of ice-edge phytoplankton production

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Four New Lepiota Mushroom Species Uncovered in Hebei Province, China

Spermidine and CaSPDS gene sustain salt tolerance in pepper seedlings

Cheaper inertial sensors could match high-end units for onboard railway track inspection

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 85 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.