…
…
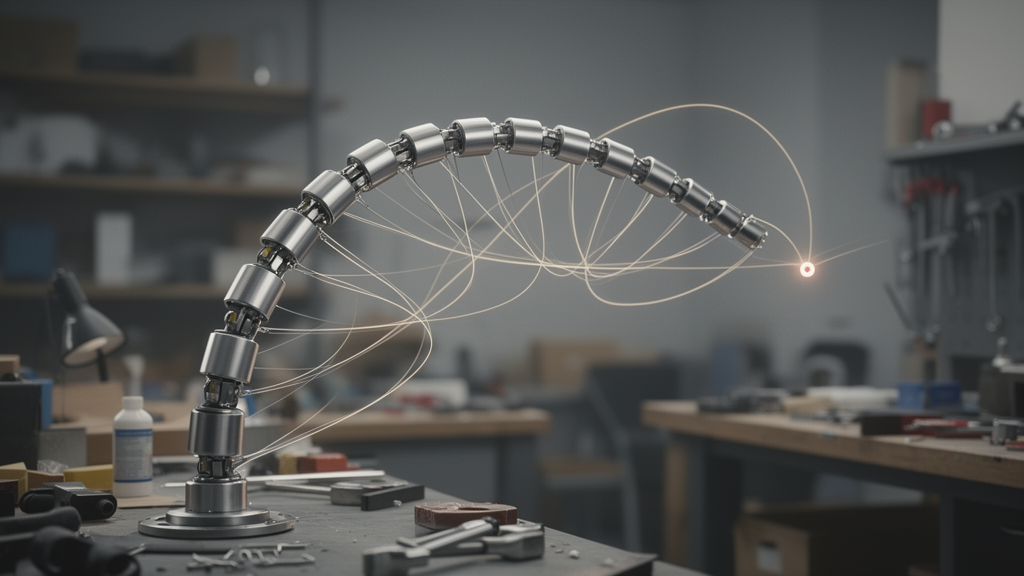
The difficulty of inverse kinematics for cable-driven continuum robots stems from a fundamental property of their geometry: the mapping from actuator space to task space is many-to-one. Because a three-section robot can bend each of its segments independently, an almost infinite family of internal configurations can place the tip at the same Cartesian point while producing different cable tensions, different orientations, and different clearance margins with respect to nearby obstacles. Classical analytical inversion struggles with this redundancy, and numerical approaches can converge to solutions that are mathematically acceptable yet physically awkward, for example configurations with abrupt curvature transitions between adjacent sections or cable-length distributions that demand excessive actuation effort. The framework described in the study addresses this by refusing to treat inverse kinematics as a pure point-matching problem. Instead, every candidate solution is judged by an aggregate score that simultaneously weighs how consistent the reconstructed arc lengths are, how precisely the end-effector orientation matches the target, how evenly the cable lengths are distributed, how smoothly the sections transition into one another, how much actuation effort the configuration requires, and whether any geometric or obstacle constraint is violated. This multi-objective formulation effectively converts an underdetermined kinematic problem into a constrained search over a well-defined feasibility landscape.
The piecewise-constant-curvature assumption underlying the forward model deserves particular attention, because it is the backbone of the entire computational pipeline. Under this assumption, each section of the robot is approximated as a circular arc with constant curvature, and the full body is obtained by concatenating homogeneous transformation matrices for the three arcs. This simplification, which has been refined over two decades of continuum-robotics research, is what makes the forward map fast enough to be evaluated thousands of times inside a population-based optimizer. A single forward evaluation yields not only the tip position but also the intermediate section frames, the implied cable lengths for each actuation channel, and the geometric quantities needed to test obstacle clearance. The trade-off is well known: piecewise-constant-curvature models neglect shear, extension, and the load-dependent deflection of the backbone, so their predictions can drift under external forces or friction in the cable-routing disks. The authors position their method accordingly, noting that higher-fidelity kinetostatic formulations remain the tool of choice when force equilibrium and non-ideal transmission effects must be resolved, while the fast model serves the inverse-kinematic search where many evaluations per second are the binding constraint.
The hybrid optimizer at the core of the study, DA-IHHO-DELS, illustrates a broader trend in computational intelligence: rather than betting on a single metaheuristic, modern solvers compose complementary search mechanisms so that exploration and exploitation are handled by different operators. Harris hawks optimization, which mimics the cooperative surprise-pounce behavior of hawks hunting rabbits, provides the exploratory backbone. Differential evolution contributes mutation and crossover operators that are particularly effective at refining solutions within a promising basin. Grey-wolf-style leader guidance biases the population toward the best solutions found so far, while opposition-based learning generates mirrored candidate points to escape premature convergence. Cauchy and Levy flights introduce occasional long-range jumps with heavy-tailed step distributions, a mechanism known to help populations escape local optima in rugged landscapes. Finally, a bounded local refinement stage polishes the best candidates within a restricted neighborhood. The design-aware seeding component is arguably the most distinctive element: instead of initializing the population randomly, the algorithm seeds candidates using the analytical geometry of the robot, so that the search starts from configurations that are already approximately feasible. This matters because metaheuristic performance is notoriously sensitive to initialization, and in a kinematic problem with many infeasible regions, starting near the feasible manifold can dramatically shorten the path to a high-quality solution.
The comparison against ten established algorithms is a methodologically important aspect of the work. Genetic algorithms, artificial bee colony, ant colony optimization, differential evolution, Harris hawks optimization, teaching-learning-based optimization, butterfly optimization, grey wolf optimizer, whale optimization algorithm, and pelican optimization algorithm each embody a different metaphor and a different balance between global exploration and local exploitation. By running all of them on the same obstacle-constrained inverse-kinematic tasks, the study provides a controlled setting in which the added value of the hybrid composition can be isolated. The reported numbers are notable: a median arc-length consistency residual of 0.00491 millimeters, a median reconstructed Cartesian error of 0.00255 millimeters, a one hundred percent success rate under the strict criterion that the residual remain below 0.01, the lowest median aggregate score among all competitors, and a mean runtime of roughly 0.57 seconds per solve. For context, sub-millimeter and even sub-hundredth-of-a-millimeter consistency in a simulated kinematic reconstruction indicates that the optimizer is essentially exhausting the numerical precision of the forward model rather than being limited by search quality. The sub-second runtime is equally significant, because inverse kinematics for continuum robots is often needed inside control loops or planning pipelines where solve latency directly affects usability.
The two-obstacle scenario embedded in the simulation deserves comment as well. Obstacle avoidance transforms inverse kinematics from a smooth optimization into a problem with discontinuous feasible regions, since a configuration is either collision-free or not, and small changes in section curvatures can flip a candidate from feasible to infeasible. Metaheuristics handle such landscapes more gracefully than gradient-based methods, which is one reason population-based search is a natural fit for continuum robots operating in cluttered environments such as minimally invasive surgical passages, confined industrial inspection routes, or crowded laboratory assemblies. The obstacle-handling terms in the aggregate score penalize candidates that approach or intersect the forbidden volumes, steering the population toward configurations that thread the robot between the obstacles while still meeting the tip-pose target. This coupling of geometric feasibility with kinematic accuracy in a single scalarized objective is what allows the optimizer to return solutions that are simultaneously precise and physically deployable in principle.
The secondary benchmark using measured actuator lengths from the CBHA/Robotino XT platform adds an important layer of external validity. The CBHA, a commercially available continuum manipulator with cable actuation, provides real cable-length data that can be fed into the same geometry-guided optimization machinery. The purpose of this benchmark is not to claim that the specific three-section robot studied in simulation was physically driven by the algorithm, an important distinction the authors make explicitly, but rather to test whether the consistency-seeking behavior of the optimizer transfers to data generated by a real device with real tolerances, real cable-routing geometry, and real measurement noise. The fact that the framework remains effective on measured data suggests that the design-aware formulation is not overfitted to the idealized simulation model. At the same time, the authors are careful to note that this is a consistency-transfer test, not a closed-loop hardware validation, which is an honest boundary on the claims.
From a broader perspective, the study sits at the intersection of two research communities that have historically progressed along separate tracks. The continuum-robotics community has developed increasingly sophisticated analytical models, from constant-curvature kinematics through geometrically exact formulations and kinetostatic analyses that account for cable friction and external loading. The computational-intelligence community has produced a rich catalogue of population-based optimizers, each with its own strengths on particular problem classes. Bridging these tracks requires careful engineering: the optimizer must respect the physical structure of the kinematic model, the seeding must encode geometric insight, and the objective must encode what practitioners actually care about, namely accuracy, smoothness, effort, and safety. The DA-IHHO-DELS framework is a concrete instance of this bridging, and its reported dominance over ten baselines in a regenerated obstacle-constrained benchmark offers evidence that the composition is more than the sum of its parts.
Several directions follow naturally from this work. The piecewise-constant-curvature forward model could be replaced or augmented with load-aware kinetostatic models when external forces are significant, and the optimizer architecture is largely agnostic to the specific forward map it searches over. The obstacle representation could be extended from simple geometric volumes to sensor-derived environment maps, enabling deployment in genuinely unstructured settings. The runtime, already under a second, could be further reduced through parallel evaluation of the population, since metaheuristic fitness assessments are embarrassingly parallel. Finally, closing the loop with physical hardware, using the optimizer inside a real-time controller with feedback from cable encoders or shape sensors, remains the decisive next step for translating simulation-level precision into demonstrated robotic capability. The present study provides the algorithmic foundation and the benchmarking discipline upon which such hardware-in-the-loop validation can be built.
Subject of Research: A new hybrid optimization intelligence for cable-driven continuum robot motion: two-obstacle simulation and real-data assessment
Article Title: A new hybrid optimization intelligence for cable-driven continuum robot motion: two-obstacle simulation and real-data assessment
Article References: Djeffal, S., Ghoul, A., Morakchi, M. R., Bendriss, B., Salah, M. E., & Chibani, A. (2026). A new hybrid optimization intelligence for cable-driven continuum robot motion: two-obstacle simulation and real-data assessment. Frontiers in Robotics and AI, 13, Article 1935721. https://doi.org/10.3389/frobt.2026.1935721
Image Credits: AI Generated
DOI: 10.3389/frobt.2026.1935721
Keywords: hybrid, optimization, intelligence, cable-driven, continuum, robot, motion, two-obstacle, simulation, real-data, assessment, scientific research
News Source: Denise Maddox. (October 16, 2026). Hybrid optimizer cracks the inverse kinematics puzzle of cable-driven continuum robots. Scienmag.