The Rubik’s Cube has spent half a century as the world’s most famous puzzle, a dizzying lattice of twisting faces and billions of possible states. Now a team of mechanical engineers in China has flattened it. In a study published in the journal Mechanical Sciences, Dabao Fan of Suqian University and colleagues introduce the planar prismatic Rubik’s cube mechanism, or PPRCM, a machine that captures the cube’s reconfigurable spirit while confining every moving part to a single plane. The work is more than a playful homage to Ernő Rubik’s 1974 invention: it delivers a formal theory for how such mechanisms are built, how they move, and how entirely new versions can be systematically designed.
The core idea is deceptively simple. Where the classic cube relies on intricate spatial axis layouts and intersecting revolute joints, the PPRCM replaces rotation with pure translation. Its rigid components slide along grooves machined into a flat base, arranged in a grid reminiscent of the sliding-tile puzzles that have entertained generations. The researchers point out that this planar constraint is a genuine engineering advantage: planar mechanisms are far easier to actuate, analyze, and manufacture than their spatial counterparts, because theoretical derivation and numerical calculation are dramatically simplified when all motion happens in two dimensions.
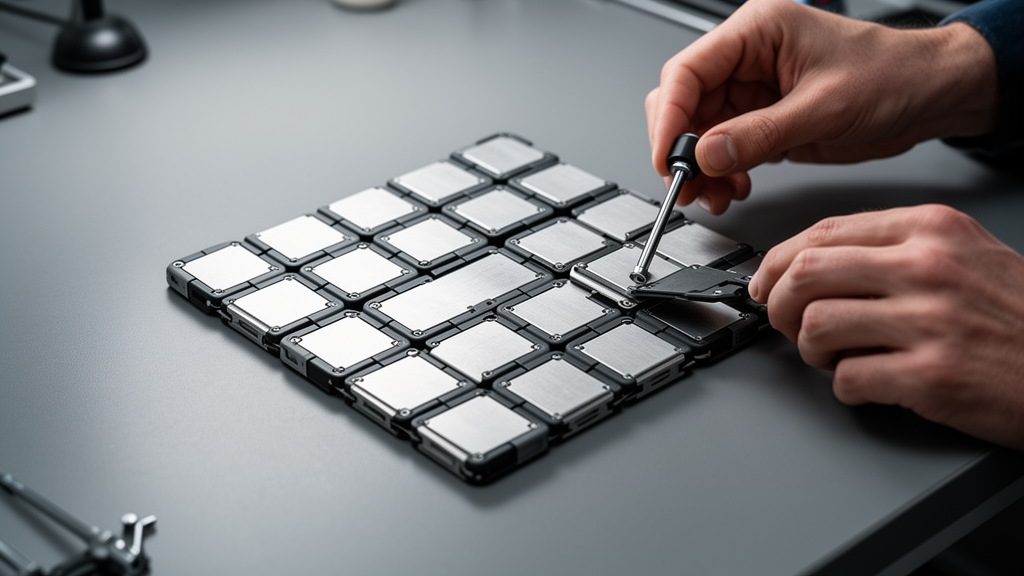
The team built their theory around a physical prototype, also rendered as a three-dimensional printed model, consisting of a base and three distinct moving modules. The base carries uniformly distributed grooves along two perpendicular directions, allowing the modules to translate along either axis. The design borrows from an unexpectedly ancient source: the tenon-and-mortise joints of traditional Chinese woodworking, which inspired the groove-and-pin interlocking scheme that dynamically connects modules to the base. Six moving paths run along each direction, giving the mechanism a rich lattice of possible trajectories.
Each moving module is itself a layered assembly. It contains a moving block together with moving-block side pieces, or MBSPs, fitted with clamping pins that keep the assembly engaged in the base grooves during translation. The side pieces also carry their own internal grooves, which lock the moving block onto them when it slides along the horizontal direction. This creates three distinct motion modes: a module can translate along one axis, along the perpendicular axis, or the inner block can slide along the horizontal direction on top of its own side pieces. Because the contact surfaces differ between the first two modes and the third, the third mode offers the richest design possibilities, and the researchers chose it as the focus of their theoretical analysis.
That analysis centers on a concept the authors call the prismatic-pair contact surface, or PPCS. A prismatic pair is the fundamental sliding joint of mechanism theory, permitting exactly one translational degree of freedom between two components. The PPCS is the direct contact area between those components, and because it is generated by extruding a two-dimensional profile along the direction of motion, it can be uniquely described by a single profile equation in a cross-sectional coordinate system. The researchers classify these surfaces as symmetric or asymmetric depending on whether a plane of symmetry parallel to the motion exists, and they restrict their formal treatment to the symmetric case for clarity.
From this foundation, the team derived the conditions under which components can actually swap positions and reconfigure the mechanism. Three rules emerge. First, components must share identical movement slopes, meaning only parts translating along the same axis are mutually interchangeable. Second, the contact surfaces must satisfy an inclusivity requirement: a moving component can slide on a fixed component only if the fixed component’s profile contains the mover’s profile, a relationship the authors express mathematically and prove to be transitive. Third, the mechanism must contain at least two intersecting movement directions, because with only one direction all motion is parallel and no component can ever move in two ways, which would make reconfiguration impossible.
These conditions feed directly into the paper’s central contribution: a type synthesis method for the PPRCM. Type synthesis is the branch of mechanism theory concerned with enumerating the structural forms a machine can take, independent of its exact dimensions. The method proceeds in four steps: choose the number of movement directions, choose how many parallel moving paths exist in each direction, choose the types of contact surfaces in each direction, and finally design a base on which all movable components can be placed. Because these three factors, direction count, path count, and surface type, fully determine the mechanism’s topology, specifying their values generates a complete family of distinct PPRCM designs.
To demonstrate the method’s power, the authors worked through systematic case studies. They generated configurations with two, three, and even four different movement slopes, including versions whose directions are not perpendicular but angled at 45 degrees, showing that the theory accommodates non-orthogonal grids. They varied the number of moving paths per direction from two up to six, and they swapped in different sets of contact-surface profiles with different inclusivity hierarchies. For every synthesized configuration, corresponding three-dimensional models were constructed to validate that the designs are geometrically rational and mechanically effective, confirming that the method reliably produces working reconfigurable mechanisms rather than paper abstractions.
The significance extends well beyond puzzle-inspired novelty. Rubik’s cube mechanisms have already been combined with origami structures, deployable space hardware, and modular robots, and cube-inspired mathematics underpins image encryption schemes, biometric template protection, microfluidic devices, and even deep-learning architectures that exploit the cube’s group structure. A planar version with a rigorous synthesis theory gives engineers a tractable starting point: it simplifies the cognitive and analytical difficulty of complex reconfigurable mechanisms and lays a foundation for extending the approach to fully three-dimensional spatial designs. Because reconfigurable machinery is central to deformable structures, adaptable robots, and variable working scenarios, a systematic recipe for generating new configurations is a valuable tool.
The authors also situate their work in a long intellectual lineage. Planar type synthesis has evolved from designers’ intuition into formal methods based on kinematic chain enumeration, finite group theory, Assur groups, matrix representations, and, more recently, neural-network and big-data approaches. Yet none of these established methods transfers directly to Rubik’s cube mechanisms, whose unique sliding, interlocking, and position-swapping behavior demands new theory. The PPRCM framework also echoes much older ideas about rearrangement: the authors trace the concept back to Luo Shu, the ancient Chinese symbolic numerical pattern embodying transformation and rearrangement, and to sliding puzzles such as the eight-digit game and the fifteen-puzzle, which are, in mechanism terms, planar prismatic systems. By formalizing what those puzzles do intuitively, the study enriches planar mechanism theory and opens a path toward a new generation of flat, reconfigurable machines whose configurations can be counted, predicted, and designed on demand.
Subject of Research: Reconfigurable kinematic analysis and type synthesis of planar prismatic Rubik's cube mechanisms
Article Title: Research on reconfigurable kinematic analysis and type synthesis of planar prismatic Rubik's cube mechanism
Article References: Fan, D., Zeng, D., Zhao, Y., Feng, H., Deng, Y., & Liu, Y. (2026). Research on reconfigurable kinematic analysis and type synthesis of planar prismatic Rubik's cube mechanism. Mechanical Sciences, 17(2), 813-823. https://doi.org/10.5194/ms-17-813-2026
Image Credits: AI Generated
Keywords: reconfigurable mechanisms, Rubik's cube mechanism, type synthesis, planar mechanism, prismatic pair, kinematics, topology, mechanism design, sliding puzzle, metamorphic mechanism, mechanical sciences, 3D printed prototype
News Source: Denise Maddox. (October 9, 2026). Rubik’s Cube Logic Goes Flat: New Reconfigurable Mechanism Rewrites Planar Machine Design. Scienmag.