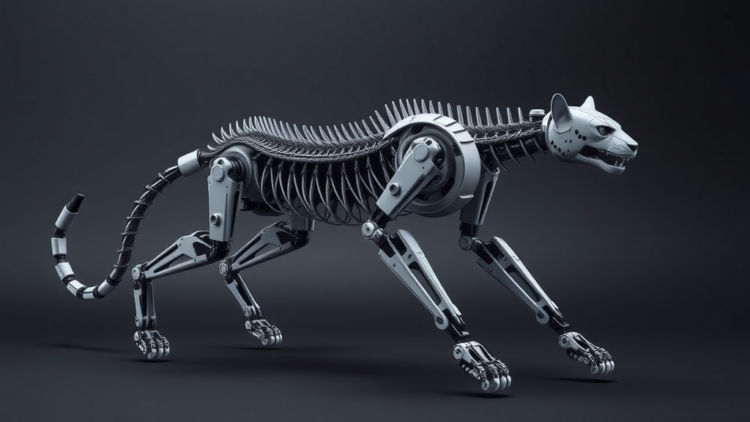
When a cheetah sprints across the savanna, its spine flexes and extends with every stride, storing and releasing elastic energy like a living spring. That remarkable biomechanical trick has long eluded roboticists, whose four-legged machines—from Boston Dynamics’ Spot to MIT’s Cheetah and ETH Zurich’s ANYmal—still lumber along on rigid torsos. Now, a team of researchers in China has built a bendable robotic spine inspired by quadruped anatomy that can carry more than three times the load reported for comparable tendon-driven continuum designs, bringing truly agile, animal-like locomotion one step closer.
The new device, described in the journal Results in Engineering, is a tendon-driven continuum robotic spine developed by Jingwei Ke and colleagues. Continuum robots, which deform smoothly along their entire length rather than hinging at discrete joints, offer theoretically infinite degrees of freedom. That makes them ideal mimics of biological spines, but it comes with a notorious weakness: they are typically too floppy to bear significant loads or hold their position accurately when something pushes on them. The team’s solution is a hybrid architecture that marries rigid and compliant elements into a modular, load-capable structure.
At the heart of the design are cross-universal joints placed between adjacent spacer discs. Unlike a conventional central elastic backbone, such as a flexible nickel-titanium rod, these joints grant two degrees of rotational freedom while actively resisting axial twisting. Torsional rigidity has been a persistent Achilles heel of continuum robots; under asymmetric loading, flexible backbones tend to twist unpredictably, wrecking positioning accuracy. By embedding discrete cross-coupled joints along the central neutral axis, the researchers established a robust torsional load-bearing skeleton that keeps the structure aligned even when forces push unevenly on its sides.
Surrounding this skeleton, pre-compressed coil springs are distributed symmetrically around the spine’s periphery, directly inspired by the elastic muscle-tendon units of a cheetah’s back. These passive springs provide stabilizing restoring forces that reduce the peak motor torque needed during load-bearing movements, and they decouple heavy compressive actuation loads from the bending deformation of the joints. That decoupling prevents the structural buckling that plagues standard continuum backbones under heavy loading. Each spring is guided by a sleeve to stop it buckling sideways during compression, and its stiffness can be tuned for different applications—a design flexibility the team says allows engineers to trade compliance against load capacity as needed.
The spine itself measures 230 millimeters long and 160 millimeters in diameter, and bends in two degrees of freedom: sagittal flexion and extension, plus lateral bending—the two dominant posture-adaptation modes seen in legged animals. Three flexible wire ropes, each 3 millimeters thick and arranged 120 degrees apart around the central axis, drive the deformation. The three-tendon layout enables full spatial bending while avoiding the extra weight and complexity of a four-tendon system. In the laboratory prototype, three DJI M3508 motors turn ball screws that precisely lengthen or shorten the tendons, though the authors acknowledge that more compact actuators, such as pulley-based routing or twisted-string mechanisms, would be needed before the spine could ride on an actual walking robot.
Modeling such a structure is fiendishly difficult. Conventional constant-curvature models assume the whole spine bends uniformly, which collapses under real-world loads where segments deform non-uniformly. More sophisticated approaches, like Cosserat rod theory, capture that complexity but require solving computationally expensive boundary value problems. The researchers instead developed a unified static model based on Newton–Euler equations, which treats each spacer disc individually and computes its rotation from local force and moment balance. Crucially, they incorporated a Coulomb friction model describing the interaction between tendons and their guide holes—a factor earlier versions of the work had ignored entirely—with a friction coefficient of 0.3 drawn from reported values for steel cables sliding against polymer sheaths.
The framework also captures the fundamental coupling that makes loaded continuum robots so hard to control: the actuation forces, structural deformation, and external loads all influence one another simultaneously. Because the resulting equations are highly nonlinear and actuation is redundant—three tendons controlling two degrees of freedom—the team solved them numerically, minimizing the sum of tendon tensions subject to static equilibrium constraints. A single solve completes in under one second on an ordinary desktop computer, a computational budget that leaves room for real-time control in a way that Cosserat rod formulations cannot match. Simulations confirmed what the experiments would later show: under load, adjacent segments bend by different amounts, a non-uniform profile the constant-curvature model simply cannot predict.
To choose the right springs, the team swept stiffness values of 10, 20, 30, and 40 newtons per millimeter in simulations with a 7.5-kilogram load. At 10 N/mm the spine deformed excessively, with roughly 10.5 degrees of angular deviation at the tip. At 20 N/mm, the spine achieved an average bending angle of 16.26 degrees across all directions with the best combination of compliance, stability, and solver efficiency, so that value was selected for the physical prototype. Experiments then put the spine through horizontal bending, vertical bending, and a full 360-degree circular trajectory at a 30-millimeter radius, all under a 7.5-kilogram external load while an eight-camera Nokov motion capture system with 0.5-millimeter precision tracked six reflective markers.
The results were striking. The maximum positional error measured was 10.10 millimeters—just 4.40 percent of the spine’s total length—during horizontal bending, with root-mean-square errors of 4.89, 5.68, and 3.96 millimeters for the circular, horizontal, and vertical trajectories respectively. For context, comparable tendon-driven continuum robots in the literature have been tested at loads ranging from 60 grams to 3.5 kilograms; this design withstood 7.5 kilograms while maintaining stable, controllable bidirectional bending. The authors caution that the comparison is contextual rather than a direct ranking, since the various robots differ in size, materials, and testing protocols, but the margin is nonetheless substantial.
The work remains deliberately scoped to quasi-static behavior: inertial forces, impacts, and vibrations during high-speed running are not yet modeled, and the test loads were applied at the spine’s tip rather than distributed through a robot’s torso and limbs as they would be in a complete quadruped. Still, the researchers report that a simplified version of the spine has already been integrated into a quadruped robot prototype, setting the stage for experiments on coordinated spine-limb control, gait performance, and energy efficiency. If those efforts succeed, the rigid-torso robots patrolling disaster zones and inspection sites today may one day move with the supple, spring-loaded grace of the animals that inspired this machine.
Subject of Research: Bio-inspired tendon-driven continuum robotic spine design for load-bearing quadruped robot applications
Article Title: Design and evaluation of a bio-inspired tendon-driven continuum robotic spine for quadruped applications
Article References: Ke, J., Yi, S., Liu, Y., Liu, S., Lei, F., Gu, X., & Guo, Z. (2026). Design and evaluation of a bio-inspired tendon-driven continuum robotic spine for quadruped applications. Results in Engineering, 32, Article 113064. https://doi.org/10.1016/j.rineng.2026.113064
Image Credits: AI Generated
DOI: 10.1016/j.rineng.2026.113064
Keywords: quadruped robots, continuum robots, robotic spine, bio-inspired design, tendon-driven actuation, Newton-Euler model, cross-universal joints, compression springs, load-bearing, cheetah biomechanics, static modeling, locomotion
Cite Scienmag News
APA MLA Chicago
Denise Maddox. (September 25, 2026). Robotic Spine That Bends Like a Cheetah’s Could Supercharge Quadruped Robots. Scienmag. https://scienmag.com/robotic-spine-that-bends-like-a-cheetahs-could-supercharge-quadruped-robots/
Denise Maddox. “Robotic Spine That Bends Like a Cheetah’s Could Supercharge Quadruped Robots.” Scienmag, 25 September 2026, https://scienmag.com/robotic-spine-that-bends-like-a-cheetahs-could-supercharge-quadruped-robots/. Accessed 25 September 2026.
Denise Maddox. “Robotic Spine That Bends Like a Cheetah’s Could Supercharge Quadruped Robots.” Scienmag. September 25, 2026. https://scienmag.com/robotic-spine-that-bends-like-a-cheetahs-could-supercharge-quadruped-robots/
Copy citation Download RIS
Tags: animal-inspired robot biomechanicsbio-inspired designbio-inspired robotic mobilitybiomimetic robotic spinecheetah biomechanicscompression springscontinuum robot degrees of freedomcontinuum robotscross-universal jointselastic energy storage in robotsflexible robotic spine designload-bearingload-bearing robotic structureslocomotionmodular hybrid robotic architectureNewton-Euler modelquadruped robot agility enhancementquadruped robot locomotionquadruped robotsrobotic spinerobotic spine flexibility and strengthstatic modelingtendon-driven actuationtendon-driven continuum robots