• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Friday, November 20, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Beaver-inspired algorithm optimizes mobile robot path planning

by
November 20, 2026
in Technology
Reading Time: 2 mins read
0
Beaver-inspired algorithm optimizes mobile robot path planning

Beaver-inspired algorithm optimizes mobile robot path planning

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

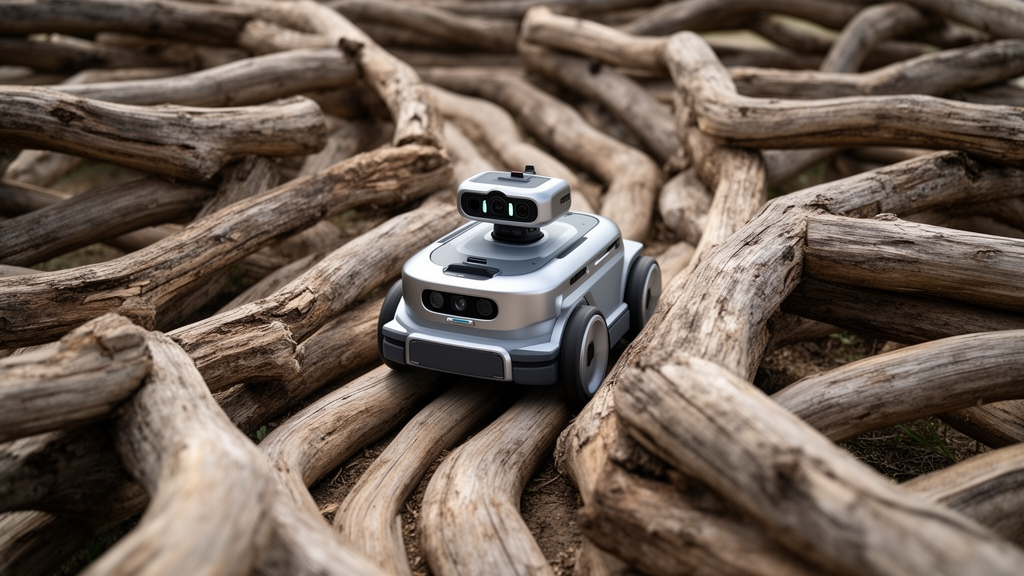
Researchers have introduced a novel bio-inspired optimization method known as the Beaver Optimization Algorithm, or BOA, designed to address the complex challenges of mobile robot path planning. The study, published in the Journal of Intelligent & Robotic Systems, presents a mathematical model derived from the adaptive behaviors of beavers in their natural aquatic habitats.

The development of the BOA stems from the observation that beavers exhibit distinct flexibility and efficiency in key survival activities, including feeding, reproduction, and predator evasion. The research team modeled these dynamic behaviors, focusing specifically on den construction and food foraging. The core of the algorithm involves three primary simulated behaviors: den migration, localized foraging, and random hiding strategies.

These simulated behaviors are translated into specific mechanisms that offer feasible solutions for various optimization tasks.

To evaluate the efficacy of the BOA, the authors conducted rigorous testing against 23 standard benchmark functions. The BOA was compared against several prominent nature-inspired algorithms, including particle swarm optimization and genetic algorithms. The results indicated that the BOA outperformed many of these established algorithms on the majority of the benchmark functions, suggesting a strong potential for general application in optimization tasks.

Building on the success of the single-objective BOA, the paper also presents a strategy for handling multi-objective optimization problems. This extension led to the development of the Multi-Objective Beaver Optimization Algorithm, or MOBOA. The MOBOA was tested on multi-objective benchmark functions and compared against four other multi-objective algorithms. The results demonstrated that MOBOA exhibited superior performance in these scenarios.

The application of the BOA to mobile robot path planning was explored in detail to validate its practical feasibility. The algorithm successfully optimized path lengths in a constructed model environment. This validation was supported by comparative analysis with other methods, confirming the effectiveness of the BOA in this specific domain.

Furthermore, the MOBOA showed promising results in addressing multi-objective path planning challenges for robots. In these challenges, multiple factors such as path length, energy efficiency, and safety must be simultaneously optimized.

In conclusion, the Beaver Optimization Algorithm and its multi-objective counterpart represent innovative approaches in the field of bio-heuristic optimization. Their application to complex problems like mobile robot path planning underscores their potential in providing efficient and effective solutions across various domains.

Subject of Research: Bio-inspired optimization algorithm for mobile robot path planning

Article Title: Beaver Optimization Algorithm: A New Bio-inspired Optimizer for Mobile Robot Path Planning Problems

Article References: Zhang, J., Liu, C., Sun, H., Geng, N., & Song, B. (2026). Beaver Optimization Algorithm: A New Bio-inspired Optimizer for Mobile Robot Path Planning Problems. Journal of Intelligent & Robotic Systems, 112(4), Article 97. https://doi.org/10.1007/s10846-026-02407-8

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02407-8

Keywords: Beaver Optimization Algorithm, Mobile Robot Path Planning, Bio-inspired Optimization, Multi-objective Optimization, Particle Swarm Optimization, Genetic Algorithms, Robotics, Path Planning, Nature-inspired Algorithms, Journal of Intelligent & Robotic Systems, Den Migration, Localized Foraging, Random Hiding Strategies, Benchmark Functions, Energy Efficiency, Safety Optimization, Aquatic Environments, Predator Evasion, Feeding Behaviors, Reproduction Behaviors

News Source: Denise Maddox. (November 20, 2026). Beaver-inspired algorithm optimizes mobile robot path planning. Scienmag.
Tags: Aquatic EnvironmentsBeaver Optimization Algorithmbenchmark functionsbio-inspired optimizationDen Migrationenergy efficiencyfeeding behaviorsgenetic algorithmsJournal of Intelligent & Robotic SystemsLocalized Foragingmobile robot path planningMulti-objective optimizationNature-inspired algorithmsparticle swarm optimizationpath planningpredator evasionRandom Hiding StrategiesReproduction BehaviorsRoboticsSafety Optimization
Share12Tweet7Share2ShareShareShare1

Related Posts

Machine Learning and Microgrid Simulation Optimize Off-Grid Moroccan Rural Electrification

Machine Learning and Microgrid Simulation Optimize Off-Grid Moroccan Rural Electrification

November 20, 2026
Seawater Immersion Weakens Thick Four Layer Carbon Fiber Cylinders More Than Thinner Tubes

Seawater Immersion Weakens Thick Four Layer Carbon Fiber Cylinders More Than Thinner Tubes

November 20, 2026

Scheduled Prompts From Collaborative Robots Increase Human Trust in Virtual Trials

November 20, 2026

Salt Incorporation Alters Electrical and Thermal Dynamics in Glycine Composites

November 20, 2026

POPULAR NEWS

  • Cardiovascular Review Examines Microplastics Evidence Across Human Tissues and Coronary Disease

    Cardiovascular Review Examines Microplastics Evidence Across Human Tissues and Coronary Disease

    29 shares
    Share 12 Tweet 7
  • New Estimand Framework Clarifies Model Validation and Data Splitting in Predictive Modelling

    29 shares
    Share 12 Tweet 7
  • Rare Periorbital Inflammation Reported After Subconjunctival Mitomycin C in Glaucoma Procedures

    29 shares
    Share 12 Tweet 7
  • Hands-On Workshops Sharply Increase Livestock Stakeholder Foot-And-Mouth Disease Recognition in Puerto Rico

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Machine Learning and Microgrid Simulation Optimize Off-Grid Moroccan Rural Electrification

Cellular Maintenance System Failures Drive Systems-Level Neurodegeneration Across Brain Glial Networks

Survey Links Therapists’ Cognitive Assumptions to Body Exposure Practices in Eating Disorders

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 89 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.