• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Thursday, November 19, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Hybrid Bi-Level Algorithm Generates Shorter Multi-Target Paths in Autonomous Vehicles

by
November 19, 2026
in Technology
Reading Time: 2 mins read
0
Hybrid Bi-Level Algorithm Generates Shorter Multi-Target Paths in Autonomous Vehicles

Hybrid Bi-Level Algorithm Generates Shorter Multi-Target Paths in Autonomous Vehicles

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

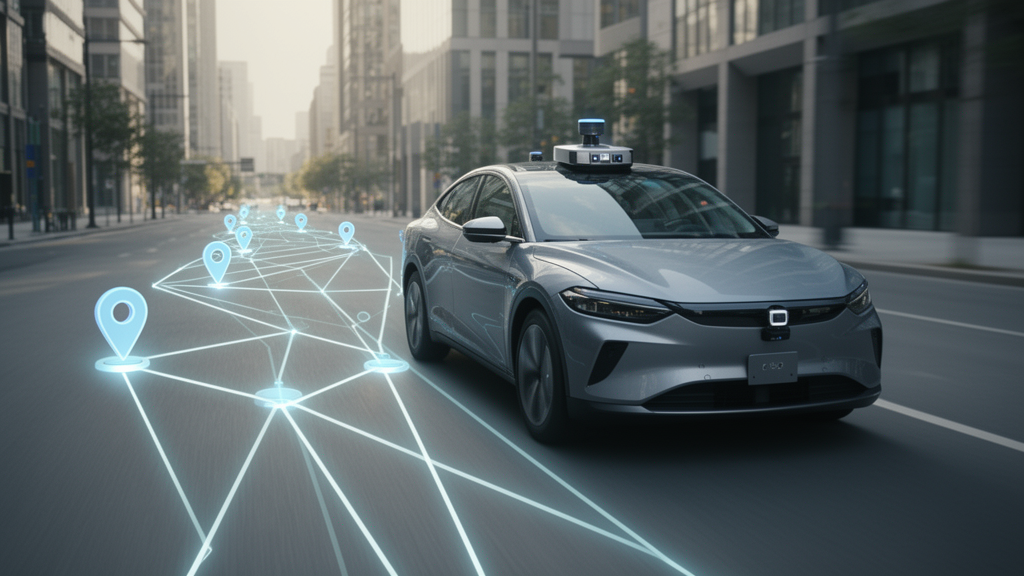
A hybrid bi-level algorithm designated HDOA-IA* integrates a hybrid dream optimization algorithm with an improved A* algorithm for multi-target path planning in autonomous vehicles. Multi-target path planning presents fundamental operational challenges in autonomous robotics because resolving the visitation order of targets must occur in conjunction with generating safe, obstacle-free paths across complex working environments.

The bi-level architecture separates the path-planning task into two distinct tiers. At the upper level, the framework employs a hybrid dream optimization algorithm, designated HDOA, to optimize the target visitation sequence. The upper-level HDOA integrates three specialized algorithmic mechanisms: a nearest-neighbor-based population initialization strategy, a path reset mechanism, and a variable neighborhood operator to search for optimal sequence arrangements.

At the lower level, the framework implements an improved A* algorithm, known as IA*, to construct collision-free travel paths between each sequenced target. The IA* algorithm combines a congestion-aware heuristic, any-angle planning, and Bézier-curve smoothing to generate collision-free paths.

To evaluate the optimization capability of the upper level, the researchers benchmarked HDOA on ten TSPLIB problem instances. The benchmark testing revealed that HDOA achieved error rates ranging between 0.67 percent and 8.95 percent across the ten instances. These evaluations demonstrated that the optimization algorithm maintained competitive solution quality across different problem sizes.

In direct path-planning experiments, the complete HDOA-IA* algorithm consistently generated shorter navigation routes across the tested complex environments. The recorded average path lengths ranged from 758.32 to 1376.26, while path variability remained low with standard deviations ranging between 8.59 and 24.16. These quantitative findings demonstrate the effectiveness of HDOA-IA* for multi-target path planning under the evaluated complex conditions.

Subject of Research: Autonomous vehicle multi-target path planning

Article Title: HDOA-IA*: A hybrid bi-level algorithm for multi-target path planning in autonomous vehicles

Article References: Fan, H., Lou, T., Zhang, Y., He, Z., Jiao, Y., & Li, L. (2027). HDOA-IA*: A hybrid bi-level algorithm for multi-target path planning in autonomous vehicles. Cluster Computing, 30(1), Article 49. https://doi.org/10.1007/s10586-026-06829-9

Image Credits: AI Generated

DOI: 10.1007/s10586-026-06829-9

Keywords: autonomous vehicles, multi-target path planning, autonomous robotics, HDOA-IA*, hybrid dream optimization algorithm, improved A* algorithm, target sequencing, collision-free path generation, bi-level algorithm, population initialization, path reset mechanism, variable neighborhood operator, congestion-aware heuristic, any-angle planning, Bézier-curve smoothing, TSPLIB benchmarking, trajectory planning

News Source: Denise Maddox. (November 19, 2026). Hybrid Bi-Level Algorithm Generates Shorter Multi-Target Paths in Autonomous Vehicles. Scienmag.
Tags: any-angle planningAutonomous RoboticsAutonomous VehiclesBézier-curve smoothingbi-level algorithmcollision-free path generationcongestion-aware heuristicHDOA-IA*hybrid dream optimization algorithmimproved A* algorithmmulti-target path planningpath reset mechanismpopulation initializationtarget sequencingtrajectory planningTSPLIB benchmarkingvariable neighborhood operator
Share12Tweet7Share2ShareShareShare1

Related Posts

Dual-Responsive Gold Nanoplatform Combines Chemo-Photothermal Action in Osteosarcoma Cells

Dual-Responsive Gold Nanoplatform Combines Chemo-Photothermal Action in Osteosarcoma Cells

November 19, 2026
Survey of Eighty-Eight Studies Reveals Severe Shortage in Amharic Conversational AI

Survey of Eighty-Eight Studies Reveals Severe Shortage in Amharic Conversational AI

November 19, 2026

Graphene Oxide and Thermodynamic Modeling Enhance Industrial Waste Alkali-Activated Materials

November 19, 2026

Acoustic Chaos and Entropy Metrics Track Laboratory Fatigue Damage in Asphalt Beams

November 19, 2026

POPULAR NEWS

  • No Metabolic Crises Occurred With Peripartum Dextrose in Small Observational Study

    No Metabolic Crises Occurred With Peripartum Dextrose in Small Observational Study

    29 shares
    Share 12 Tweet 7
  • Mental Health Emergency Visits in Saudi Arabia Surge During Late Autumn and Winter

    29 shares
    Share 12 Tweet 7
  • Rare APBA1 Genetic Variants Identified in Children with Severe Monogenic Obesity

    29 shares
    Share 12 Tweet 7
  • RNA Thermometer Controls Recombinant Protein Expression in Engineered Escherichia Coli Cultures

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Pediatric Critical Care Review Highlights Fluid Overload Risks and Stewardship Needs

Review Details How Gastrodin Protects Neurons in Experimental Parkinson’s Disease Models

Global Scoping Review Reveals Critical Gaps in Evaluating Surgical Task Sharing

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 89 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.