• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Thursday, November 19, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Adaptive Dual Quaternion Control Improves Small Drone Formation Tracking and Transitions

by
November 19, 2026
in Technology
Reading Time: 2 mins read
0
Adaptive Dual Quaternion Control Improves Small Drone Formation Tracking and Transitions

Adaptive Dual Quaternion Control Improves Small Drone Formation Tracking and Transitions

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

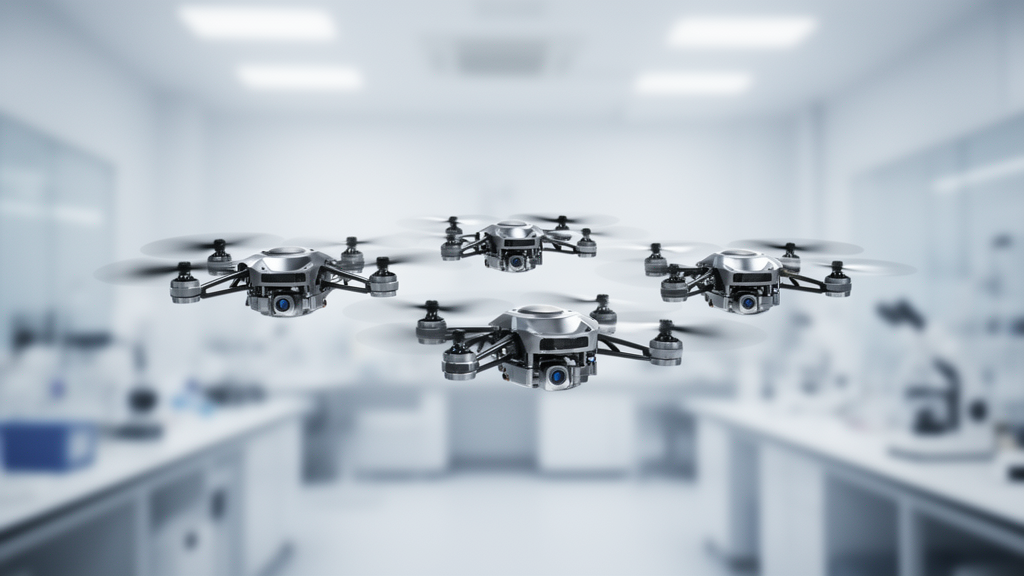
Researchers have developed a dual-quaternion-based control strategy designed for the coordinated formation flying of small unmanned aerial vehicle teams.

The framework utilizes a virtual structure to define the multirobot formation, establishing a unified and global representation of both the overall pose and the geometric variables that shape the team.

By employing dual quaternions, the system achieves a compact and singularity-free representation within SE(3), which enables the pose controller to function consistently even when the aerial formation undergoes large rotational motions or operates with only partially defined orientation.

Expanding upon existing dual-quaternion kinematic controllers, the formulation introduces two primary enhancements, beginning with a geometry-adaptive control law in which gains adjust online according to formation inertia, backed by stability guarantees extending the convergence results of fixed-gain controllers.

The second enhancement incorporates a partial dual-quaternion representation that permits the identical pose-control structure to govern formations with either fully or partially defined orientations, enabling seamless transitions between configurations, such as when an agent is lost and the group reduces to a smaller structure, without requiring a control law redesign.

Validation through simulations and experimental trials, including comparative studies and practical transition demonstrations, confirmed improved tracking performance and robustness under varying formation geometries.

Published on 18 September 2026 in the Journal of Intelligent and Robotic Systems, the open-access article was released early to accelerate access to accepted findings. The paper is citable, carries a permanent digital object identifier, and remains subject to minor editorial updates before being formally replaced by the final Version of Record.

Subject of Research: Adaptive dual-quaternion virtual structure control for small unmanned aerial vehicle formations

Article Title: Adaptive Multirobot Virtual Structure Control using Dual Quaternions

Article References: Giribet, J. I., Ghersin, A. S., Mas, I., Marciano, H. N., Dourado Villa, D. K., & Sarcinelli-Filho, M. (2026). Adaptive Multirobot Virtual Structure Control using Dual Quaternions. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02462-1

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02462-1

Keywords: dual quaternions, virtual structure, unmanned aerial vehicles, formation flying, multirobot systems, geometry-adaptive control, formation inertia, pose control, SE(3), kinematic controllers, partial dual quaternion, formation transitions, tracking performance, online gain adaptation, convergence results, stability guarantees

News Source: Denise Maddox. (November 19, 2026). Adaptive Dual Quaternion Control Improves Small Drone Formation Tracking and Transitions. Scienmag.
Tags: convergence resultsdual quaternionsformation flyingformation inertiaformation transitionsgeometry-adaptive controlkinematic controllersmultirobot systemsonline gain adaptationpartial dual quaternionpose controlSE(3)stability guaranteestracking performanceunmanned aerial vehiclesvirtual structure
Share12Tweet7Share2ShareShareShare1

Related Posts

PaDaWaN System Streamlines Heterogeneous Research Data Warehouses Across Diverse Disciplines

PaDaWaN System Streamlines Heterogeneous Research Data Warehouses Across Diverse Disciplines

November 19, 2026
Simulations Show Quantum Mixer Design Shapes Performance in Ternary Portfolio Optimization

Simulations Show Quantum Mixer Design Shapes Performance in Ternary Portfolio Optimization

November 19, 2026

Computational Analysis Reveals Site-Specific Molecular Water Hydration on Transition Metal Nitride Nanoribbons

November 19, 2026

Polypropylene Fibers Extend Alkali-Activated Slag Concrete Creep Lifetime by 156 Percent

November 19, 2026

POPULAR NEWS

  • Single-Cell Study Links SLC2A1-Driven Metabolism to Immune Evasion in Cholangiocarcinoma

    Single-Cell Study Links SLC2A1-Driven Metabolism to Immune Evasion in Cholangiocarcinoma

    29 shares
    Share 12 Tweet 7
  • Deubiquitinase DUB3 Stabilizes GCase and Reduces Neurodegeneration in Parkinson’s Disease Models

    29 shares
    Share 12 Tweet 7
  • HPV16 and HPV18 Infection Associated With High-Grade Cervical Lesions in Study

    29 shares
    Share 12 Tweet 7
  • Southeast Asian Wildlife Disease Surveillance Relies Predominantly on Passive Outbreak Tracking

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Covalently Anchored Titanium Coating Prolongs Local Minocycline Release in Laboratory Tests

Cobalt Clinoptilolite Outperforms Nickel Catalyst in Sodium Borohydride Hydrolysis Tests

Experimental ADC Micvotabart Pelidotin Shows Promise in Head and Neck Cancers

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 89 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.