• HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
Wednesday, November 18, 2026
BIOENGINEER.ORG
No Result
View All Result
  • Login
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
  • HOME
  • NEWS
  • EXPLORE
    • CAREER
      • Companies
      • Jobs
        • Lecturer
        • PhD Studentship
        • Postdoc
        • Research Assistant
    • EVENTS
    • iGEM
      • News
      • Team
    • PHOTOS
    • VIDEO
    • WIKI
  • BLOG
  • COMMUNITY
    • FACEBOOK
    • INSTAGRAM
    • TWITTER
No Result
View All Result
Bioengineer.org
No Result
View All Result
Home NEWS Science News Technology

Synchronized Sensing Quantifies Servo Tracking Across Reconfigurable Spherical Hexapod Mode Transitions

by
November 18, 2026
in Technology
Reading Time: 2 mins read
0
Synchronized Sensing Quantifies Servo Tracking Across Reconfigurable Spherical Hexapod Mode Transitions

Synchronized Sensing Quantifies Servo Tracking Across Reconfigurable Spherical Hexapod Mode Transitions

Share on FacebookShare on TwitterShare on LinkedinShare on RedditShare on Telegram

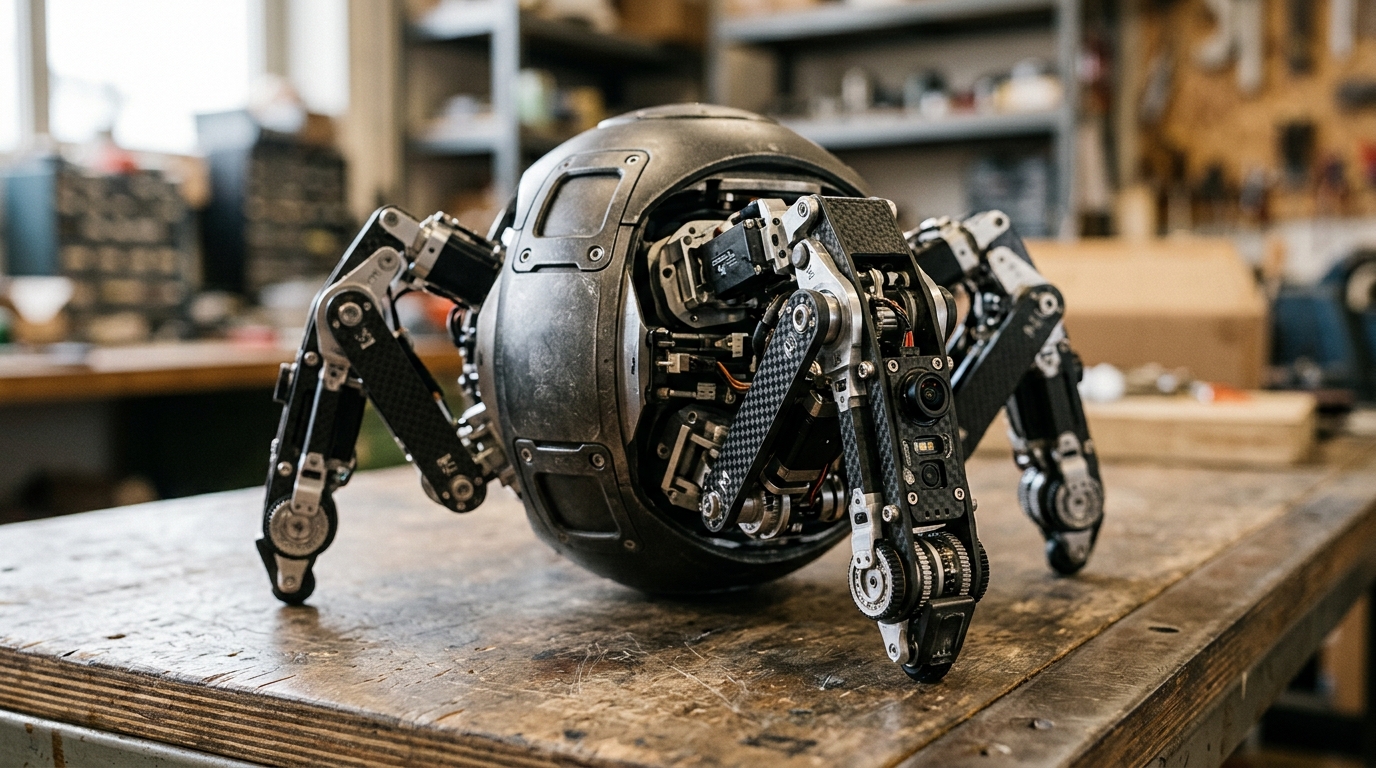
A newly published characterization of a reconfigurable spherical hexapod demonstrates that aggregate joint tracking errors remain between 1.12 and 2.29 degrees across sequential locomotion mode transitions. The investigation evaluated synchronized on-board sensor data to determine whether operational feedback is sufficiently observable and timely to supervise morphology changes when the robotic platform transitions between different locomotion arrangements.

The robotic platform examined in the evaluation incorporates thirty ZX20D serial-bus servos alongside a single S80 center-of-mass shift actuator. This mechanical configuration allows the machine to alternate between compact rolling-oriented geometries and legged locomotion modes.

Experimental evaluations were conducted using a continuous 12.00-second synchronized record capturing multiple operational modes. The recorded test sequence incorporated distinct operating conditions, beginning in a HOME baseline posture, transitioning through a FOLD stage, passing across three discrete center-of-mass shift states, advancing through an UNFOLD phase, and concluding with an alternating tripod gait.

A recalculation performed using the supplied thirty-servo command and feedback archive established statewise aggregate tracking root-mean-square errors ranging from 1.12 to 2.29 degrees. The dataset also revealed notable instantaneous deviations at dynamic transition points, with the largest instantaneous error reaching 33.51 degrees during the transition from ROLL3 to UNFOLD and 32.25 degrees during a GAITB movement reversal.

Under the modeled timing assumptions applied in the study, completing a sequential scan across all thirty serial-bus servos required 26.70 milliseconds. This duration corresponds to a nominal upper scanning frequency of 37.45 hertz, defining the temporal resolution available to on-board controllers during morphological reconfiguration.

Testing verified that physical mass offsets of 72, 66, and 60 millimeters produced corresponding dominant-axis attitude peaks of 24.25, 21.55, and 20.02 degrees.

The on-board instrumentation also tracked load dynamics across leg assemblies using uncalibrated contact and load-proxy channels. Within the analyzed twelve-second recording, these measurement channels separated the commanded stance phases from the commanded swing phases by a mean ratio of 53.0 to 1. This separation demonstrates clear differentiation between grounded and airborne leg groups under baseline conditions.

Together, these tracking metrics, timing constraints, and load differentiation data define quantitative prerequisites for prospective closed-loop supervision. Because the characterization relies on the supplied twelve-second record, the authors present these findings as measurable baseline criteria to support real-time monitoring and control strategies for reconfigurable spherical robots undergoing dynamic mode changes.

Subject of Research: Reconfigurable spherical hexapod feedback characterization

Article Title: Feedback-Readiness Characterization of a Reconfigurable Spherical Hexapod: Synchronized On-Board Sensing for Mode-Transition Supervision

Article References: Wang, Y., Luo, C., Liu, L., Li, M., Chen, Z., Cheng, L., Lin, Z., Chen, H., & Yu, K. (2026). Feedback-Readiness Characterization of a Reconfigurable Spherical Hexapod: Synchronized On-Board Sensing for Mode-Transition Supervision. Journal of Intelligent & Robotic Systems. https://doi.org/10.1007/s10846-026-02472-z

Image Credits: AI Generated

DOI: 10.1007/s10846-026-02472-z

Keywords: reconfigurable robots, spherical hexapod, mode transition, legged locomotion, serial-bus servos, center of mass actuator, tracking error, tripod gait, scan rate, attitude peaks, contact sensing, closed-loop supervision, robot morphology, on-board sensing, feedback readiness, stance and swing ratio

News Source: Denise Maddox. (November 18, 2026). Synchronized Sensing Quantifies Servo Tracking Across Reconfigurable Spherical Hexapod Mode Transitions. Scienmag.
Tags: attitude peakscenter of mass actuatorclosed-loop supervisioncontact sensingfeedback readinesslegged locomotionmode transitionon-board sensingreconfigurable robotsrobot morphologyscan rateserial-bus servosspherical hexapodstance and swing ratiotracking errortripod gait
Share12Tweet7Share2ShareShareShare1

Related Posts

Dual-Stream AI Predicts Intensive Care Kidney Injury but Overestimates Clinical Risk

Dual-Stream AI Predicts Intensive Care Kidney Injury but Overestimates Clinical Risk

November 18, 2026
Cybersecurity Game Theory Models Lack Operational Field Deployments Across Modern Networks

Cybersecurity Game Theory Models Lack Operational Field Deployments Across Modern Networks

November 18, 2026

Multilinear Neural Network Boosts Field Crop Disease Diagnosis Across Variable Environments

November 18, 2026

Disk-Shaped Diatoms Provide Greater Shear Strength in Soil Than Elongated Species

November 18, 2026

POPULAR NEWS

  • Area Disadvantage Outweighs Personal Socioeconomic Status in Chronic Hepatitis B Liver Fibrosis

    Area Disadvantage Outweighs Personal Socioeconomic Status in Chronic Hepatitis B Liver Fibrosis

    29 shares
    Share 12 Tweet 7
  • Seven-Country Study Finds EQ-5D Captures Core Aspects of Poor Health Across Cultures

    29 shares
    Share 12 Tweet 7
  • Alnus trabeculosa Tree Compounds Protect Mitochondria in Parkinson’s Disease Cellular Models

    29 shares
    Share 12 Tweet 7
  • Dordaviprone Review Details Multi-Pathway Activity Against Aggressive Midline Gliomas

    29 shares
    Share 12 Tweet 7

About

We bring you the latest biotechnology news from best research centers and universities around the world. Check our website.

Follow us

Recent News

Screening Reveals Developmental Delays in Many Pediatric Liver Transplant Recipients

Randomized Balance Training Alters Movement Coordination Without Boosting Young Adult Stability

Dual-Stream AI Predicts Intensive Care Kidney Injury but Overestimates Clinical Risk

Subscribe to Blog via Email

Enter your email address to subscribe to this blog and receive notifications of new posts by email.

Join 88 other subscribers
  • Contact Us

Bioengineer.org © Copyright 2023 All Rights Reserved.

Welcome Back!

Login to your account below

Forgotten Password?

Retrieve your password

Please enter your username or email address to reset your password.

Log In
No Result
View All Result
  • Homepages
    • Home Page 1
    • Home Page 2
  • News
  • National
  • Business
  • Health
  • Lifestyle
  • Science

Bioengineer.org © Copyright 2023 All Rights Reserved.