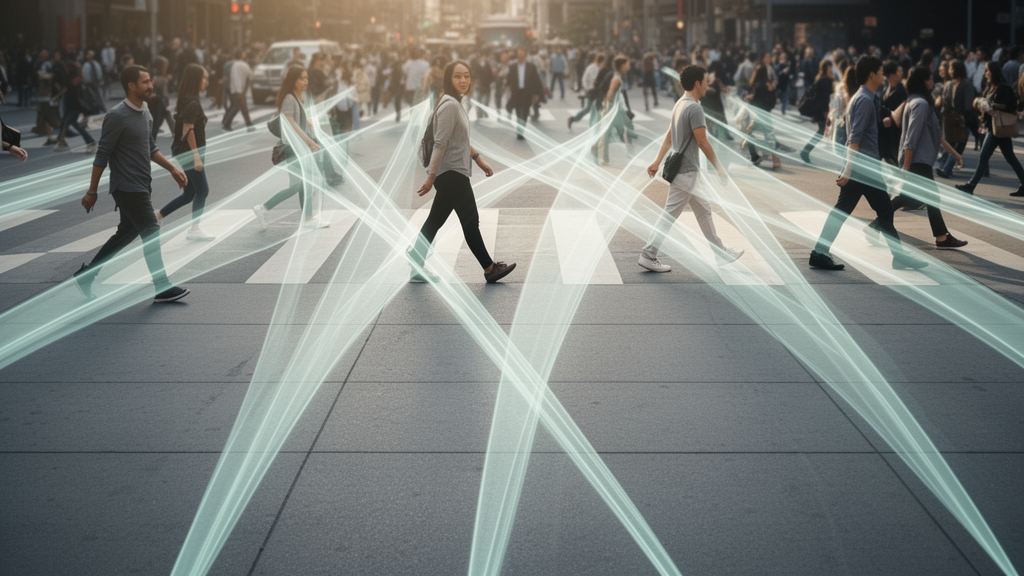
A novel trajectory prediction framework designated SF-SAGCN improves the accuracy of pedestrian movement forecasting by coupling dynamic soft attention mechanisms with the Social Force Model, according to research published in Complex & Intelligent Systems.
The deeply coupled architecture transforms conventional, purely data-driven soft attention into a dynamic, intent-aware topological representation guided directly by the Social Force Model. This structure is specifically designed to mitigate the risk of predictive models becoming trapped in short-sighted local optima that arise from an over-reliance on instantaneous speed and direction. Under this design, interaction soft attention weights are dynamically rectified by coupling a history-derived desired-motion driving force with multi-pedestrian interaction forces.
In addition to pedestrian-to-pedestrian dynamics, the framework integrates a pedestrian-environment interaction confidence factor that enriches the semantic representation of spatial scene nodes. Following this spatial interaction modeling, Temporal Convolutional Networks are deployed to process the intent-aware representations and generate the final predicted movement trajectories.
Extensive evaluations conducted on public benchmark datasets demonstrated a clear quantitative advantage over previous trajectory prediction methods. Furthermore, targeted ablation studies and leave-one-scene-out experiments confirmed the effectiveness of the model’s individual components and established its generalization capability across diverse spatial scenes.
The accuracy of pedestrian trajectory prediction is fundamentally crucial for advancing traffic management protocols, refining the operational efficiency of autonomous driving systems, and bolstering overall public safety.
Subject of Research: Pedestrian trajectory prediction using social force-guided graph convolutional networks
Article Title: Pedestrian trajectory prediction based on social force-guided soft attention graph convolutional network
Article References: Hui, L., Mingyue, L., Wanbo, L., Hewei, L., Jianan, L., & Wei, Q. (2026). Pedestrian trajectory prediction based on social force-guided soft attention graph convolutional network. Complex & Intelligent Systems. https://doi.org/10.1007/s40747-026-02591-y
Image Credits: AI Generated
DOI: 10.1007/s40747-026-02591-y
Keywords: pedestrian trajectory prediction, social force model, soft attention mechanism, graph convolutional networks, temporal convolutional networks, autonomous driving systems, traffic management, public safety, intent-aware topological representation, pedestrian-environment interaction, interaction confidence factor, desired-motion driving force, multi-pedestrian interaction forces, spatial scene nodes, leave-one-scene-out experiments, ablation experiments, cross-scene generalization, SF-SAGCN framework
News Source: Cassandra Pierce. (November 18, 2026). Social Force Guided Neural Network Improves Pedestrian Trajectory Predictions in Tests. Scienmag.