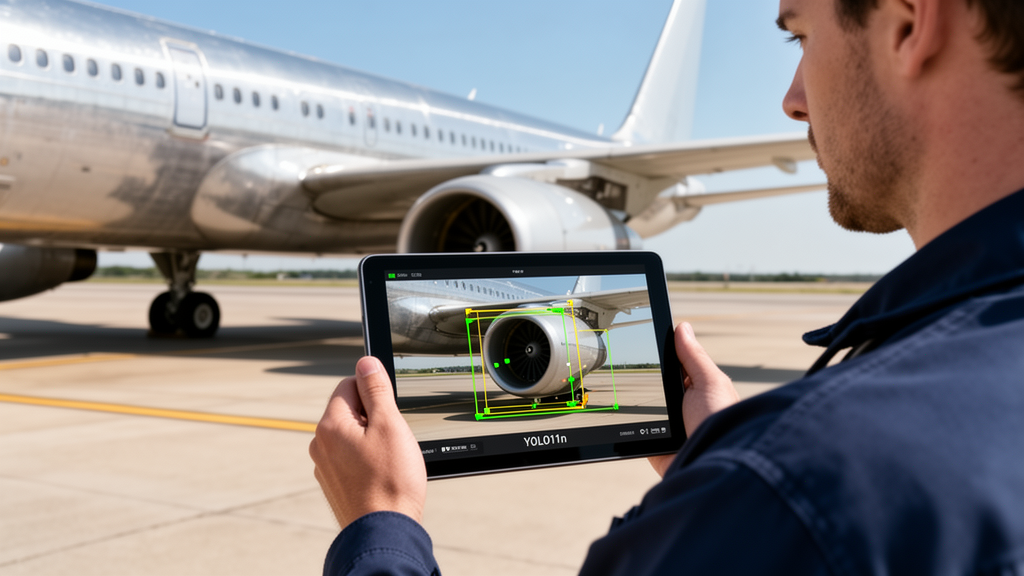
In an edge deployment evaluation for robot-assisted aircraft walk-around inspection, the lightweight YOLO11n object detection architecture emerged as the only tested model capable of processing an entire walk-around video recording within the physical duration of the recording itself. Evaluated across repeated benchmark trials on a mobile robot’s onboard computer, the model successfully completed the full inspection workload faster than real-time playback, establishing OpenVINO YOLO11n as a viable and practical option for autonomous aeronautical inspection tasks.
The research, published in Frontiers in Mechanical Engineering, was carried out by investigators Yiming Yang, Weihan Li, and Yuying Dong from the Xian Aeronautical Polytechnic Institute in Xi’an, China, in collaboration with Kelu Cao from Jinduicheng Molybdenum Co., Ltd. Their investigation directly addressed a critical technical requirement in automated aviation maintenance: enabling an autonomous inspection robot to reliably identify external airframe targets while maintaining fast, efficient computational processing directly on the robot’s onboard edge hardware.
To ground their visual detection pipeline in real-world maintenance routines, the authors mapped ten visually observable Boeing 737-300 job-card targets directly to distinct object detection classes. They compiled an experimental dataset comprising 3,219 images containing a total of 6,808 target annotations. For experimental validation, the researchers structured the visual data into a sequence-separated dataset featuring a held-out test set of 457 images, which served as the common benchmark to compare seven distinct YOLO network configurations.
Evaluation across the held-out test set revealed clear performance variations among the seven evaluated YOLO models depending on the precision threshold applied. The YOLO11s-P2 configuration secured the highest detection accuracy at the 0.50 intersection-over-union benchmark, achieving an mAP50 score of 0.8939. In contrast, when measured across the broader range of intersection-over-union thresholds from 0.50 to 0.95, the YOLO26s configuration demonstrated the strongest overall precision, recording the study’s top mAP50-95 score of 0.4308.
To determine actual field readiness, the authors implemented a deployment evaluation that integrated detection accuracy, OpenVINO conversion consistency, and repeated video processing directly on the robot’s physical onboard hardware, an Intel Core i5-1335U MiniPC. Six of the seven candidate YOLO configurations were evaluated by running inference over an identical 7,255-frame walk-around inspection video lasting 241.82 seconds. Each of the six models processed this complete recording three separate times using OpenVINO CPU inference.
During these edge computing trials, YOLO11n completed the full 7,255-frame inspection recording in an average duration of 220.7 ± 6.5 seconds, expressed as mean ± standard deviation. Crucially, YOLO11n was the single configuration among all tested models to process every individual frame within the 241.82-second recording duration across all three experimental runs, leading the research team to conclude that OpenVINO YOLO11n represents a practical, dependable deployment choice for the evaluated onboard inspection workload.
Subject of Research: Edge object detection deployment for robot-assisted aircraft walk-around inspection
Article Title: Object detection and edge deployment for robot-assisted aircraft walk-around inspection
Article References: Yang, Y., Li, W., Dong, Y., & Cao, K. (2026). Object detection and edge deployment for robot-assisted aircraft walk-around inspection. Frontiers in Mechanical Engineering, 12, Article 2007121. https://doi.org/10.3389/fmech.2026.2007121
Image Credits: AI Generated
DOI: 10.3389/fmech.2026.2007121
Keywords: robot-assisted inspection, aircraft walk-around inspection, edge deployment, object detection, YOLO, YOLO11n, YOLO11s-P2, YOLO26s, OpenVINO, Intel Core i5-1335U, Boeing 737-300, aircraft maintenance, mechatronics, CPU inference, job-card targets, mean average precision, onboard computing
News Source: Denise Maddox. (November 17, 2026). Onboard YOLO11n Model Completes Aircraft Walk-Around Video Processing Within Recording Duration. Scienmag.