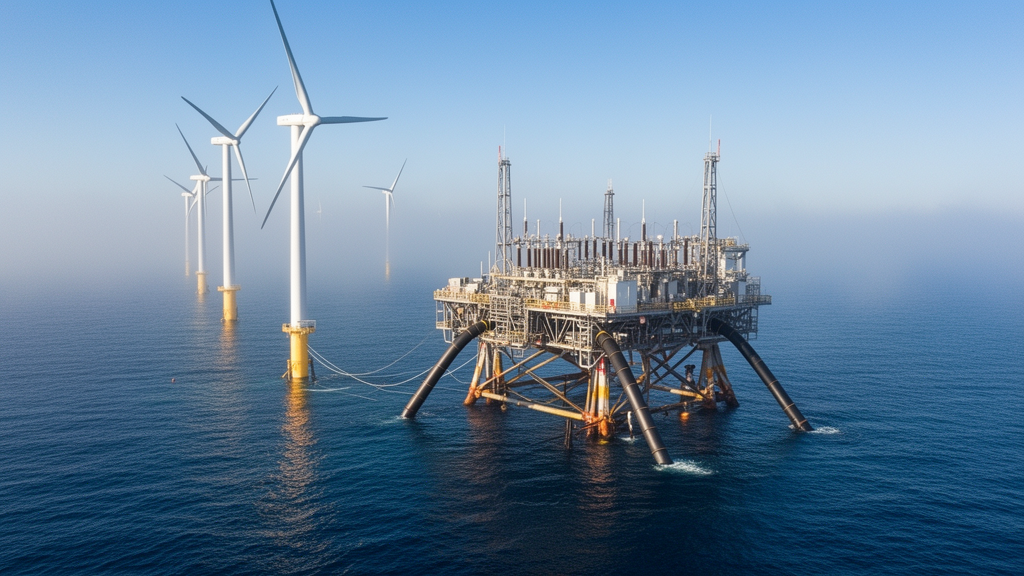
Engineers have developed a sequence-domain graph learning framework that significantly improves fault-location accuracy across offshore wind farm transmission networks dominated by inverter-based resources. Electrical faults in offshore power collection and export systems represent severe logistical and financial challenges, as locating damaged cables beneath the seabed requires specialized vessels, favorable weather windows, and prolonged system outages. The integration of full-converter wind turbine generators further complicates automated protection because power electronics restrict fault current magnitudes and shift phase angles according to control priorities rather than traditional physical machine impedances. Compounding the challenge, long submarine cross-linked polyethylene cables introduce significant capacitive charging currents, while high fault resistances weaken diagnostic electrical signatures. The newly introduced framework, termed physics-grounded sequence-domain graph learning, addresses these operational hurdles by coupling an eight-node graph attention network with a three-sequence physics-informed neural network, analytical compensation algorithms, and rigorous uncertainty bounds.
The research evaluates this methodology within a simulated 69-kilovolt, 60-hertz offshore collection and export network model derived from an established transmission benchmark. In this simulated topology, a primary utility Thevenin source at Bus A connects to a shore-side collector station at Bus B through a 60-kilometer overhead transmission line. Landing at Bus B are three submarine cable feeders measuring 5, 7, and 9 kilometers in length, each modeled with equivalent sections that capture distributed series impedances and shunt capacitances. These individual subsea feeders terminate at three distinct full-converter wind turbine generator groups rated at 24, 32, and 20 megawatts, representing a combined generating capacity of 76 megawatts. Synchronized intelligent electronic devices stationed at Bus A and Bus B capture fundamental and harmonic current and voltage phasors. Rather than operating under passive synchronous generator physics, the modeled wind turbines operate as current-controlled sources governed by fault-ride-through specifications, restricting positive-sequence reactive current injection to 1.10 per unit and active current to 0.40 per unit.
To overcome the limitations of classical single-ended impedance and Takagi locators that presume homogeneous source impedances, the framework transforms all three-phase terminal voltage and current phasors into symmetrical components consisting of positive, negative, and zero sequences. This electrical transformation cleanly isolates the distinct boundary behaviors of different fault topologies before passing them into the learning pipeline. The physical wind farm layout is mapped into an undirected topological graph comprising eight nodes and seven edges. The nodes represent the main utility bus, the shore-side collector bus, the three subsea feeder landing terminals, and the three offshore wind turbine converter terminals. Each node carries a twelve-dimensional feature vector containing sequence voltage and current magnitudes and angles, referenced to the positive-sequence voltage angle at Bus A. Corresponding edges carry four-dimensional attribute vectors detailing branch sequence impedance magnitudes, physical path lengths, and binary flags indicating whether a segment consists of an overhead line or an insulated submarine cable.
Processing these topological electrical inputs begins with a sequence-domain graph attention neural network, designated as SeqGNN, configured with four message-passing layers, eight attention heads, and a hidden layer width of 128 units. The graph attention mechanism assigns dynamic importance weights to adjacent network branches, allowing the model to distinguish between faulted branches and healthy operational feeders. An aggregation readout block combines the mean-pooled graph embedding with specific embeddings from the terminal intelligent electronic devices to feed four separate task heads. Two classification heads categorize the precise fault type among single phase-to-ground, phase-to-phase-to-ground, phase-to-phase, and balanced three-phase events, while concurrently identifying the faulted line or feeder section with recorded accuracies ranging between 99.4 percent and 99.6 percent. Simultaneously, two regression heads produce initial estimates of the per-unit fault distance along the identified line segment and the apparent fault resistance.
Because data-driven graph representations can produce electrically inconsistent predictions under novel operating states, the initial estimates are transferred to a three-sequence physics-informed neural network refinement module. Operating as a fully connected refinement network, this module incorporates sequence-domain network constraints directly into its optimization loss function. For each sequence excited by a specific fault type, the formulation computes the internal fault-point voltage independently from both terminal records using Kirchhoff voltage laws. The discrepancy between these two terminal-derived fault voltages forms a sequence line residual that penalizes physical inconsistencies during model optimization. Furthermore, fault-type boundary conditions enforce analytical voltage-drop relationships across the fault resistance, accommodating zero-sequence ground loops during ground faults or differential phase potentials during line-to-line faults. A secondary monotonicity regularization term prevents apparent reactance increases from yielding smaller estimated fault distances, anchoring the neural network to fundamental electromagnetic transmission behavior.
A critical analytical contribution of the architecture is its decoupling of internal transmission line physics from non-linear converter control actions. When unbalanced faults occur, grid-following converters actively inject negative-sequence currents to support system stability, creating strong cross-sequence coupling. The framework accommodates this converter behavior by restricting the sequence boundary constraints to the passive transmission segments between synchronized relays, treating converter controls as external boundary injections that enter purely through measured terminal currents. Under the condition that line conductors are transposed and synchronized terminal phasors are available, the sequence impedance matrices remain decoupled. To correct for subsea cable physics, the system implements a half-line shunt charging current compensation routine. Because the charging current across the three subsea feeders represents between 4.1 percent and 8.9 percent of the rated turbine current, removing fundamental capacitive current before graph ingestion directly mitigates phase angle distortion on small converter-limited fault currents.
The framework also incorporates an analytical inverter operating-point adaptation that requires no neural network retraining. Because total fault current divides between the utility grid and the current-limited converter, the grid-side share of the current varies non-linearly with the pre-fault active power generation. Using an analytical hyperbolic decomposition function with a fixed parameter constant of 0.85, the pipeline estimates total fault current from single-terminal measurements based on pre-fault power readings accessible via supervisory control and data acquisition systems. In testing across five operating points ranging from 0.70 to 1.30 per unit power, this adaptation suppressed mean relative errors by 48.3 percent at nominal capacity and up to 69.2 percent at generation extremes. For high-impedance faults up to 150 ohms, an automated harmonic detection gate measures third- and fifth-harmonic current distortion over a one-cycle discrete Fourier transform window, triggering Dempster-Shafer evidence fusion across both terminal relays to reconcile conflicting directional views.
Across comprehensive simulation benchmarks encompassing single-phase, phase-to-phase, and three-phase faults with resistances between 2 and 40 ohms, the complete architecture demonstrated marked improvements over conventional and machine learning benchmarks. Across the main 60-kilometer overhead line, the proposed framework achieved an average mean relative location error of 0.195 percent. In direct comparison, the published random-forest benchmark using identical line parameters registered an average error of 0.631 percent, while the classical Takagi locator exhibited an average error of 2.100 percent and conventional impedance calculation degraded to an average error of 32.7 percent at 40 ohms. The physics-informed refinement module was particularly impactful in resolving fault resistance, reducing the average resistance estimation error from 4.67 ohms in the random-forest baseline down to 1.98 ohms, with the greatest precision gains occurring on ground-involved faults where zero-sequence equations are fully active.
The evaluation further quantified uncertainty and operational protection compatibility using sequence-residual split-conformal prediction and a protection consistency index. Unlike standard conformal prediction schemes that produce fixed-width uncertainty bands, the sequence-residual conformal formulation scales prediction intervals dynamically according to physical line residuals, expanding intervals when measurements show electrical inconsistency. Concurrently, the protection consistency index tracked whether estimated locations mapped into the correct distance relay reach zones. The system maintained an index of 0.982 up to 60 ohms fault resistance, staying well above legacy methods at high resistances, while subsea cable charging compensation reduced feeder location errors by 70.1 percent to 73.9 percent across all cable lengths.
Despite these favorable simulation results, the investigators explicitly delineate several boundaries surrounding the present findings. The performance metrics rely exclusively on simulated fault cases within a single transmission topology, without validation on real-time digital simulators, hardware-in-the-loop platforms, or empirical field records. Furthermore, the comparative benchmark against prior random-forest methods represents an indicative evaluation rather than a paired statistical trial on identical events, as the benchmark system lacked subsea cable branches. The sequence decoupling equations assume fully transposed conductors, which may not match untransposed overhead geometries or complex cable sheath bonding configurations. The authors emphasize that extensive multi-seed robustness testing under noise, communication latency, and varying converter control schemes must precede any practical deployment in offshore substation automation.
Subject of Research: Physics-grounded graph learning for fault location in inverter-dominated offshore wind farm networks
Article Title: Physics-grounded sequence-domain graph learning for adaptive fault location in IBR-dominated offshore wind farm transmission networks
Article References: Pandya, S. B., & Kalita, K. (2026). Physics-grounded sequence-domain graph learning for adaptive fault location in IBR-dominated offshore wind farm transmission networks. Discover Artificial Intelligence, 6(1), Article 1863. https://doi.org/10.1007/s44163-026-02731-w
Image Credits: AI Generated
DOI: 10.1007/s44163-026-02731-w
Keywords: offshore wind farms, fault location, inverter-based resources, graph neural networks, physics-informed neural networks, symmetrical components, sequence domain, cable charging current, split-conformal prediction, high-impedance faults, Dempster-Shafer fusion, protection consistency index, transmission networks, submarine power cables, distance relaying, power system protection
News Source: Katie Riggs. (November 13, 2026). Physics-Grounded Graph Learning Accurately Locates Faults in Offshore Wind Networks. Scienmag.